How to manipulate parameters at runtime | ROS2 Humble Python Tutorial ...
How to set/get parameters from another node | ROS 2 Humble Python ...
How to use C++ and Python in the same ROS2 package | ROS2 Humble ...
How to import custom Python3 modules in a ROS2 package | ROS2 Humble ...
How to create a complex message - ROS2 Basics in 5 Days Humble (Python ...
Python ROS2: Mastering Callbacks Tutorial | ROS Developers Open Class ...
Runtime Mobile Security: manipulate Android Java Classes and Methods at ...
ROS2 Tutorial 3: Publisher and Subscriber Nodes From Scratch in Python ...
Create a ROS2 Node with Python - ROS2 Humble Tutorial 6 - YouTube
How to Install ROS 2 Humble on Ubuntu 22.04 - ROS 2 Tutorial 1 - YouTube
Tạo bản đồ cùng với ROS2 Nav2 sử dụng SLAM | ROS2 Navigation Tutorial ...
[Bug] Unable to execute Example 2.5 - ROS2 Basics in 5 Days Humble ...
ROS2 Humble Cartographer on NVIDIA Jetson Nano with RPLIDAR | by ...
Mô phỏng nhiều robot với Nav2 trong ROS2 Humble & Gazebo (Phần 1 ...
Parameterの使い方 - Japanese ROS2 Tutorial | The Construct
Comment utiliser OpenCV avec ROS2 en C++ et Python - French ROS ...
rclcpp Params Tutorial - Get and Set ROS2 Params with Cpp - The ...
How To Set Parameters In Power Bi - Dibujos Cute Para Imprimir
2.10 STEP 4 doesn't work - ROS2 Basics in 5 Days Humble (Python) - The ...
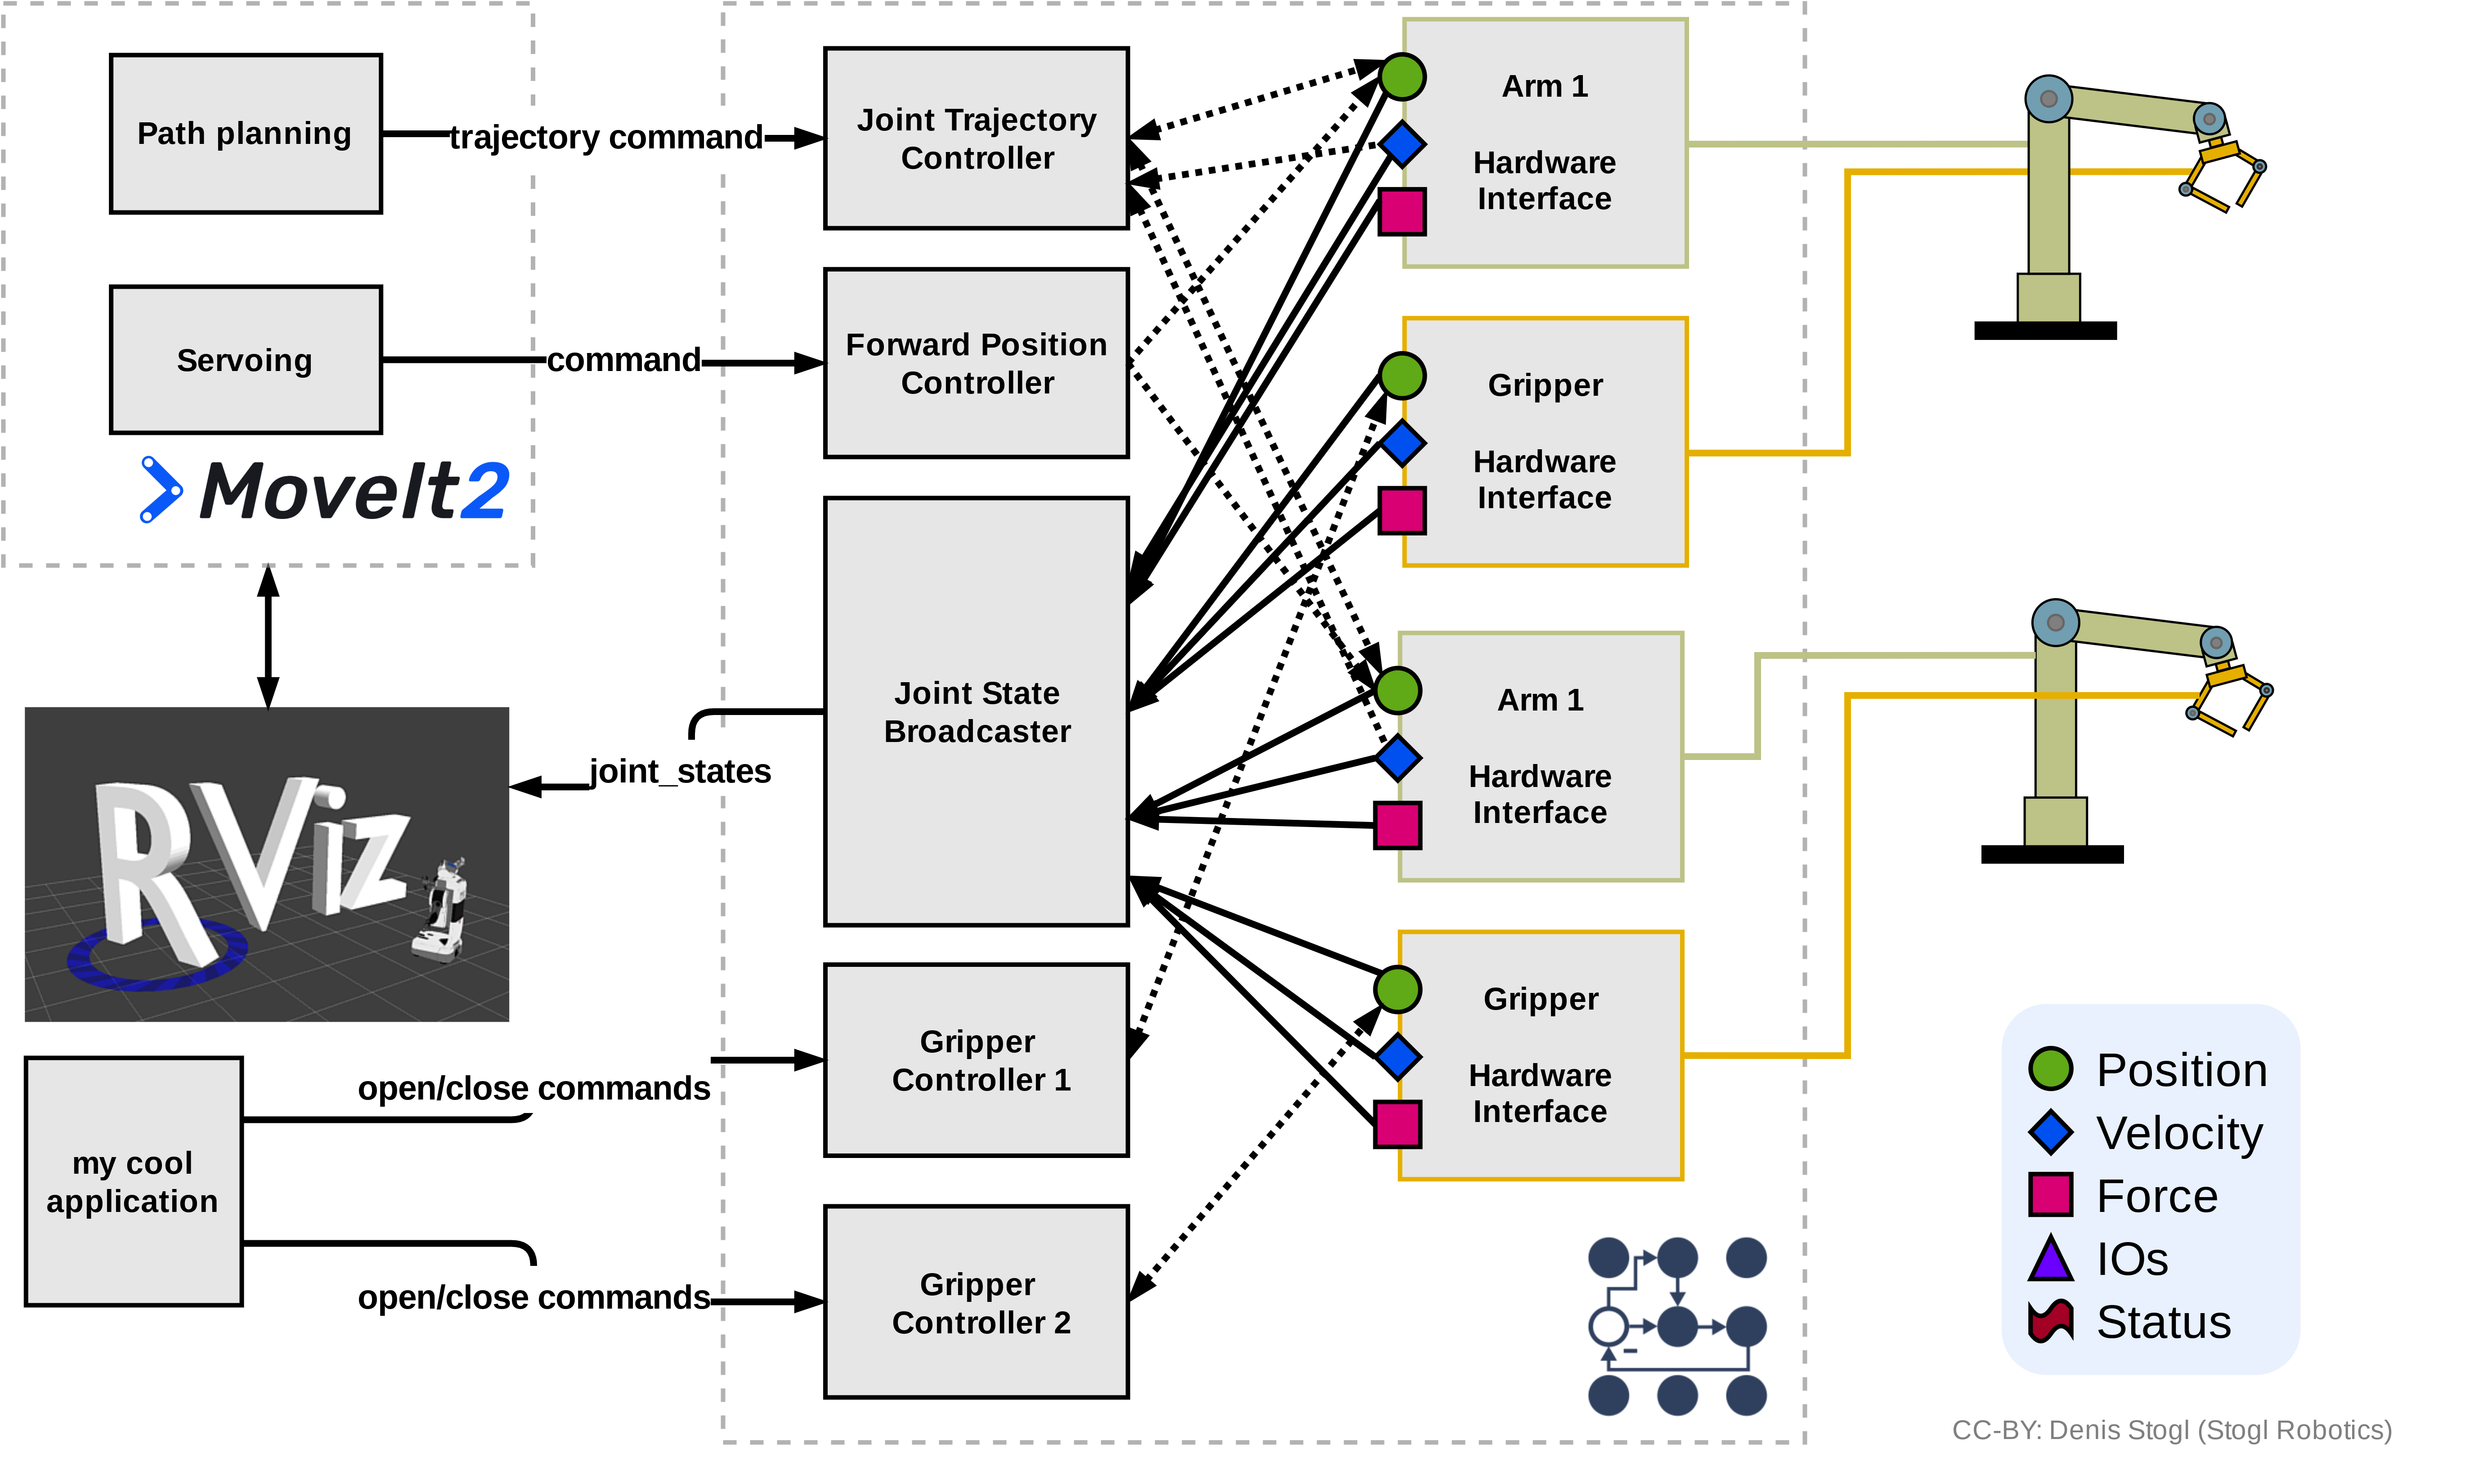
Example 7: Full tutorial with a 6DOF robot — ROS2_Control: Humble Feb ...
Combine Publisher, Subscriber & Service in ROS2 Single Node | ROS2 ...
ROS2 Jazzy Tutorials from Scratch: First Python Program in ROS2 Jazzy ...
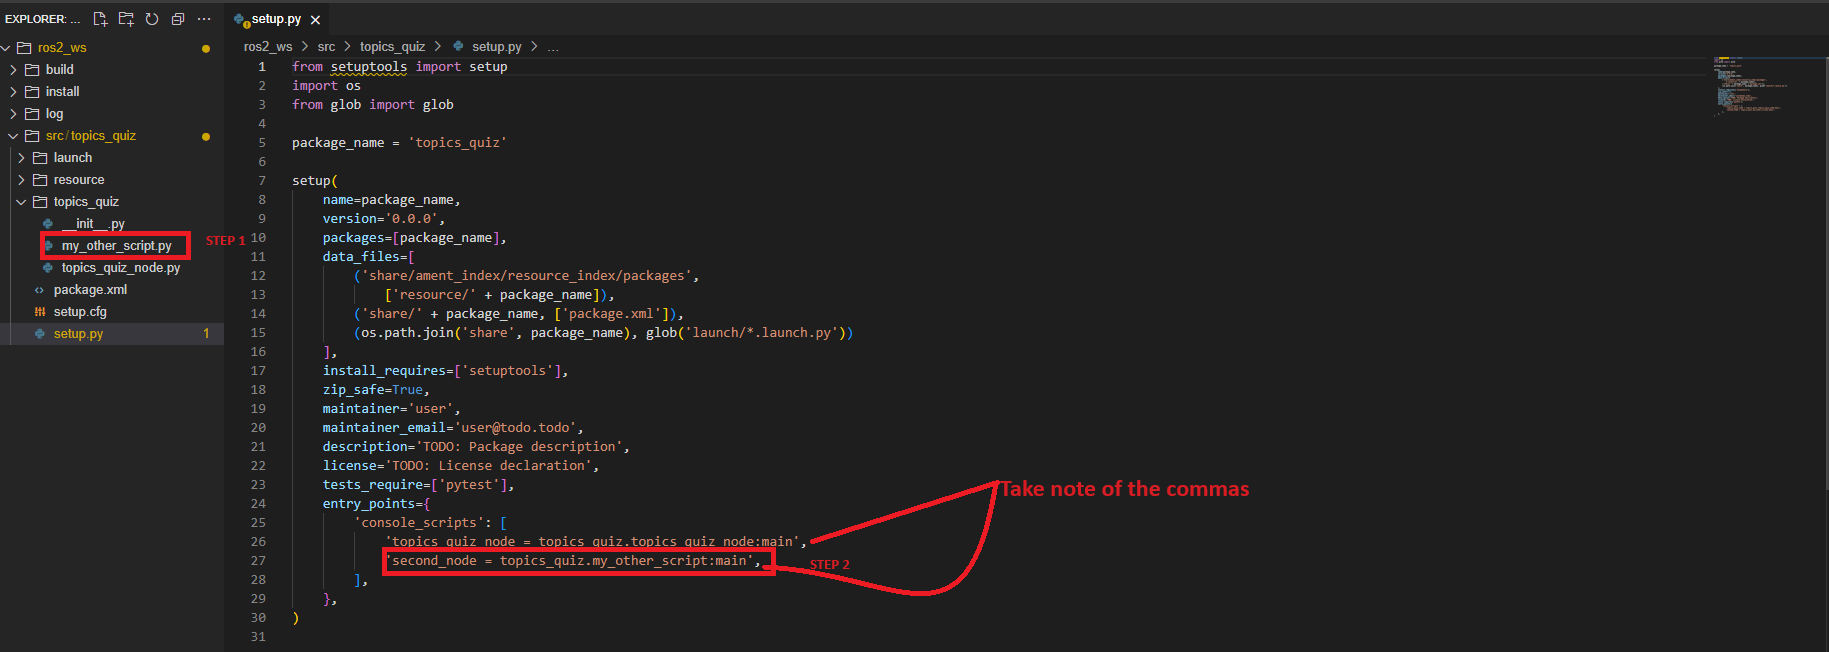
[Bug] setuptools! - ROS2 Basics in 5 Days Humble (Python) - The ...
How to Set Up & Use System Parameters in Odoo 18
ros2 インストール ubuntu | ros2 humble desktop インストール – YCZIY
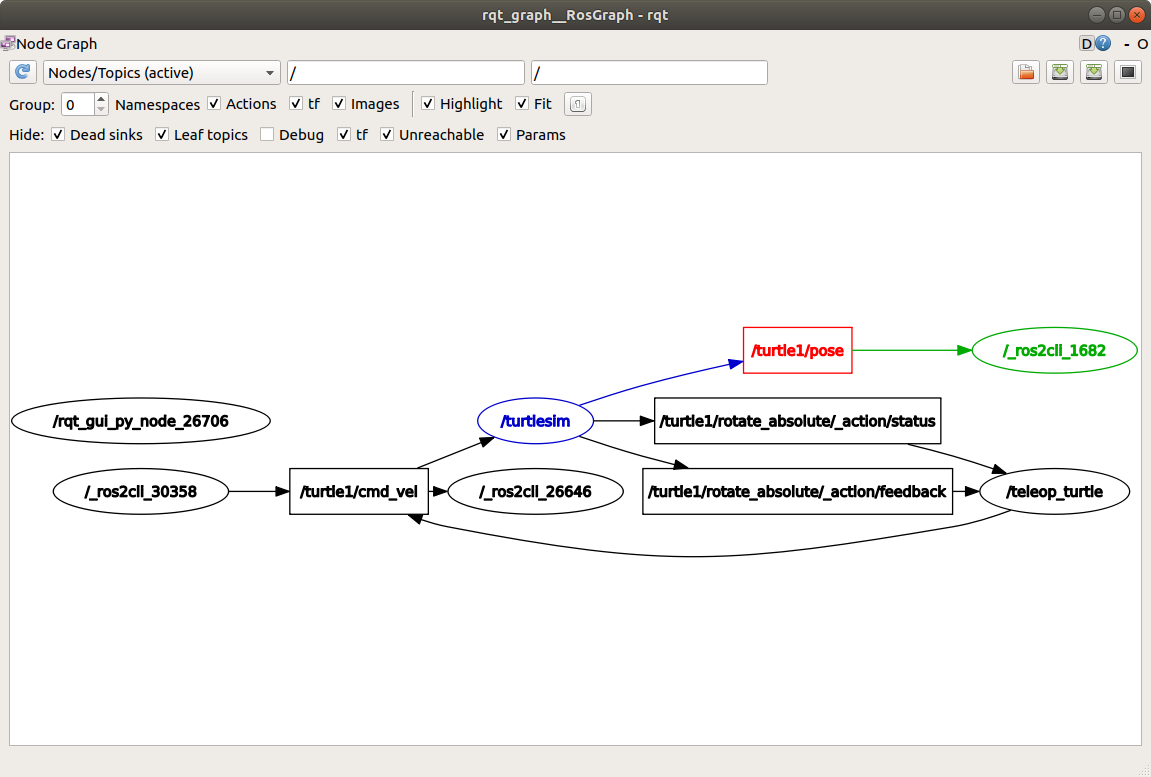
ROS2 Humble Tutorial: The Basic Structure of ROS2 Communication Graph ...
[Bug] I deleted all the files - ROS2 Basics in 5 Days Humble (Python ...
Unable to launch subscriber in 3.3.1 (ROS Basics) - ROS2 Basics in 5 ...
Como usar en ROS2 un paquete de ROS1 generado por SolidWorks to URDF ...
Setup system for ROS2 development - ROS2 Tutorial - ros2 humble - YouTube
Run a python file outside the package_name folder - ROS2 Basics in 5 ...
Yahboom ESP32 Smart Robotics ROS2 Humble Robot Kit microROS Robot ...
[Bug] Problem running launch file - ROS2 Basics in 5 Days Humble ...
[Rosject] ROS2 Basics Part 2: Services - ROS2 Basics in 5 Days Humble ...
How to Create URDF and Launch Files of Robot From Scratch - Complete ...
Test Review Needed - ROS2 Basics in 5 Days Humble (Python) - The ...
Do not understand hint for quiz 3.7 - ROS2 Basics in 5 Days Humble ...
[Bug] ROS2 can not find launch file - ROS2 Basics in 5 Days Humble ...
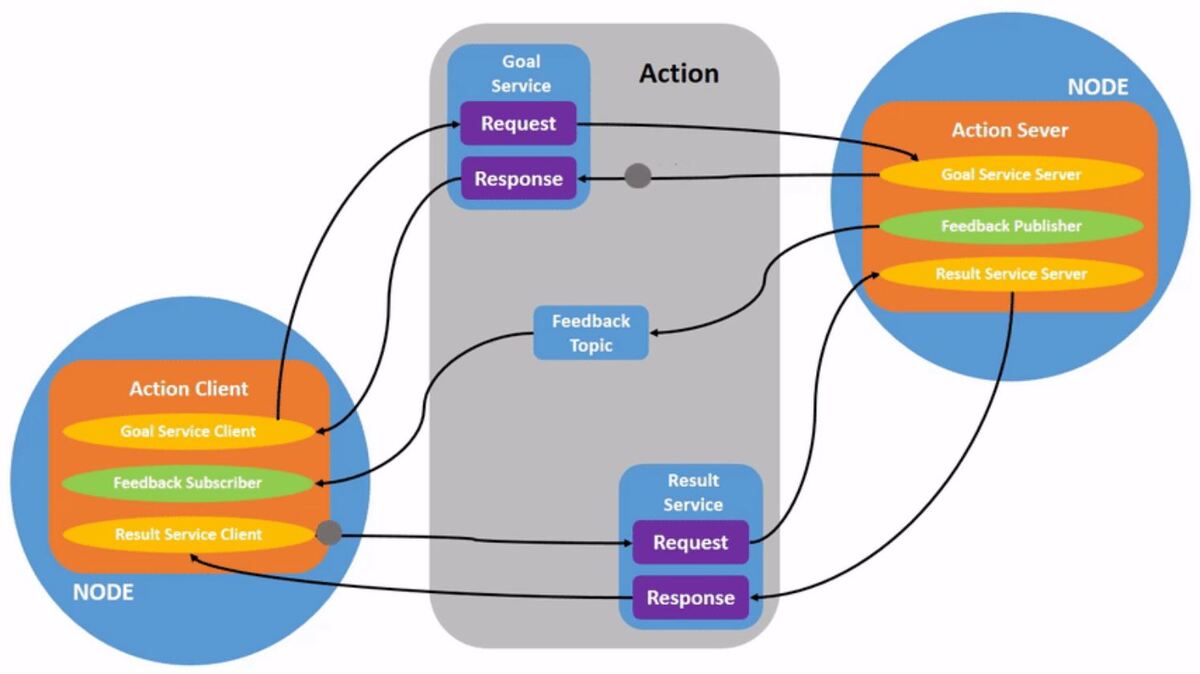
ROS2 Humble 笔记(八)动作 action_ros2 python action-CSDN博客
Create a ROS2 Python Package - ROS2 Tutorial 4 - YouTube
Unsure of what to make of the multithreading example in unit 5 - ROS2 ...
Setting Up TurtleBot3 Simulation in ROS 2 Humble Hawksbill | by ...
A Beginner’s Guide to Simulating and Testing Robots with ROS 2 and ...
Example_Interfaces Ros2 at Carlos Hamilton blog
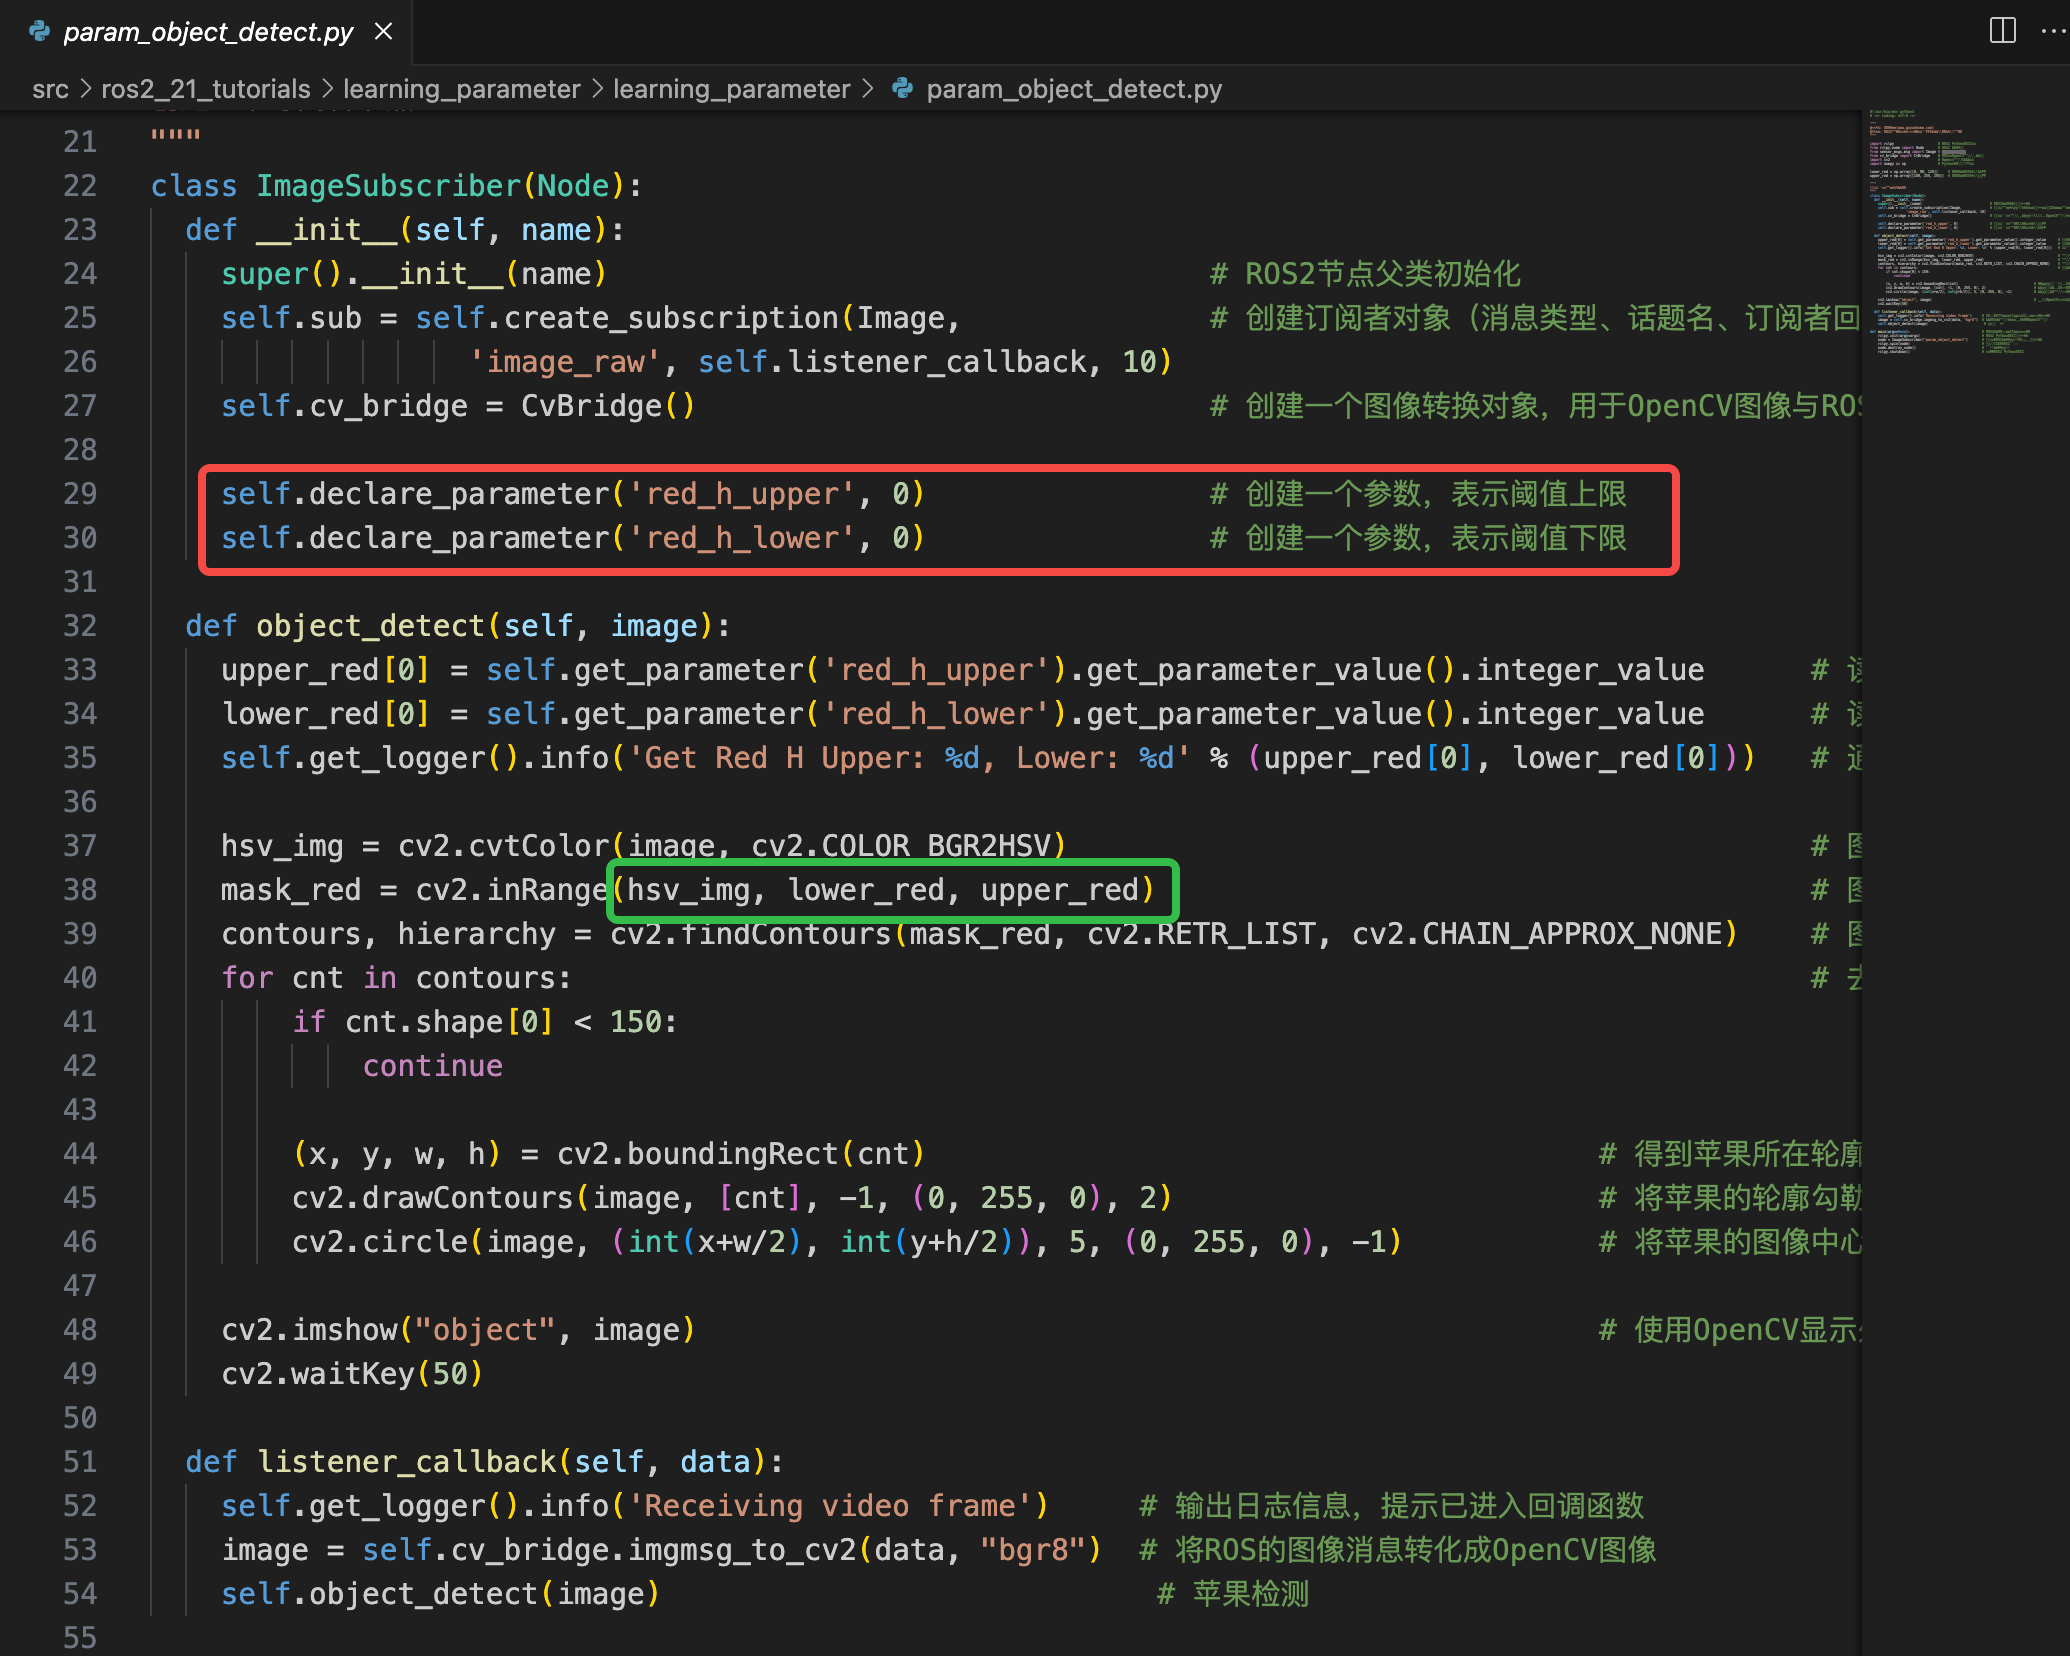
ROS2 Humble 笔记(九)参数 param_ros2 param-CSDN博客
How To Create an Action in ROS 2 Galactic (Advanced)
New ROS Online Course - Gazebo Sim with ROS2 - Learn from scratch ...
MPU9250 IMU with ROS2 on Raspberry Pi for Rviz IMU Data Visualization ...
Ros 2 Publisher and Subscriber Python | by Poommin | Medium
2025 最新 Python MQTT 終極攻略 | 解鎖 IOT 物聯網通信 | SaludPCB
Integrating Pi Camera with ROS 2 Humble on NVIDIA Jetson Nano using ...
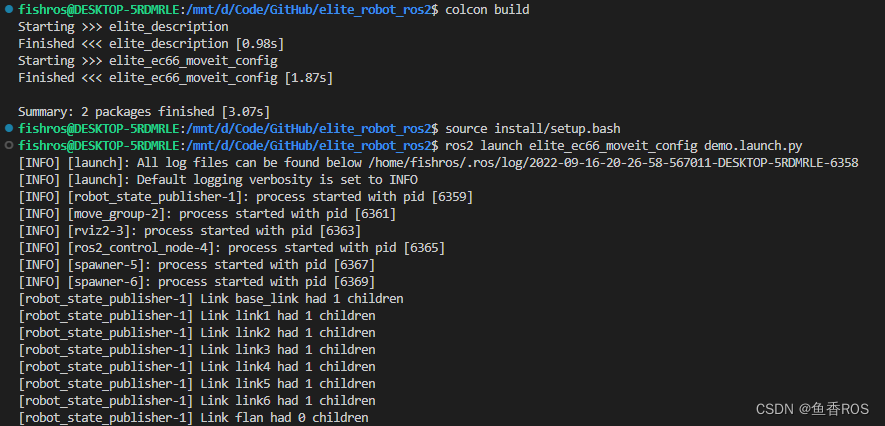
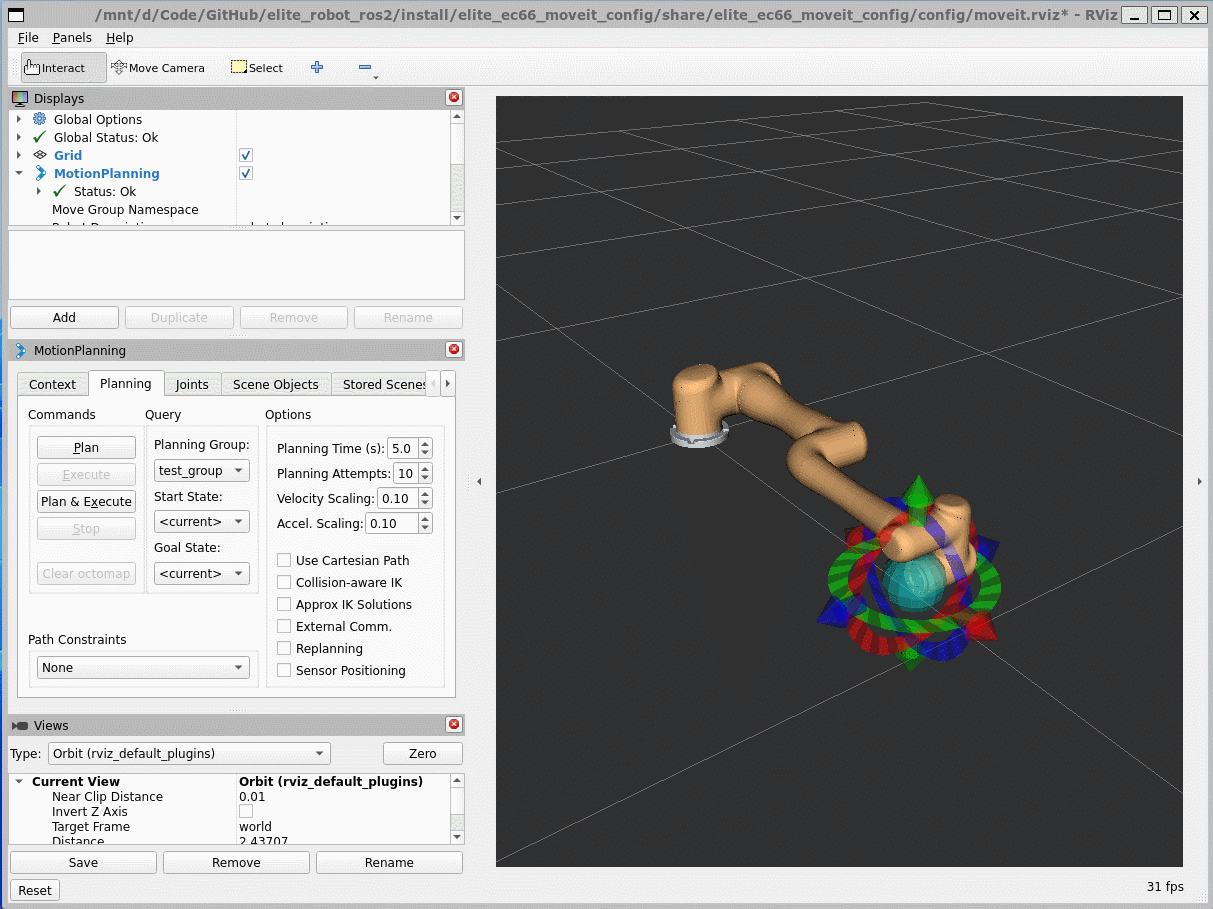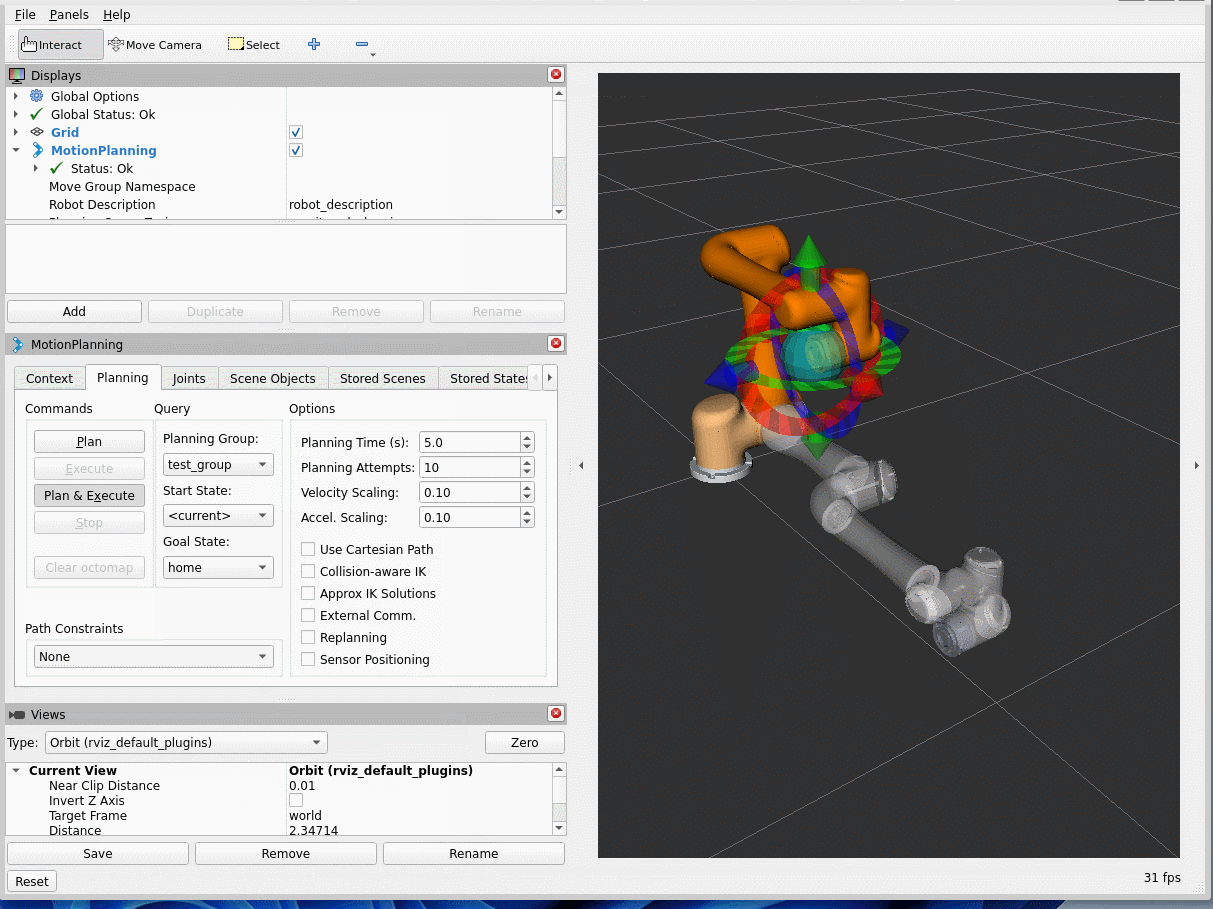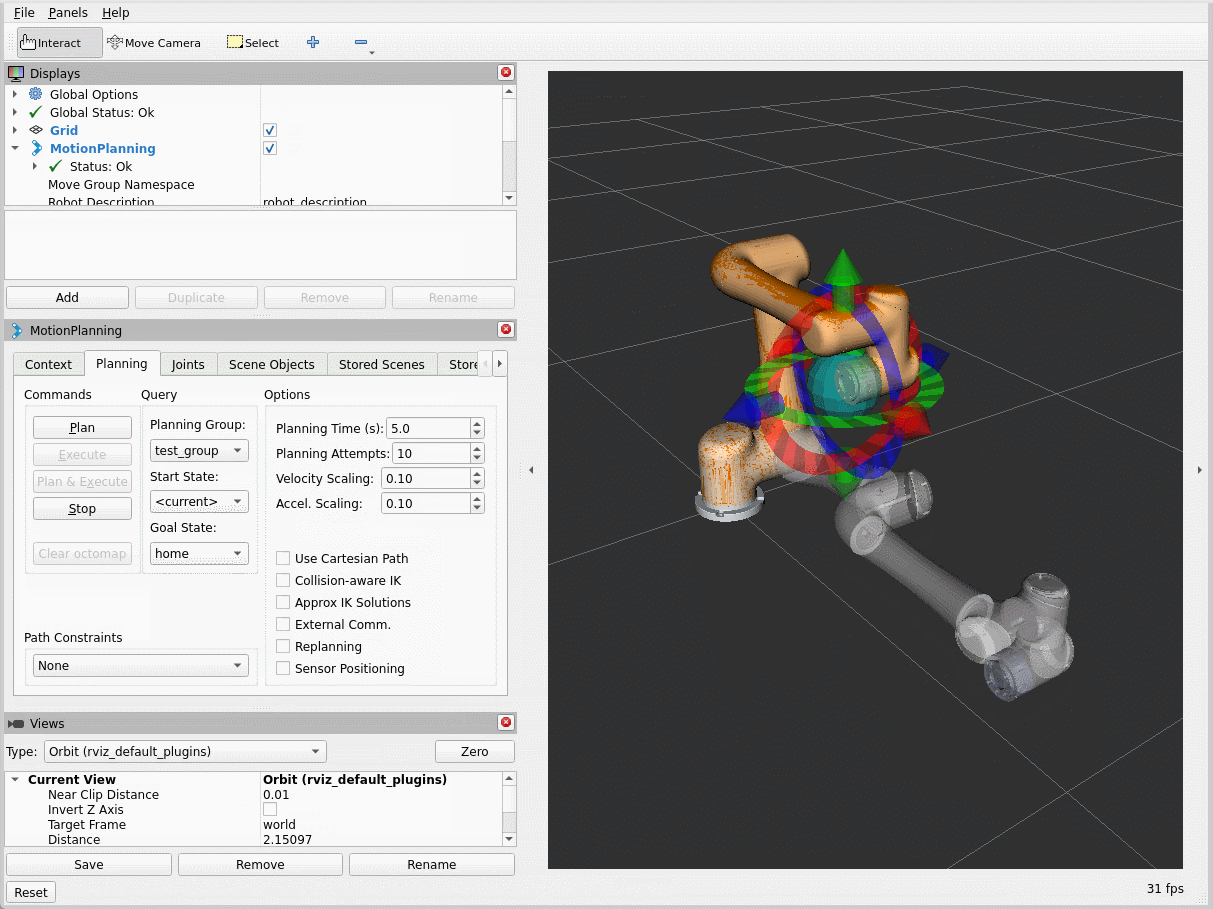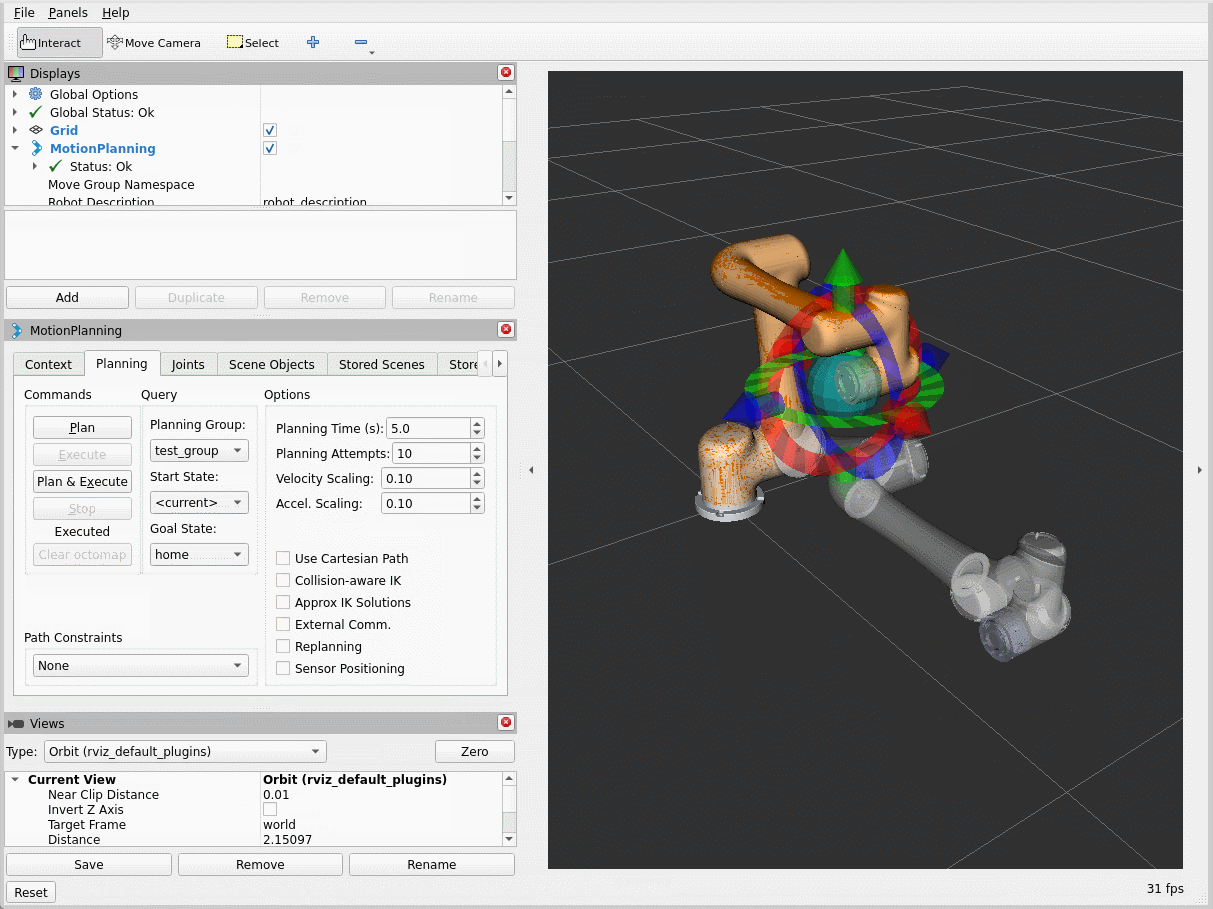
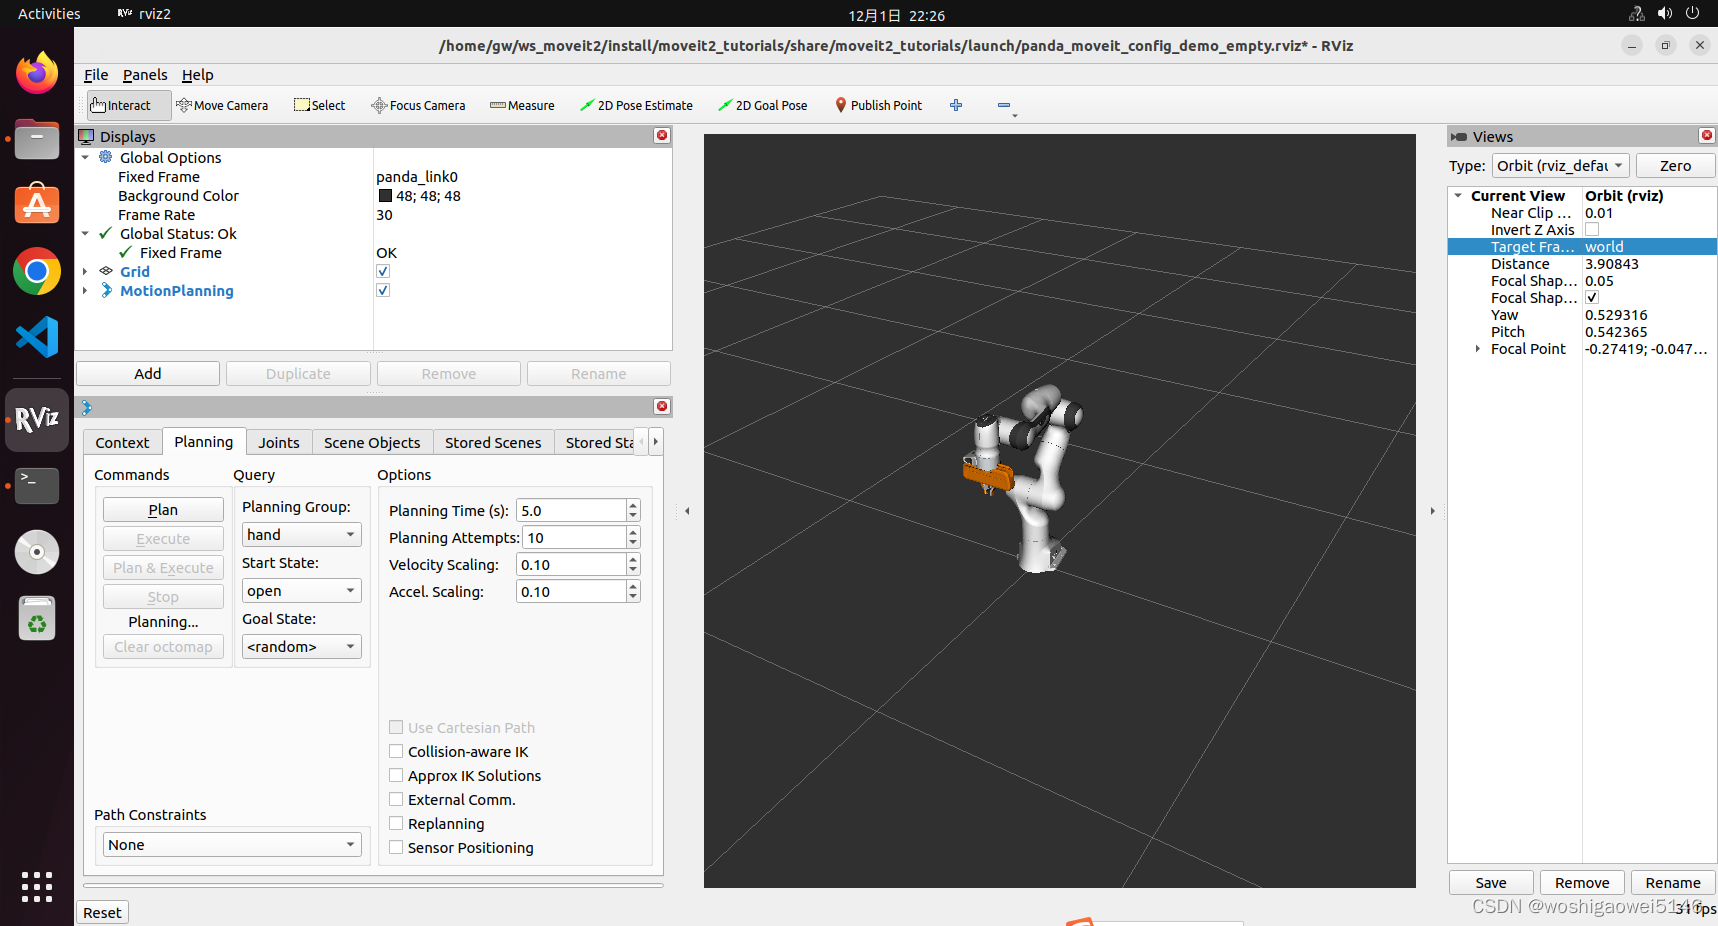
动手学Moveit2 | 运行配置好的机械臂功能demo_python humble moveit2-CSDN博客
Image to PDF Conversion in Python: Complete Tutorial with Code
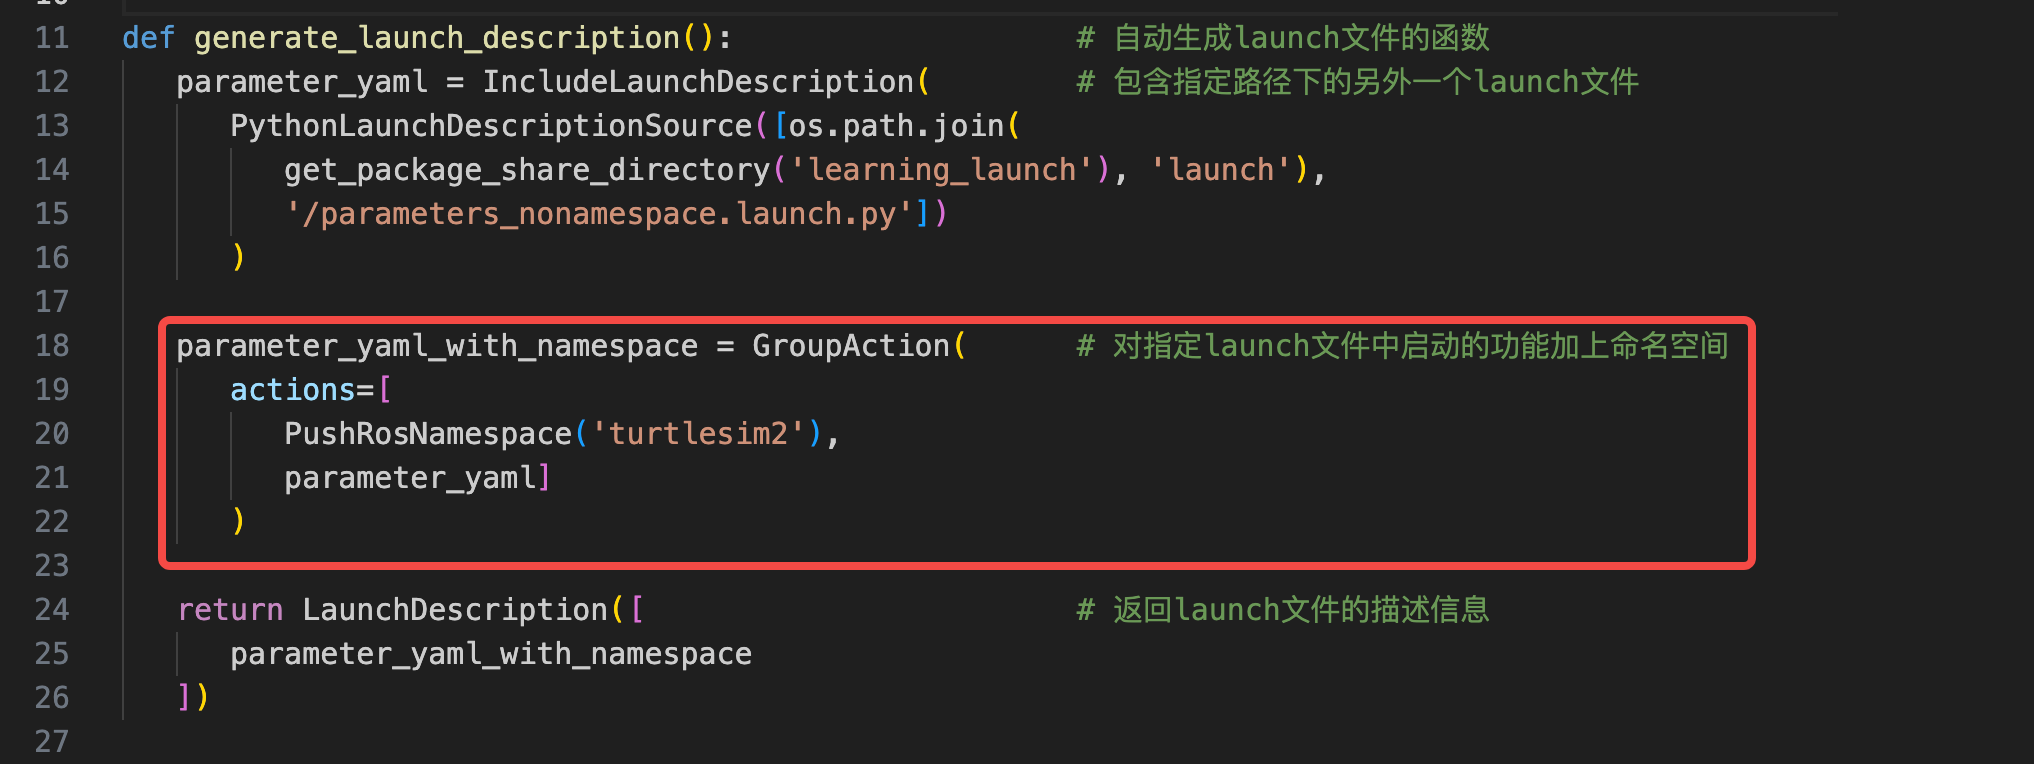
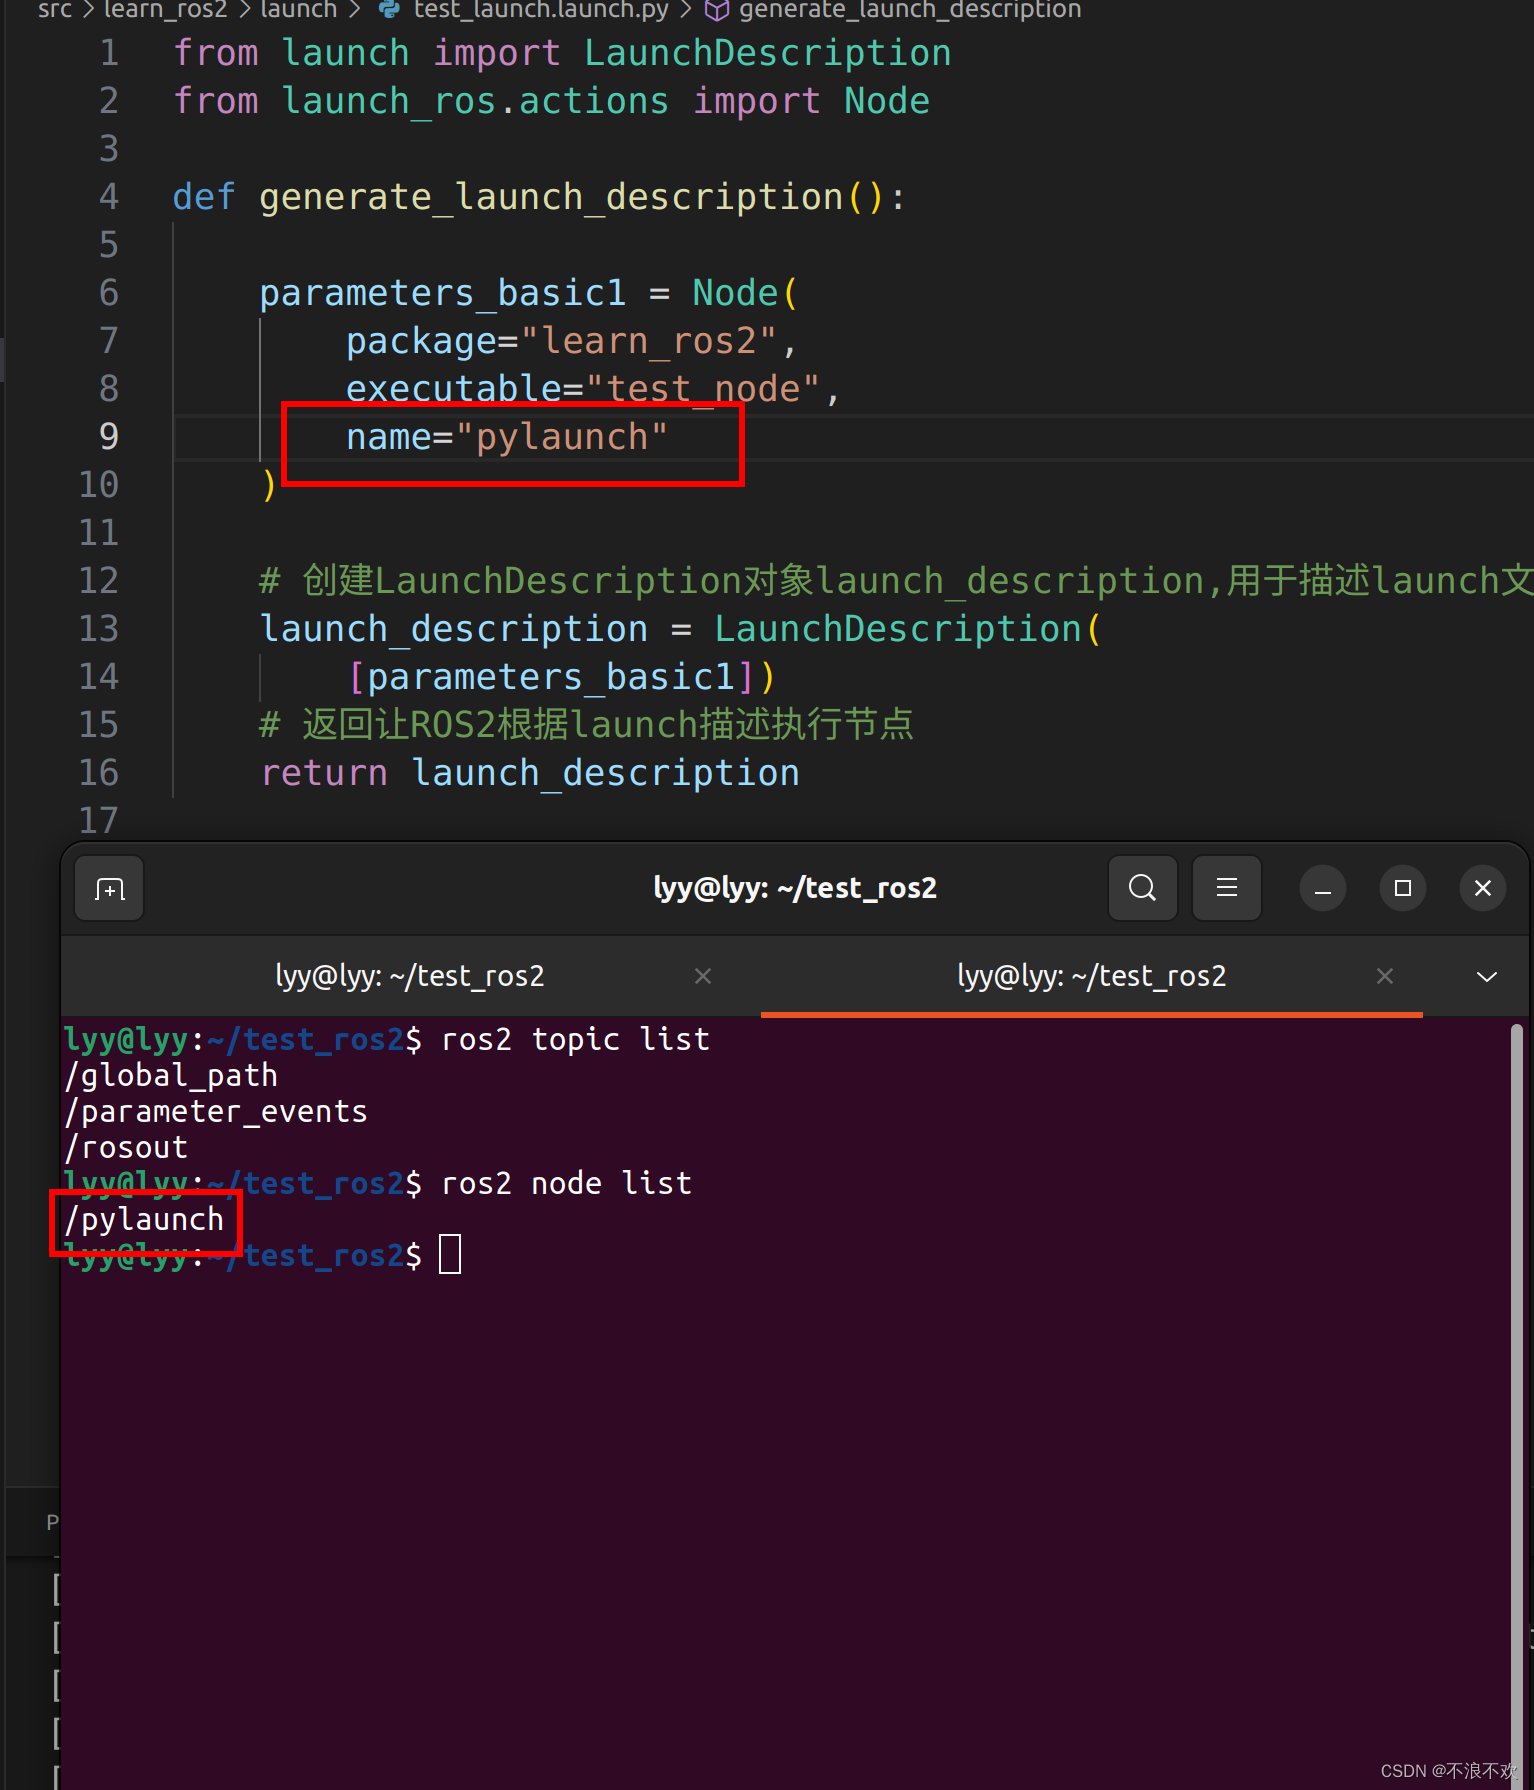
ROS2 Humble 笔记(十二)launch 文件与 namespace 启动多个节点 - 技术栈
ROS2 Jazzy Tutorial: Develop and Control Gazebo Model of Mobile Robot ...
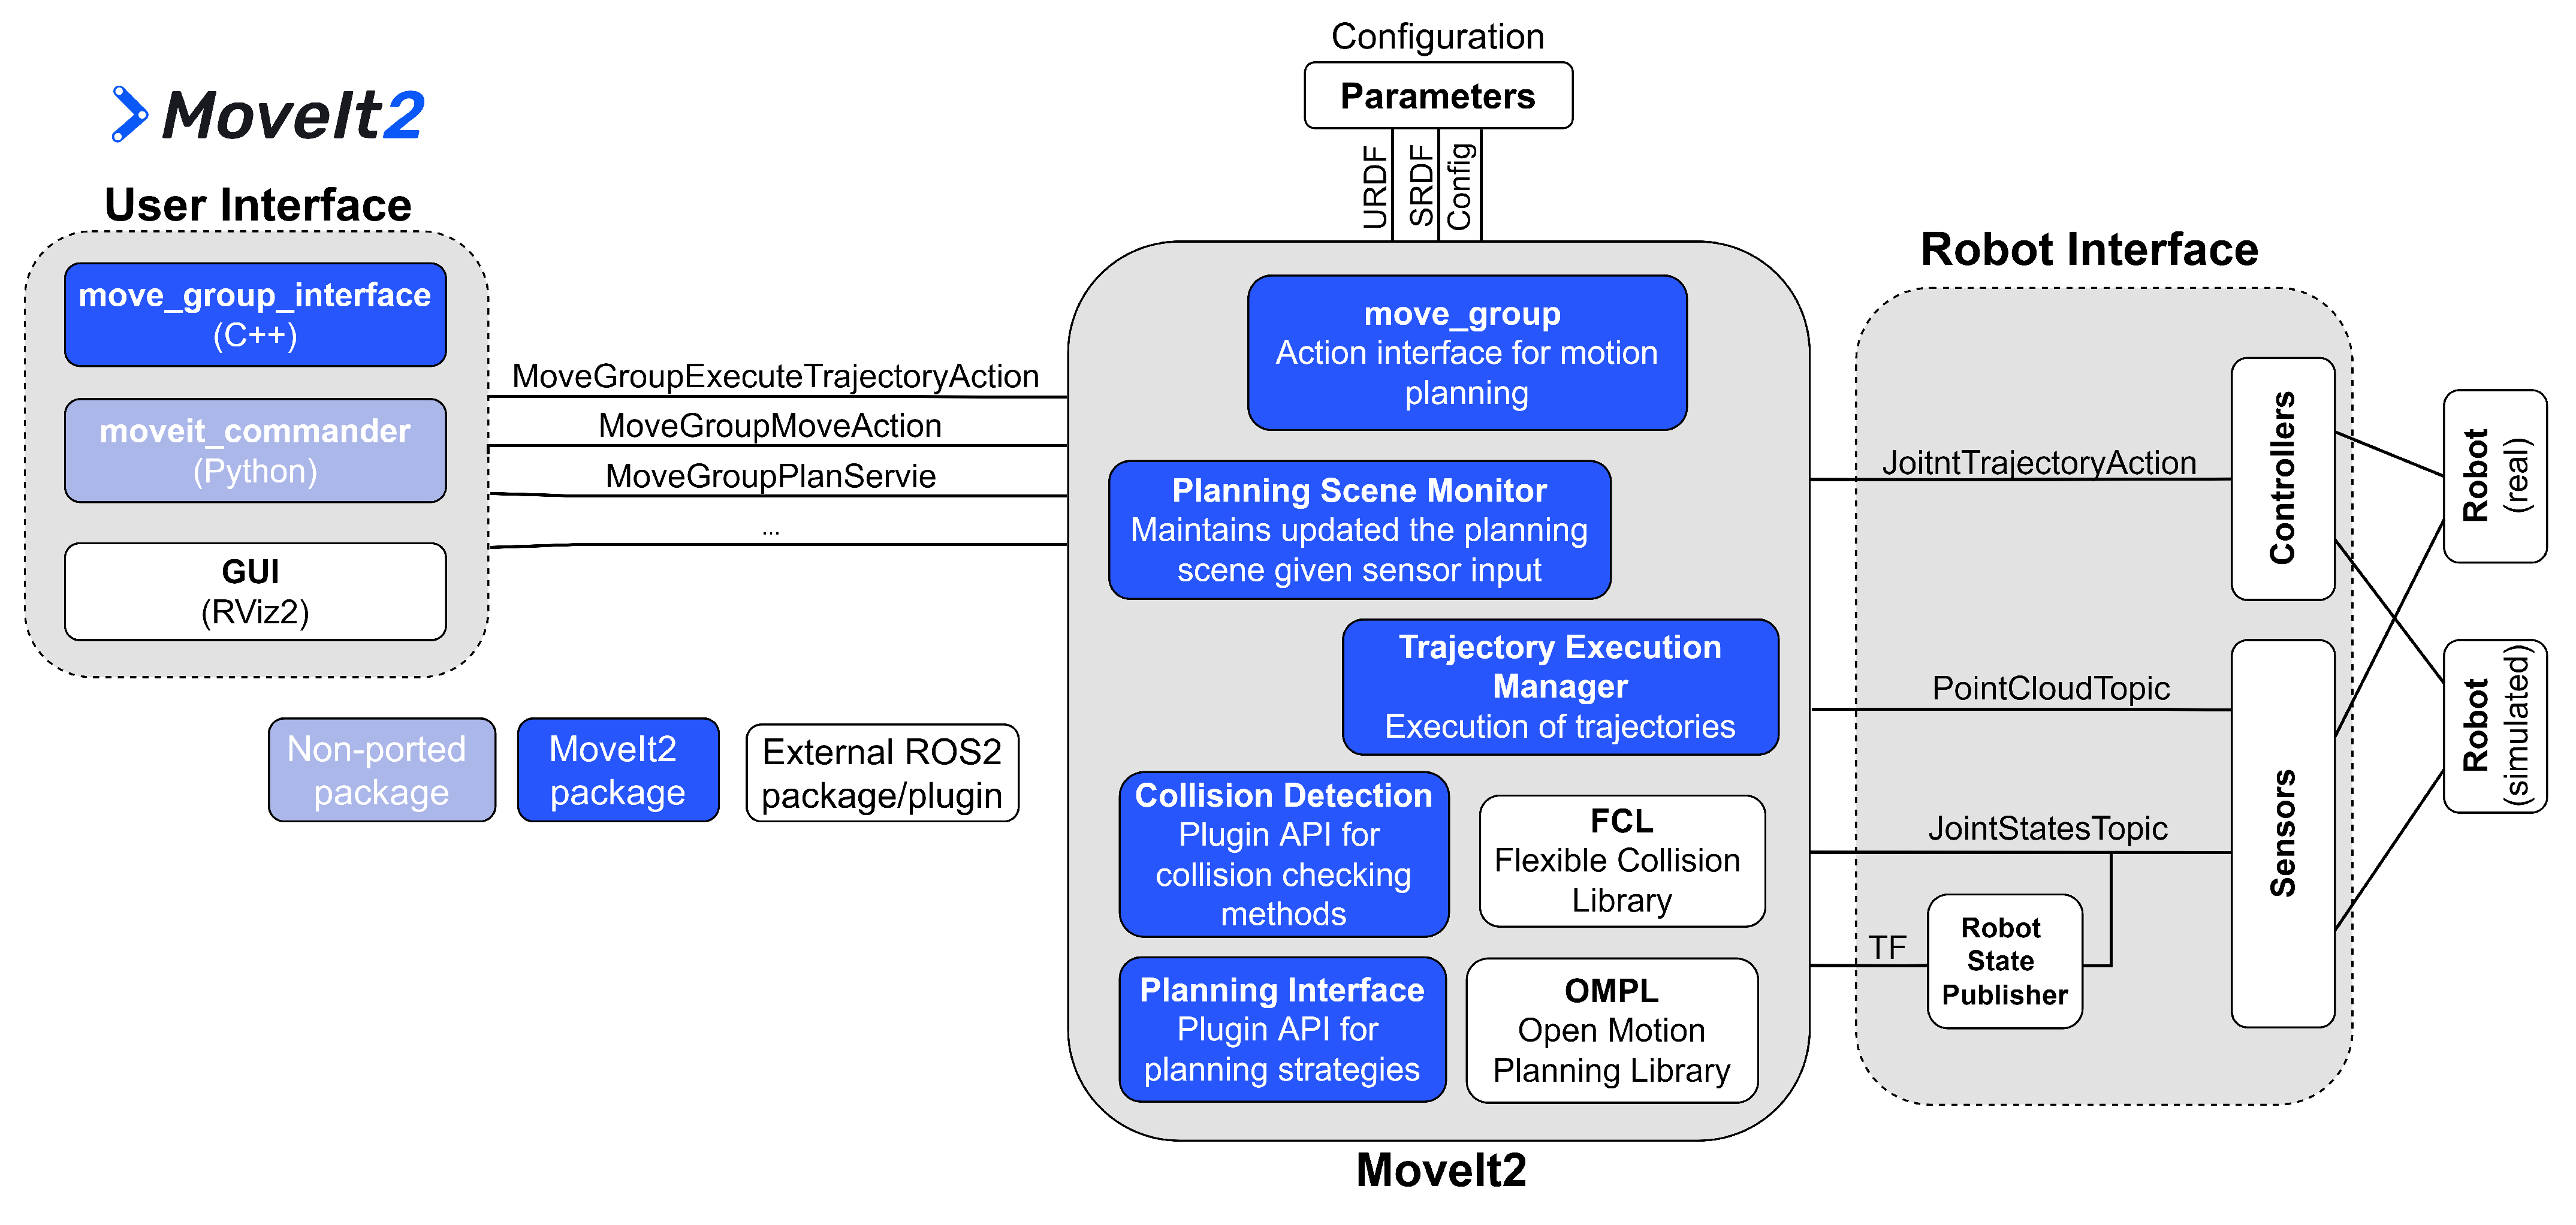
Integrating NVIDIA Isaac Sim and ROS 2 Humble with MoveIt for Advanced ...
Python Tkinter Tutorial
ROS2 Nav2 Tutorial - The Robotics Back-End
基于 Python 的 ROS2 应用开发全解析 - 知乎
Manipulate forced validation on a form question in real time ...
Using Jinja to manipulate custom SQL filter applied on a Chart
GitHub - liuX-humble/python-cheatsheets-collection: Python Data Science ...
ROS2 python编写 intel realsense D405相机节点通过launch.py启动多个相机并发送图像话题,基于 ...
[ROS2 Q&A] How to follow waypoints using nav2 #232 - The Construct
개발자와 함께하는 ROS2 Humble Topic 이해하기, ROS2 명령어-3
Getting Started with ROS2: What is a ROS2 Service? Implementing ROS2 ...
openEuler 安装 ROS2 Humble【编译系统】_openeuler ros-CSDN博客
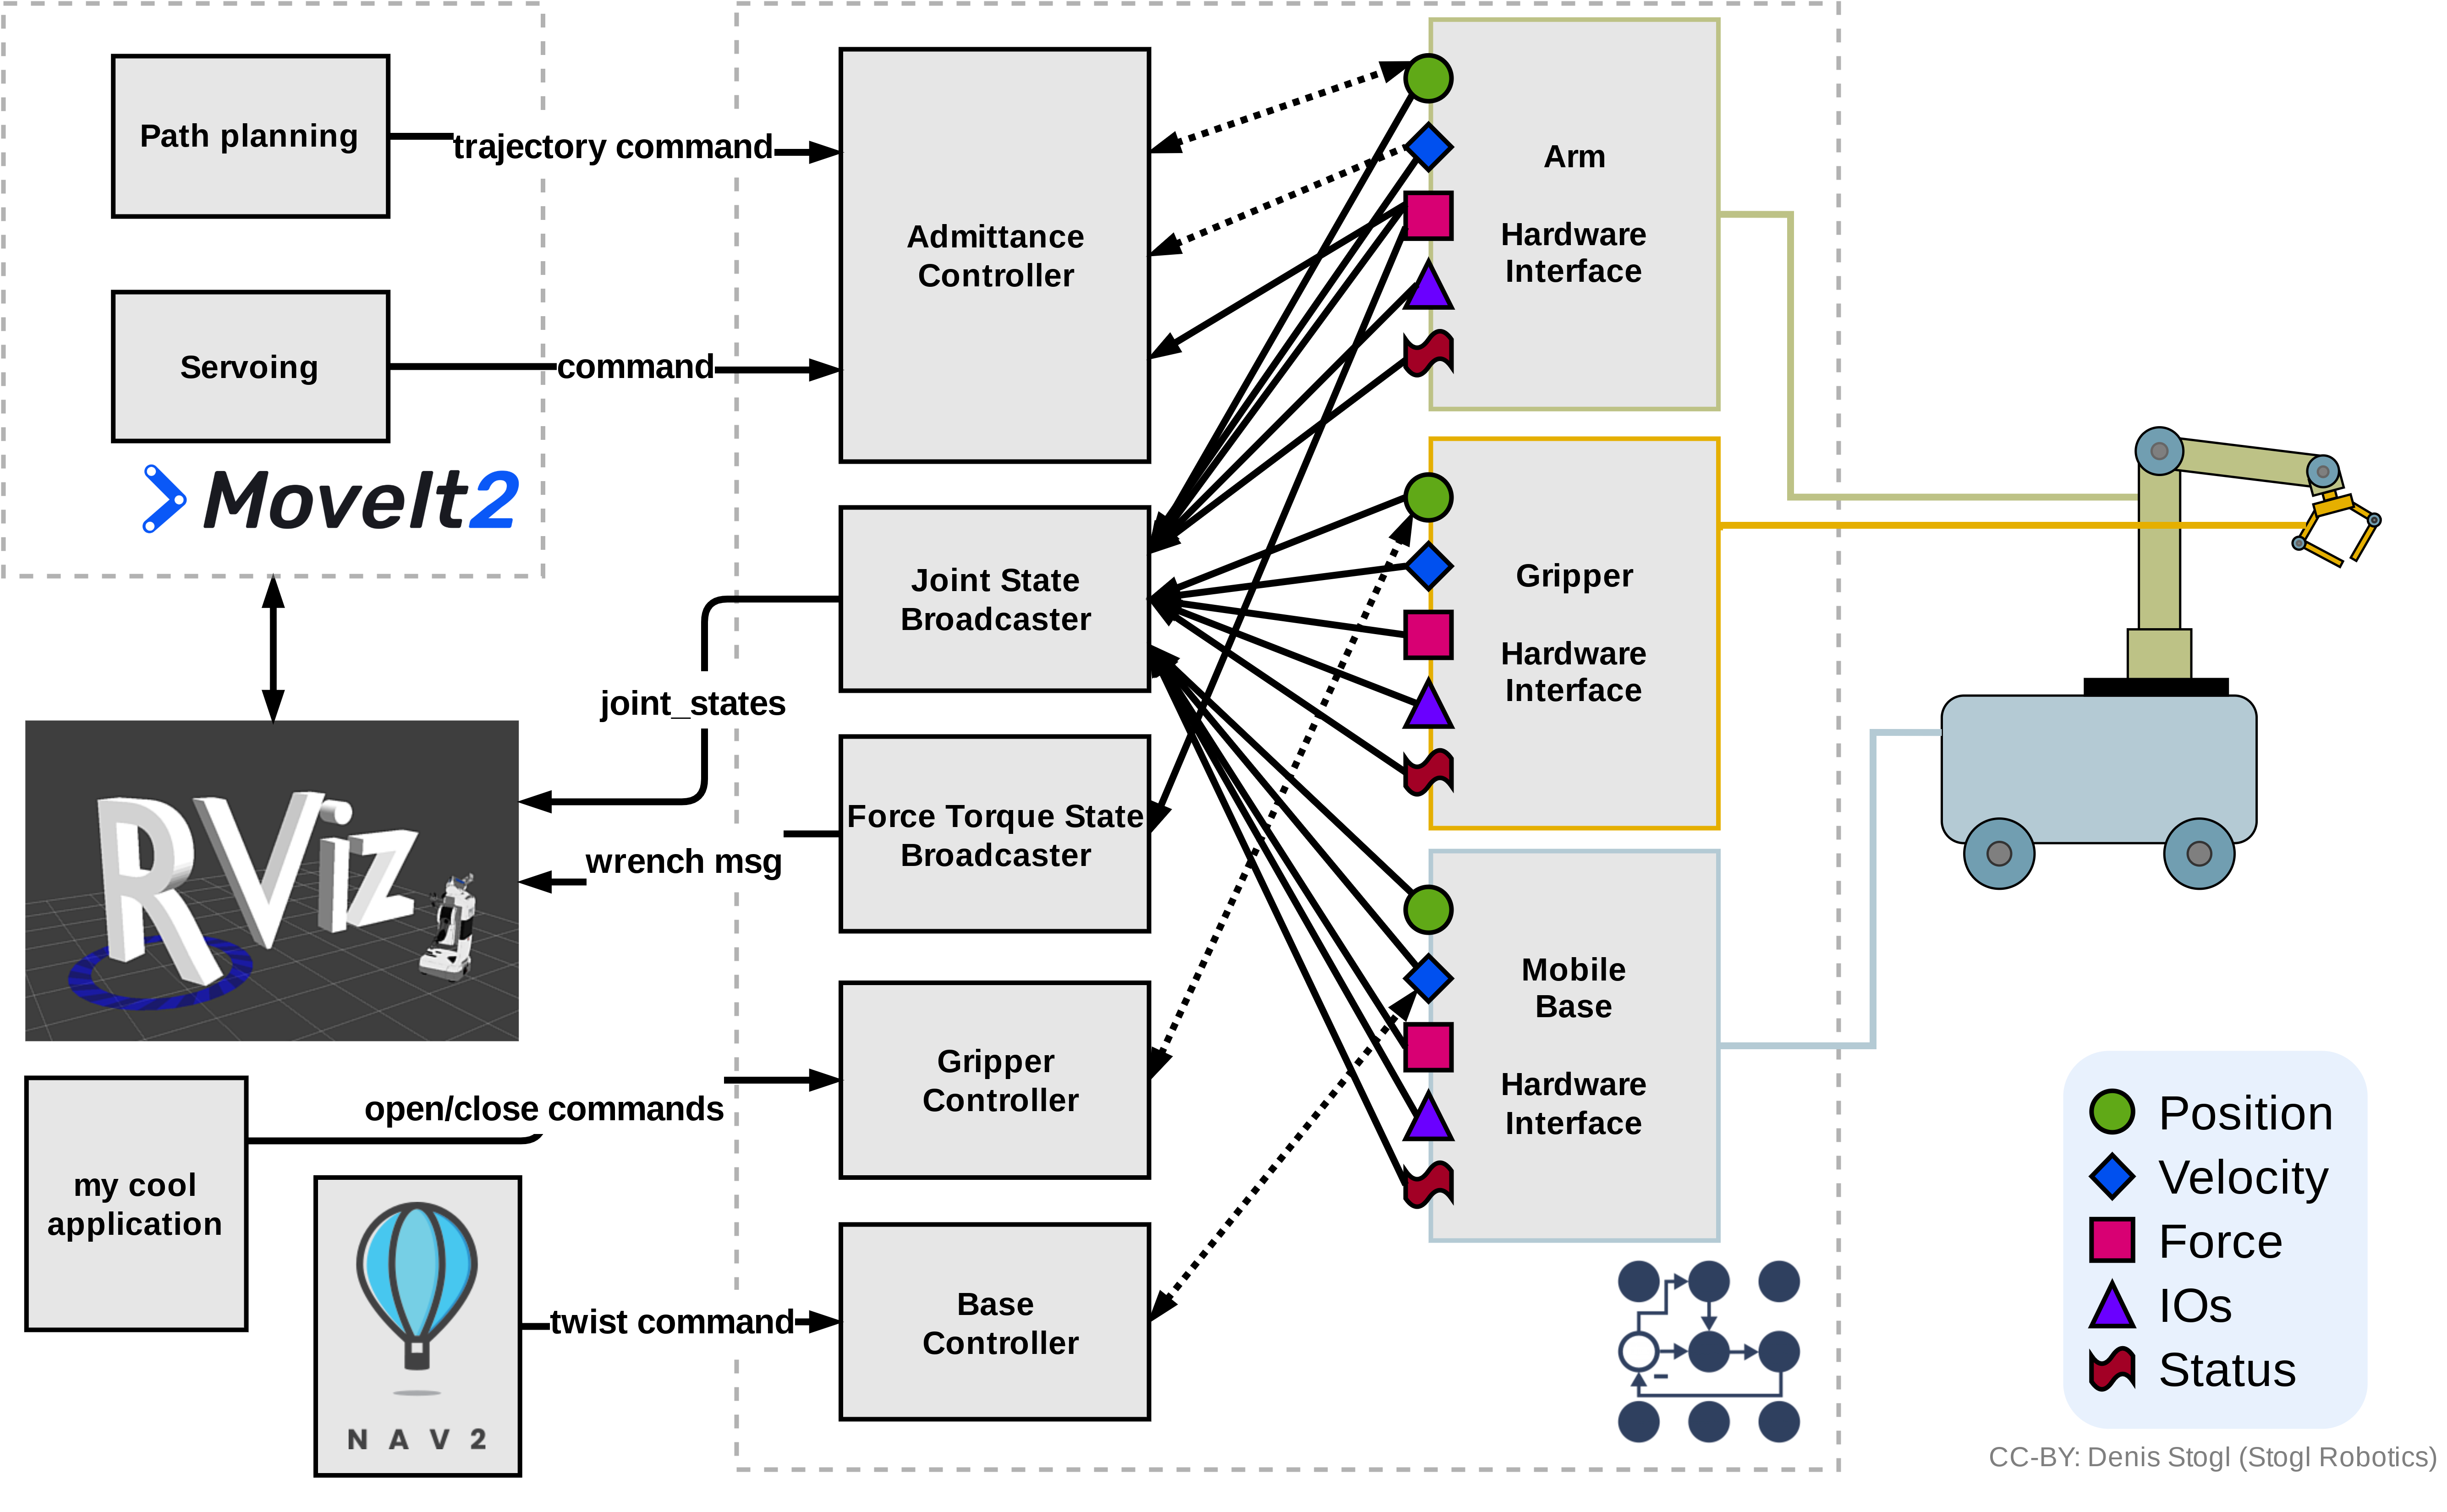
Resources — ROS2_Control: Humble Feb 2026 documentation
利用ros2 control获取gazebo中六维力传感器数据,使用force_torque_broadcaster_力传感器在ros中的数据 ...
ROS2 Transform Trees and Odometry — Isaac Sim Documentation
Using a URDF in Gazebo — ROS 2 Documentation: Humble documentation
Robotic Arms Workflow of MoveIt2 with ROS2 for Motion Planning - YouTube
ROS2 Cartographer纯定位导航遇到的问题-CSDN博客
ROS2 机器人操作系统入门和安装以及如何使用 .NET 进行开发 - 董川民
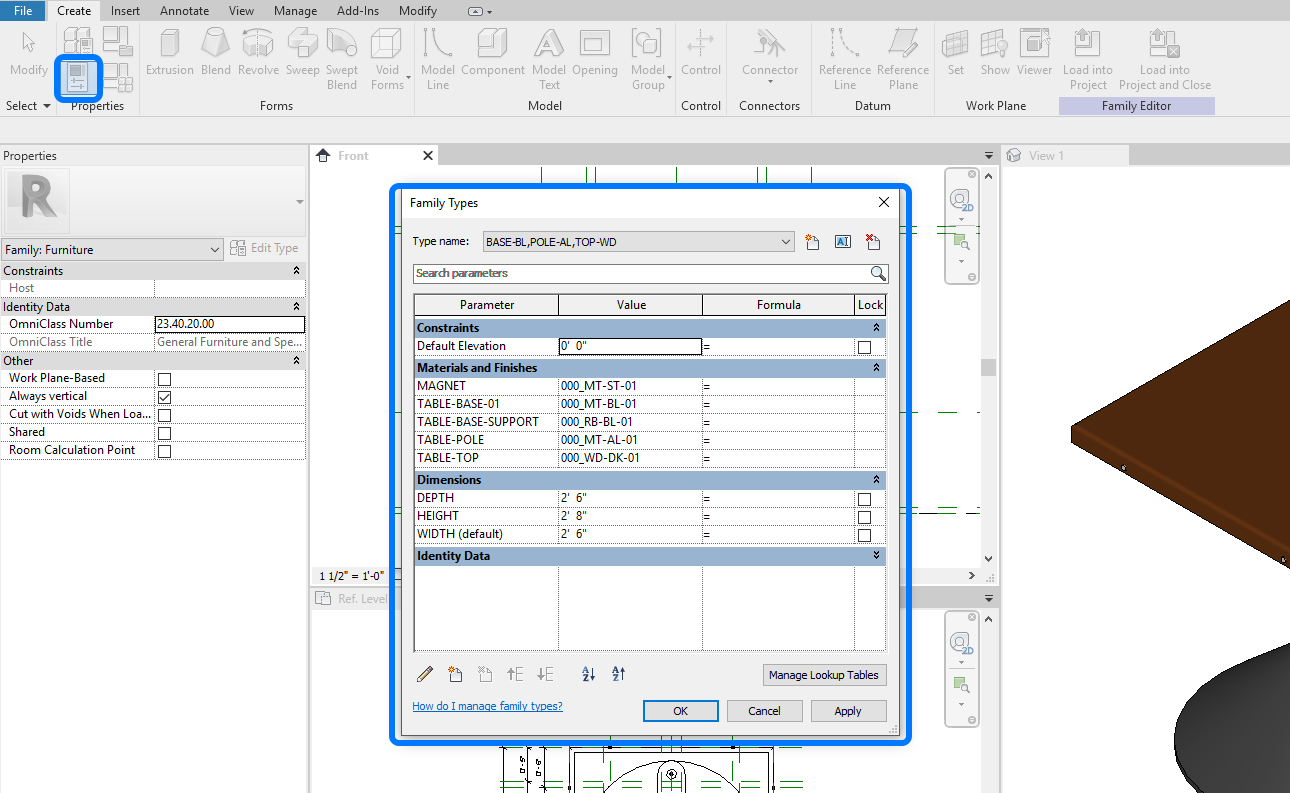
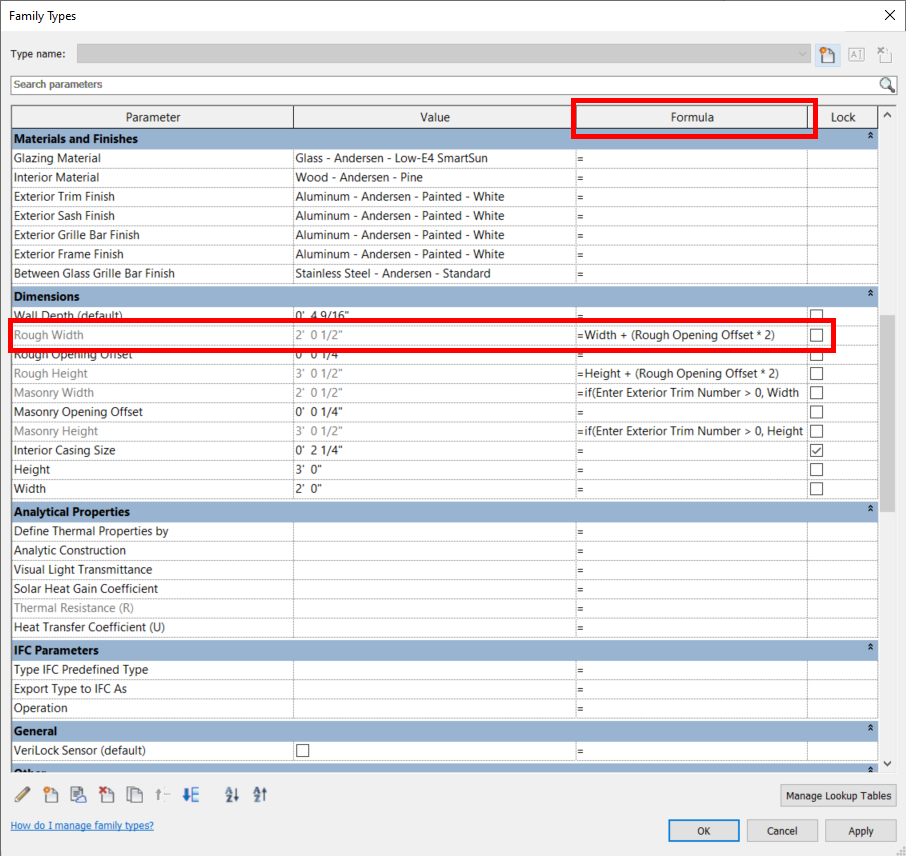
Pi Revit Formula at Milla East blog
Simulink_PX4_with_ROS2_Tutorial/utilities/launchMulti ...
Python Data Types - Spark By {Examples}
GitHub - TJU-Aerial-Robotics/YOPO-Rally: A Sim-to-Real Single-Stage ...
GitHub - NguyenLeMinh-dev/Unitree-Lidar-L1-SLAM: Using Unitree Lidar L1 ...
ros2 launch gazebo_ros gazebo.launch.py无法启动_gazebo打不开-CSDN博客
ROS 2 Humble Hawksbill 之 f1tenth gym-云社区-华为云
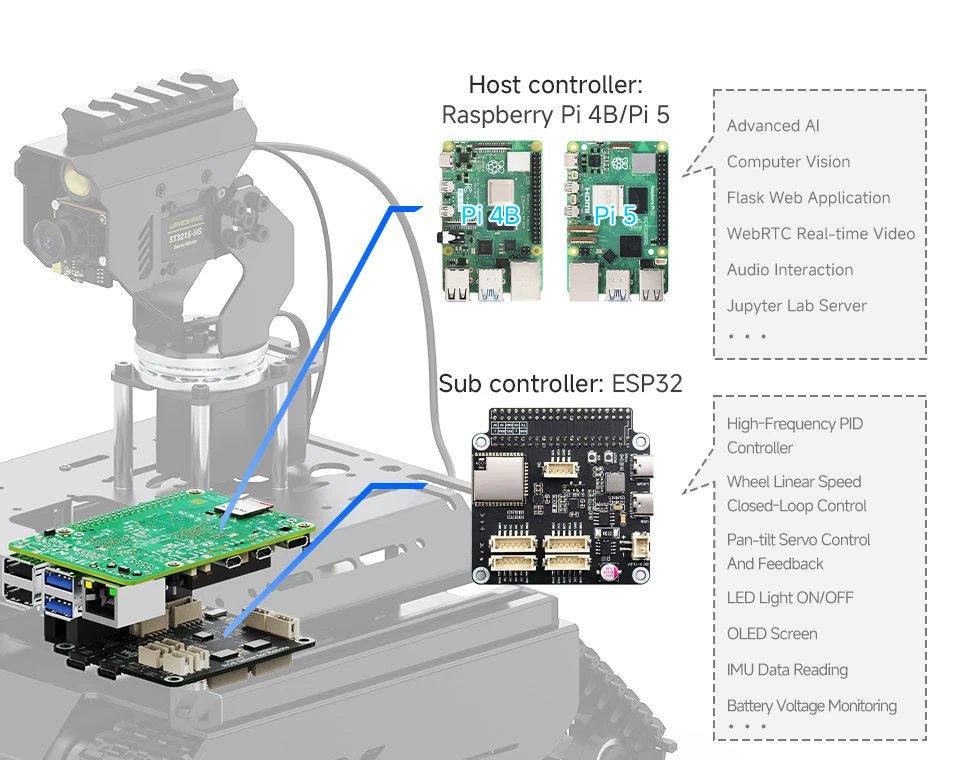
Raspberry Pi 4/5 AI robot with tracked wheels for off-road driving ...
Manipulation with MoveIt2 — Visualizing robot arm in simulation — 1 ...
Ubuntu22.04 + ROS2 Humble的环境配置_ros2 humbel环境配置-CSDN博客
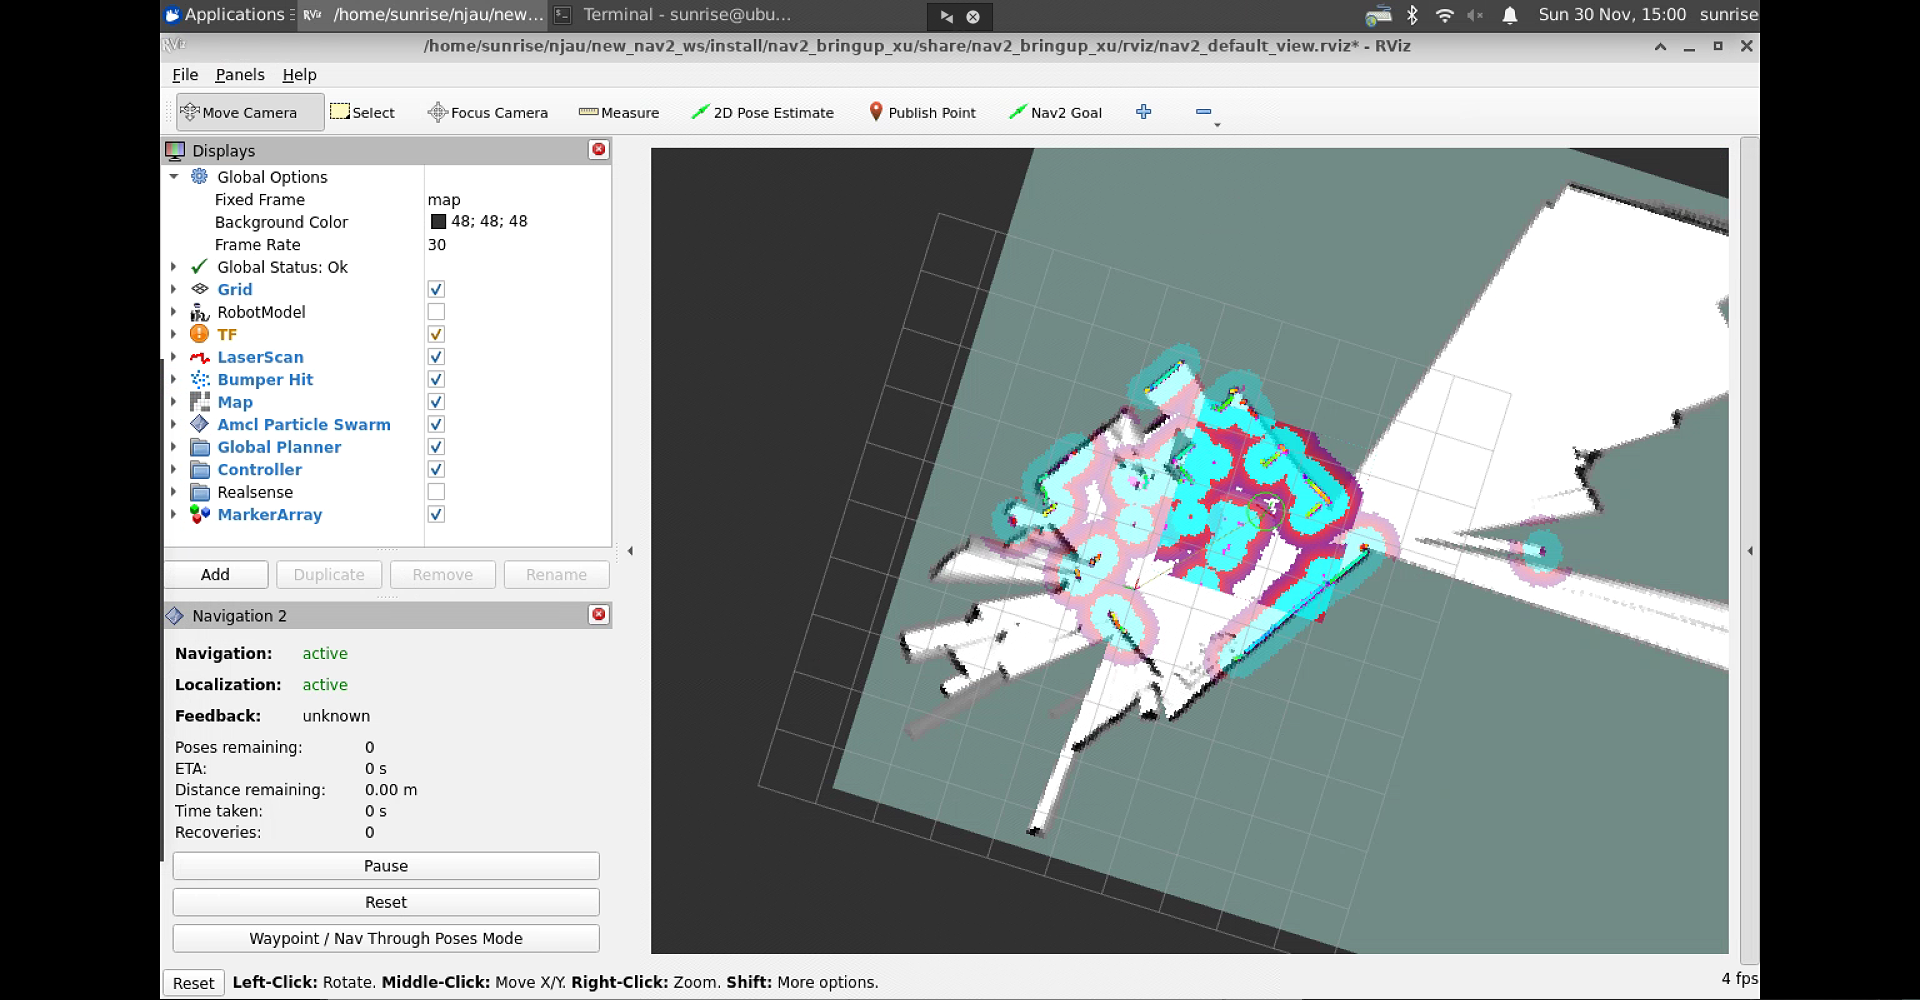
ROS 2 Navigation - Part 3 (creating Nav2 Simple demo with TurtleBot3 ...
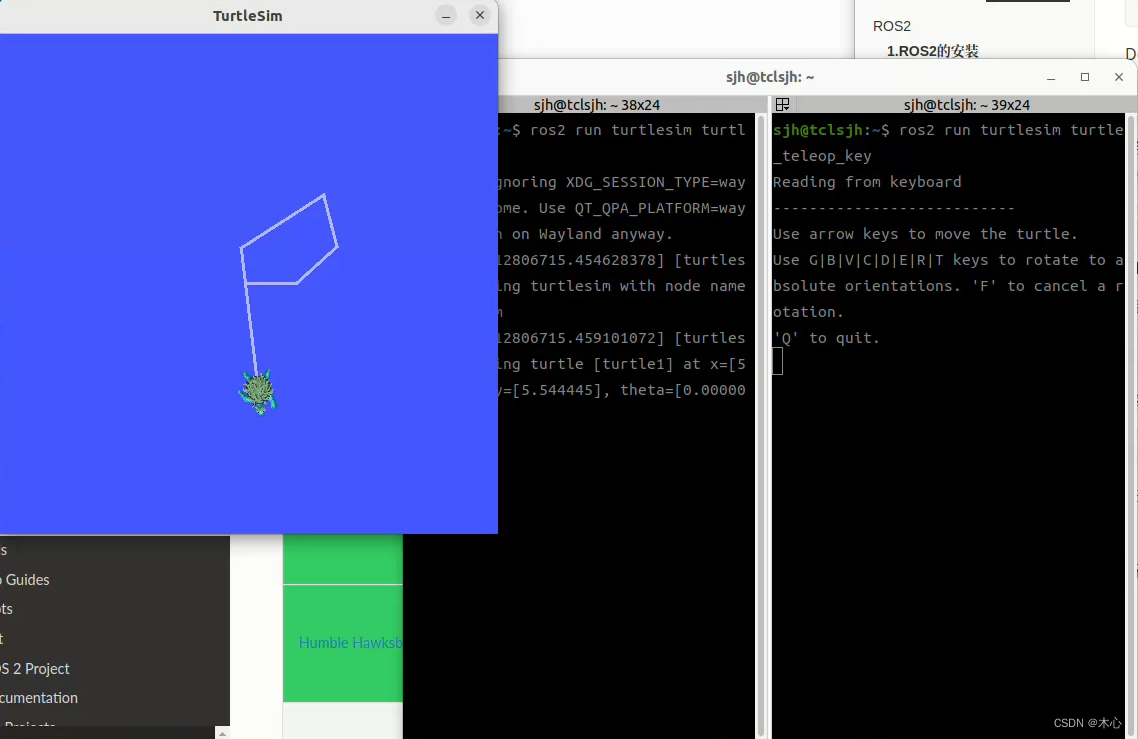
Setup ROS2 for Turtlesim🐢 - YouTube
GitHub - jiuyewxy/ros_arm_tutorials: 《ROS机械臂开发与实践》教学源码,涵盖ROS基础、ROS进阶、机械 ...
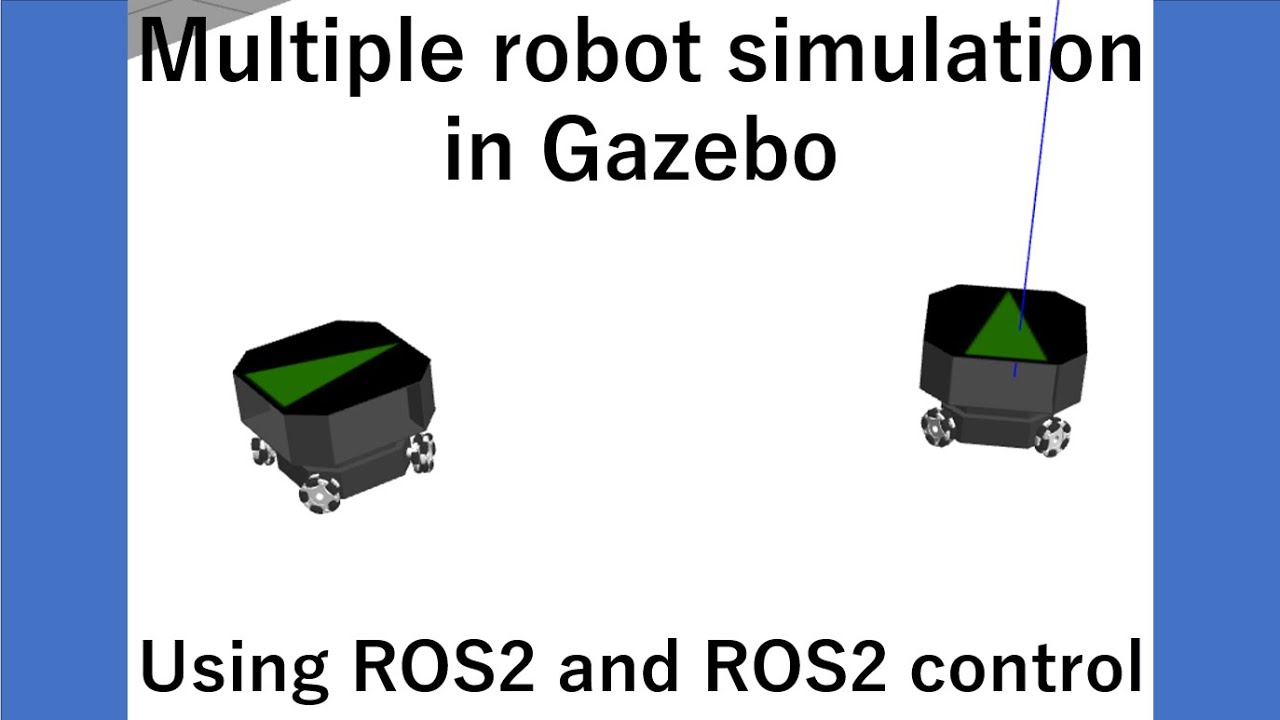
Multiple Robot Simulation in Gazebo Using ROS2 and ROS2 Control - YouTube
the 'inputs parameters' of workflow operation 'Send_an_email_(V2)' of ...
Appendix: ROS 2 — 240AR060 - Introduction to ROS
더 쉽게 프로그램 실행하세요. ROS2 Launch 파일 공략하기
Mastering Holonomic Control with NVIDIA Isaac Sim and ROS2: A Guide for ...
Robot Operating System 2 (ROS2)-Based Frameworks for Increasing Robot ...
「第2版 ROS2とPythonで作って学ぶAIロボット入門」をやってみよー!
ROS2中launch编写及参数含义(xml、python)_介绍ros 2launch-CSDN博客
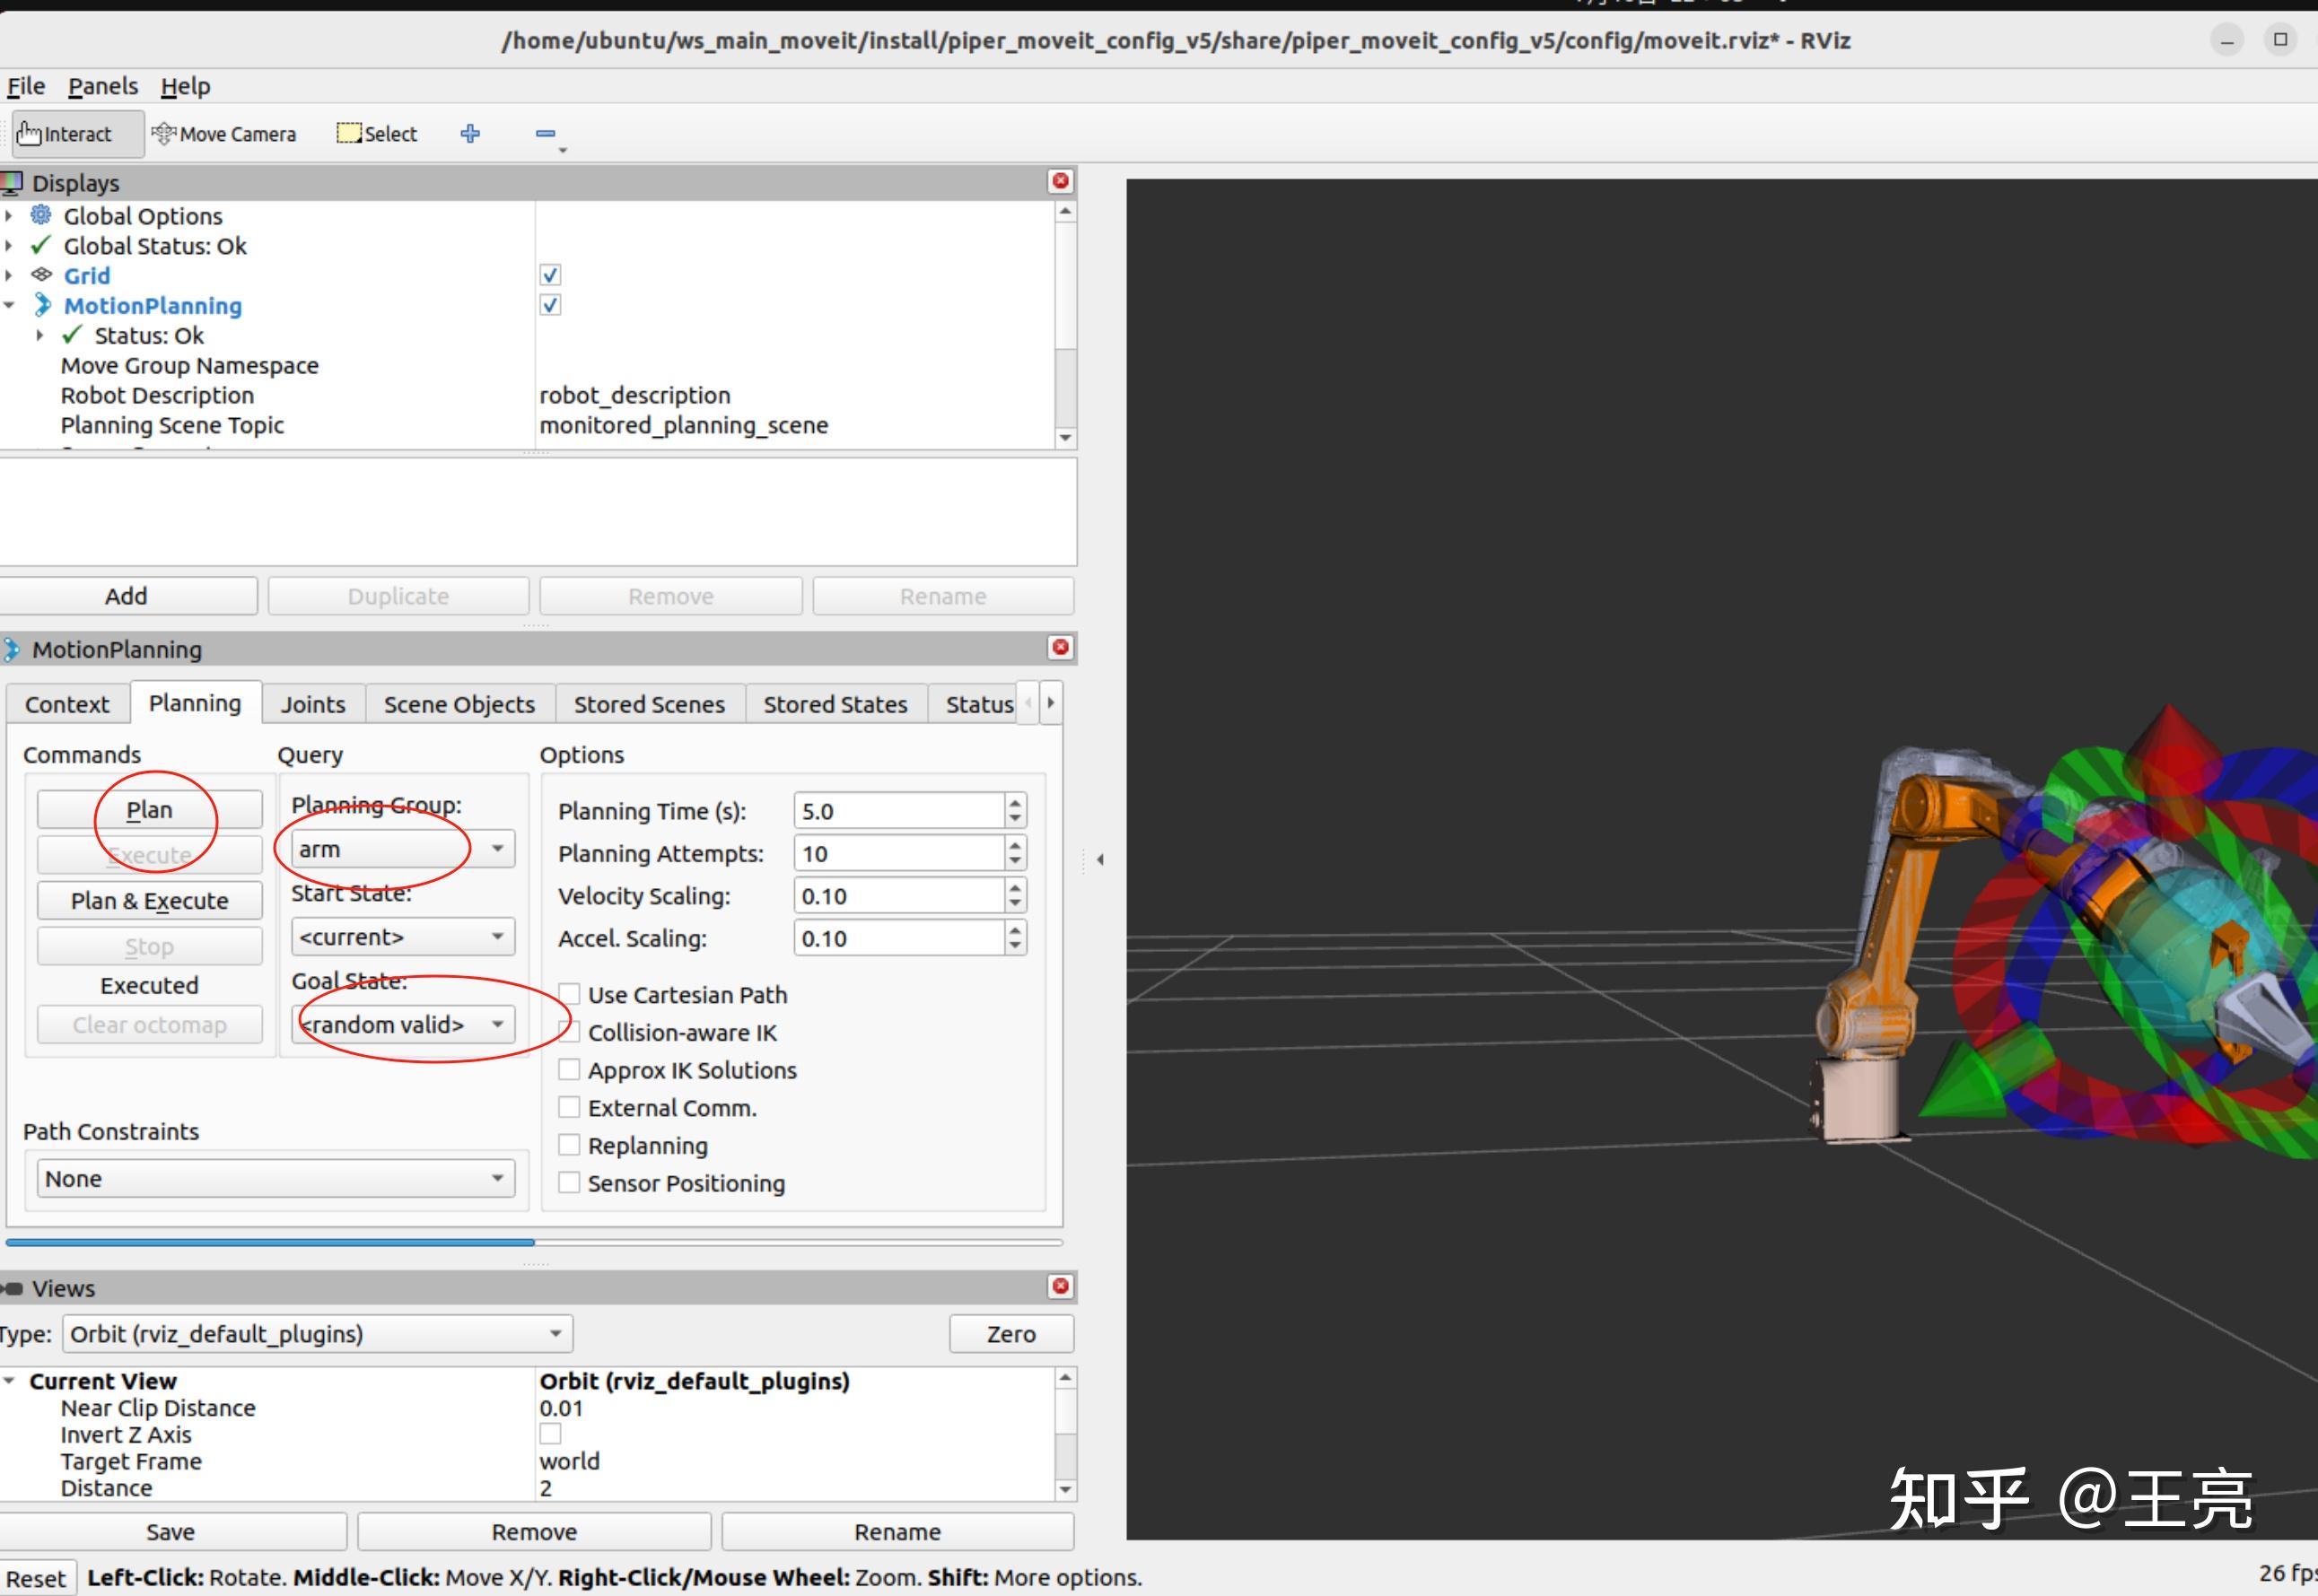
ROS2机械臂入门6-松灵piper机械臂使用 - 知乎
ROS2机器人编程简述humble-第三章-COMPUTATION GRAPH .2_humble 编程例子-CSDN博客
ROS 2机器人开发--坐标变换工具TF与可视化_ros2 tf-CSDN博客
Resources — ROS2_Control: Rolling Apr 2026 documentation
ROS2入门详解含架构对比与安装配置实践-开发者社区-阿里云
Azure Kinect DK + ROS1 Noetic使用教程-阿里云开发者社区
ROS2与openEuler入门教程-安装ROS2的humble版本 - 爱折腾-创客智造实验室
Medium
从零开始玩转Franka Panda机器人 – 源码巴士
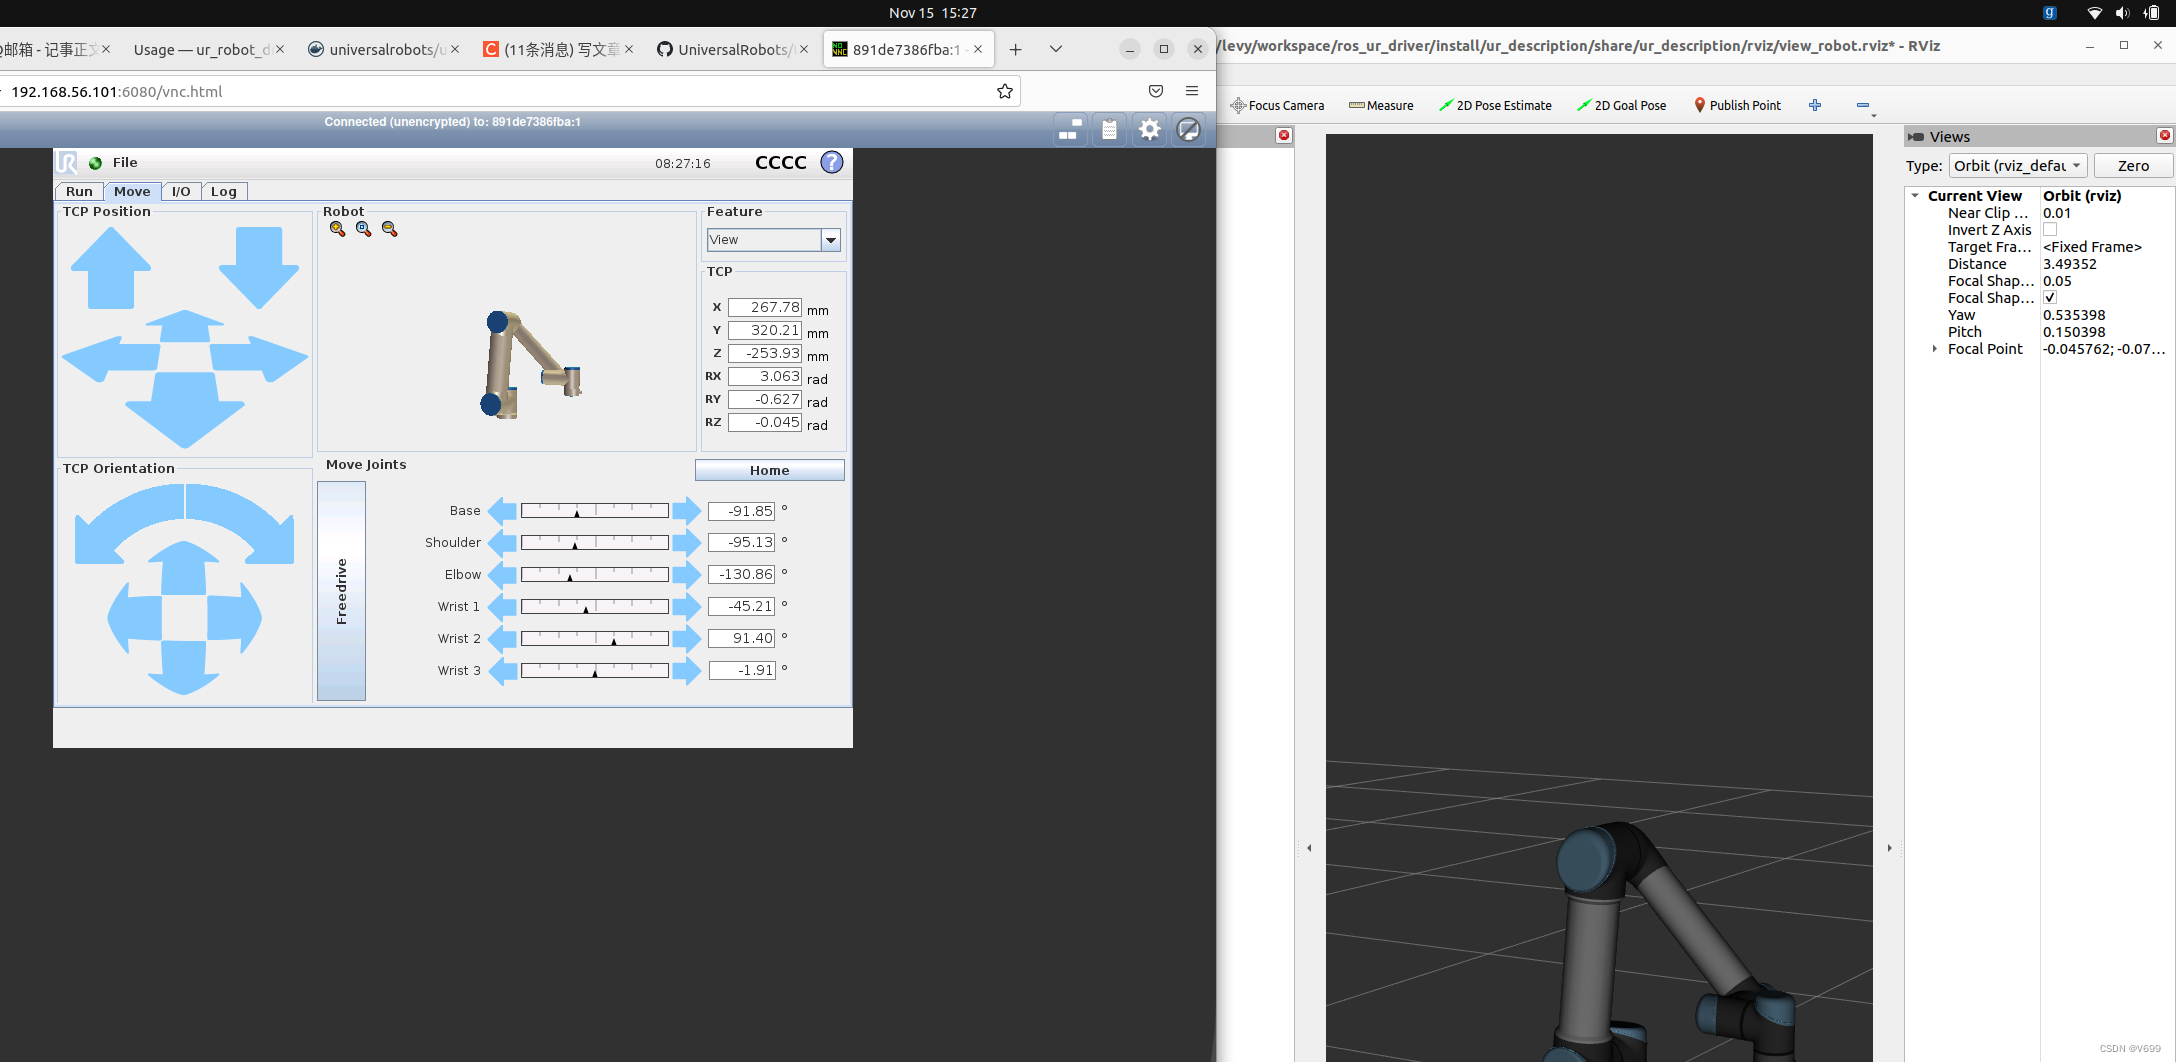
详细Ubuntu 22.04 配置最新UR机械臂仿真环境(ros2-humble, ur-sim, ur-ros2-driver) – 源码巴士
pycharm中调试python-ros2工程 - 知乎
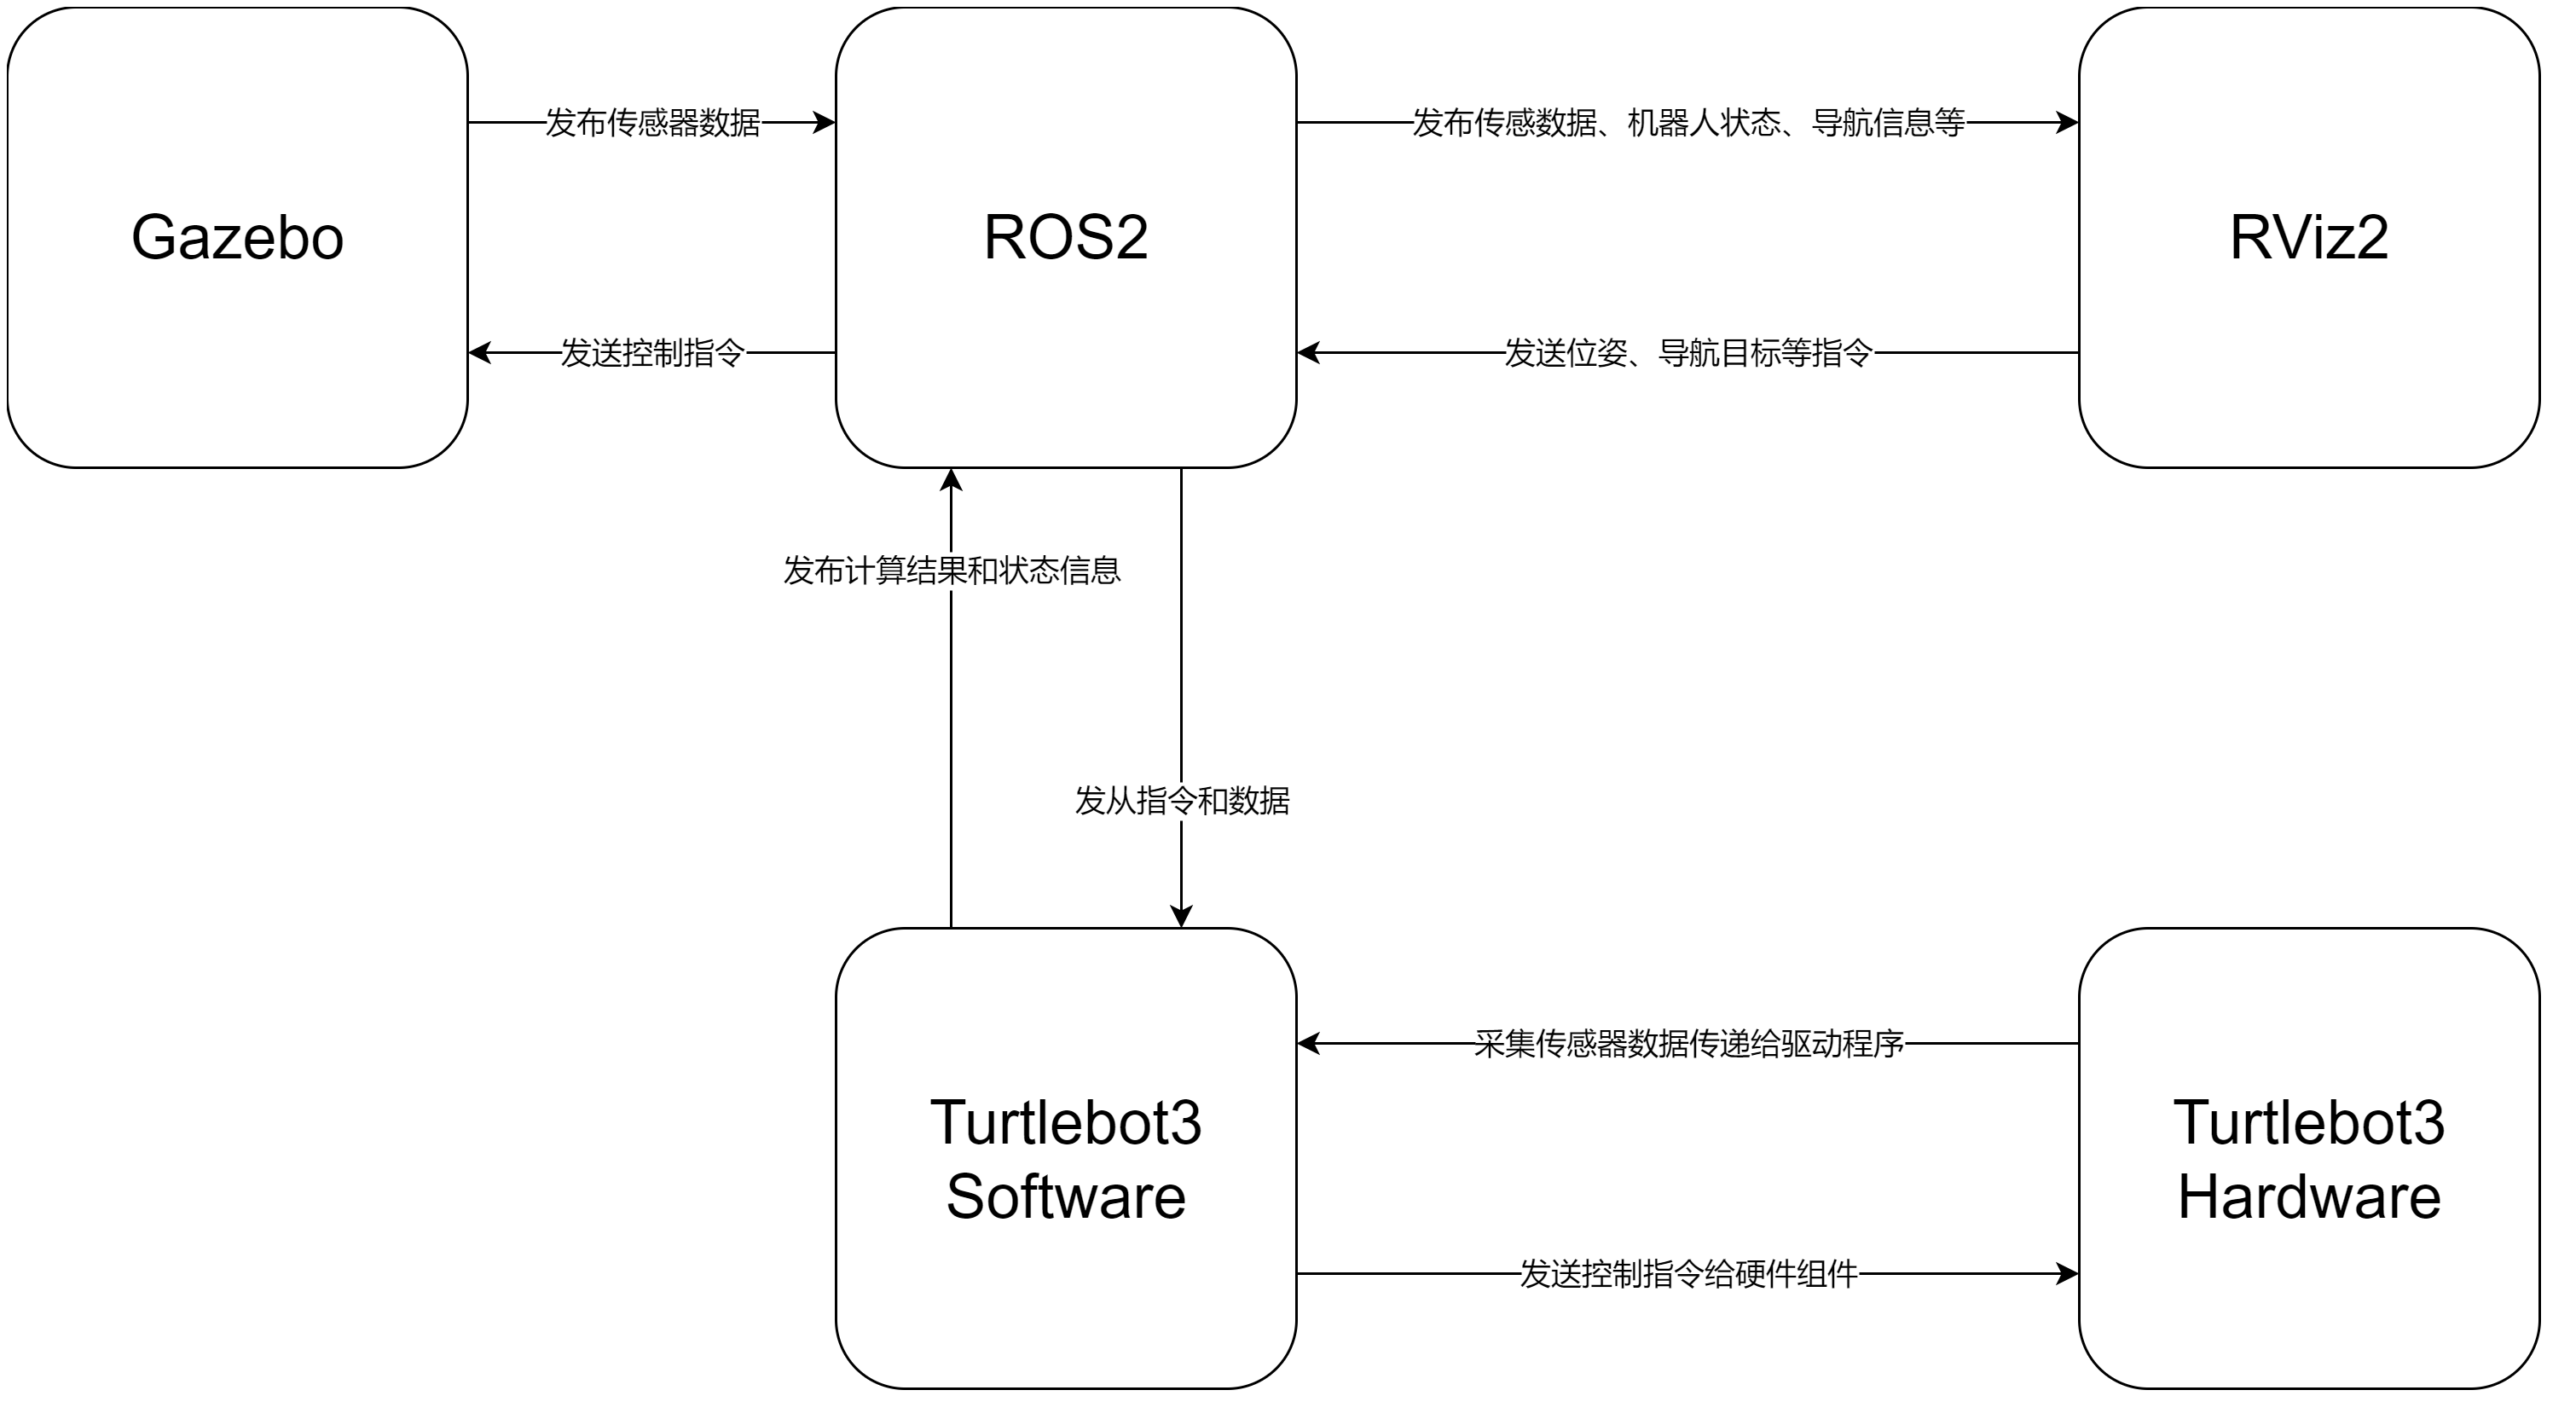
ROS2(1):基于ROS2+Gazebo+RViz2的TurbleBot3仿真开发环境搭建 - ArnoldLu - 博客园
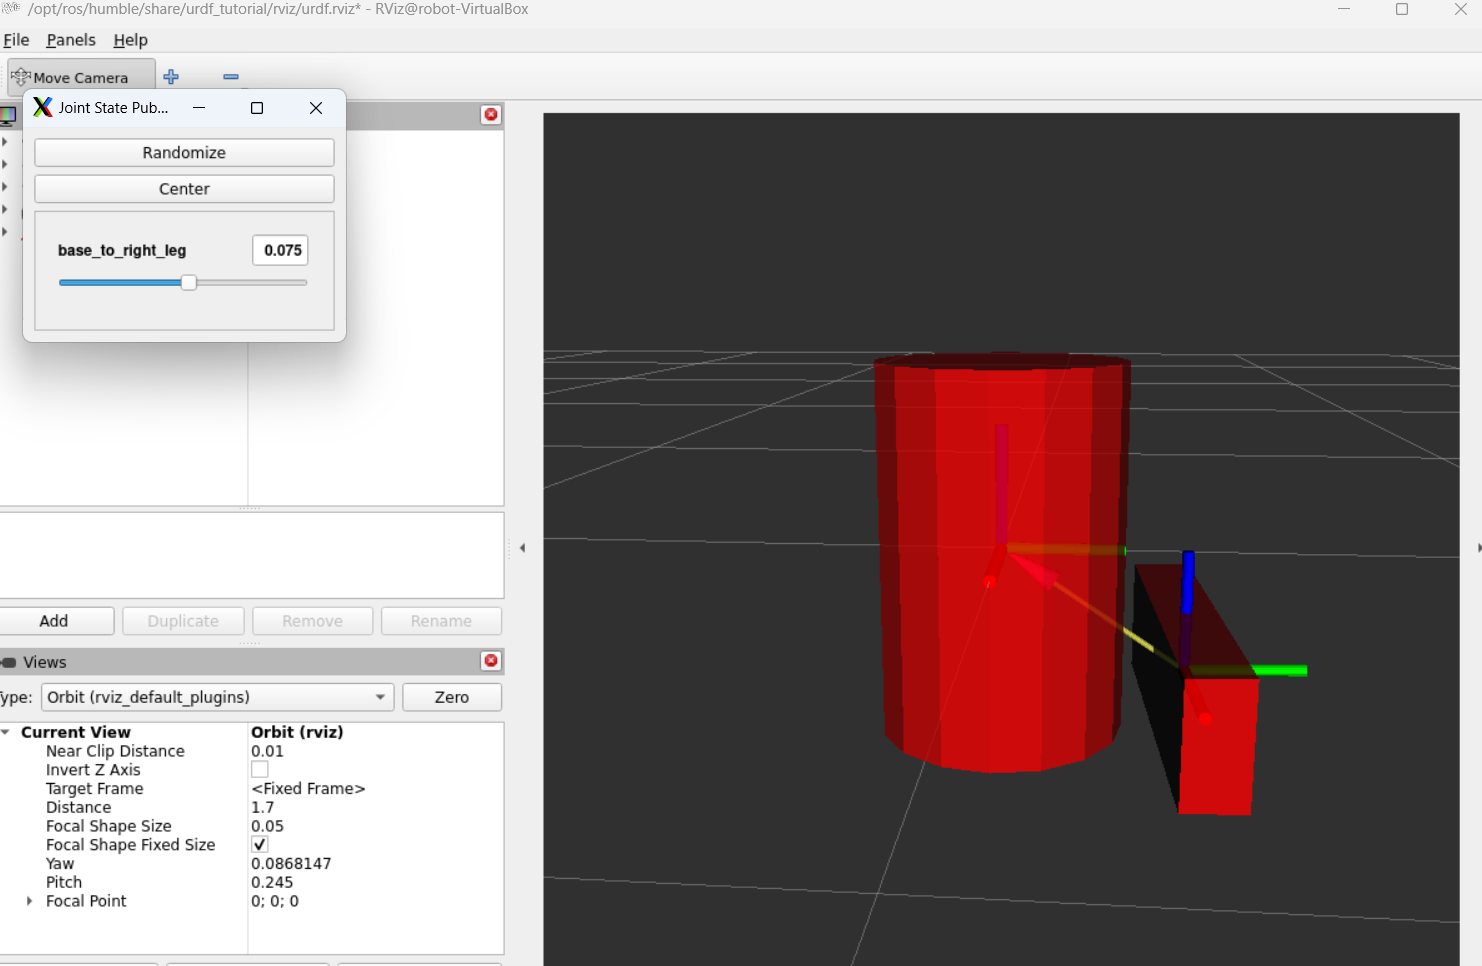
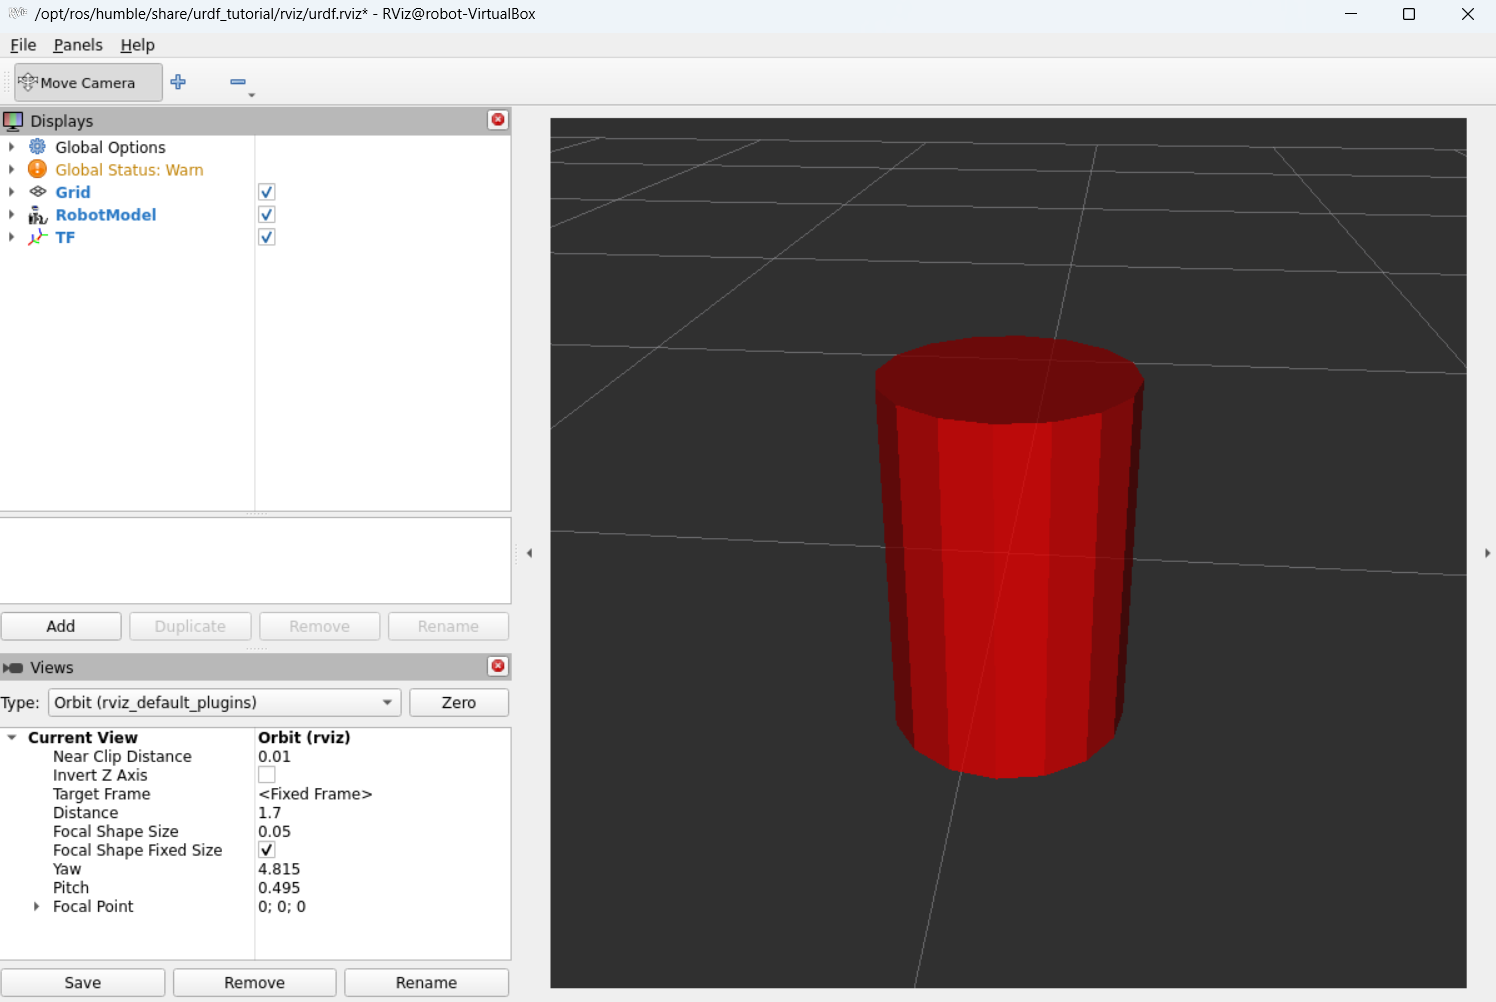
ROS2[Humble] -- URDF Tutorial- 02-multipleshapes_rosemary512-智能体开发者社区
问题处理——在ROS2(humble)+Gazebo+rqt下,无法显示仿真无人机的相机图像 - 技术栈
ROS2[Humble] -- URDF Tutorial- 01-myfist_ros humble安装urdf-CSDN博客
[ROS2 Humble] Multi Floor Navigation with Gazebo and Nav2 - YouTube
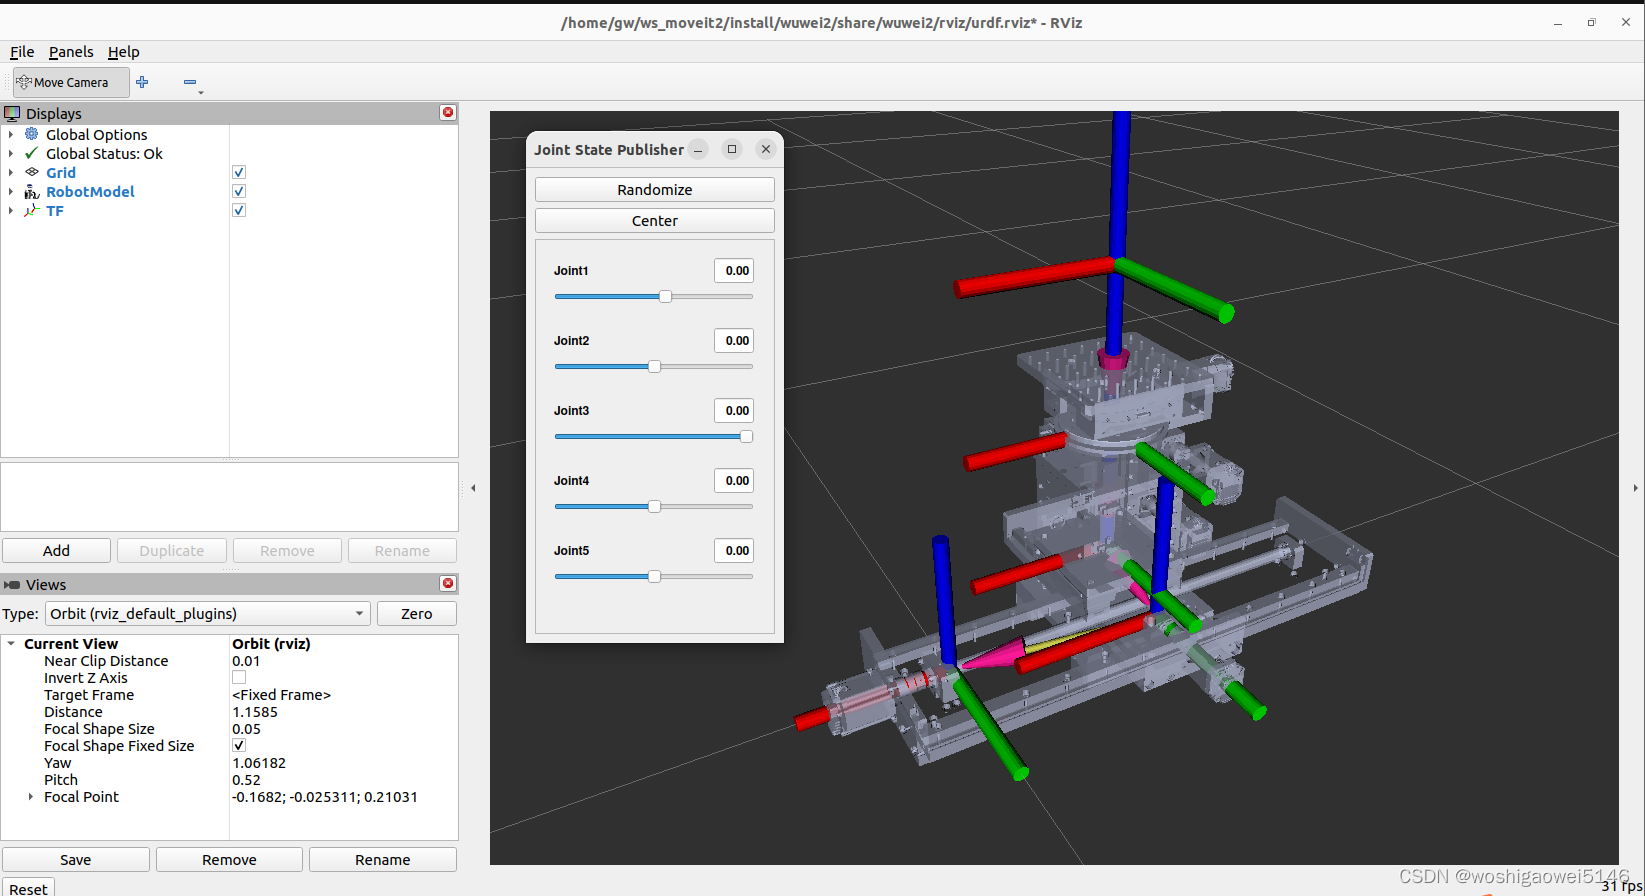
Solidworks导出URDF总结(Humble)_sw导出的urdf文件在ros2 humble显示-CSDN博客
ROS MoveIT2(humble)安装总结_moveit2安装-CSDN博客
ROS 2 Jazzy Jalisco 操作工具 MoveIt2 总结和习题_ros2 jazzy moveit2-CSDN博客