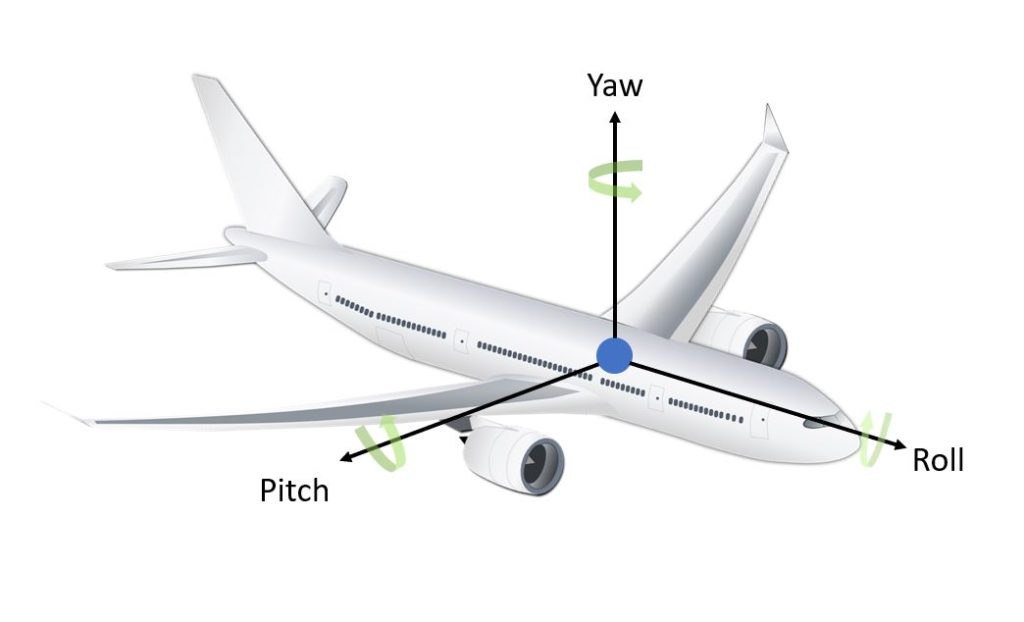
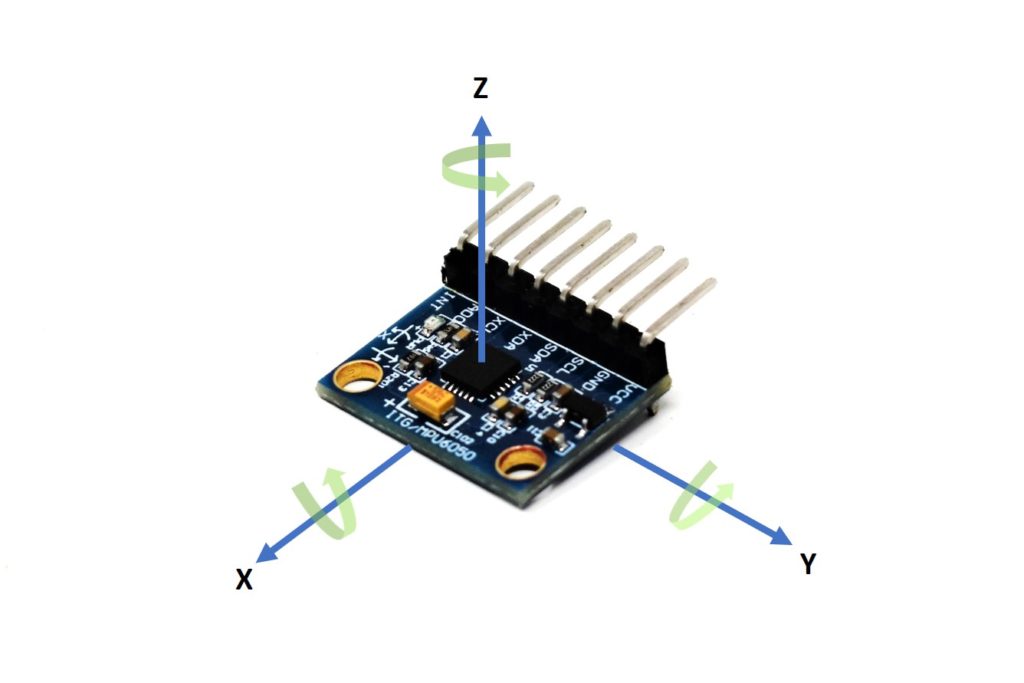
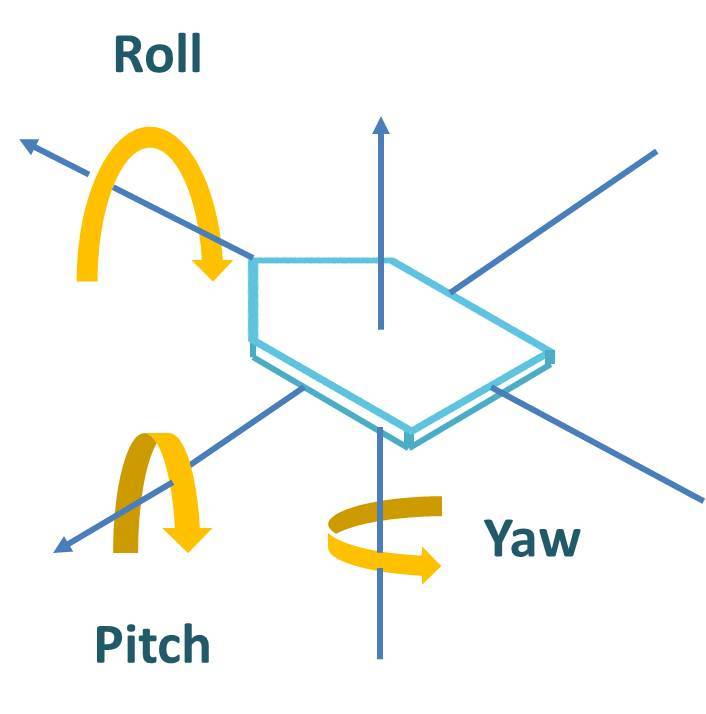
Measure Pitch, Roll, Yaw with MPU6050 + HMC5883L & ESP32
Roll, Pitch And Yaw , Measure Pitch, Roll, Yaw with MPU6050 + HMC5883L ...
High-Accuracy Pitch, Roll, Yaw with ESP32 & BNO08x IMU
Measuring Roll, Pitch, and Yaw Using 3-Axis Gyro on the MPU6050 ...
Measure Angles with MPU6050 and ESP32 (Part 2): 3D Animation | by ...
Roll, Yaw & Pitch using MPU6050 - YouTube
Measure Pitch Roll and Yaw Angles Using MPU6050 and Arduino - YouTube
Measure Pitch Roll and Yaw Angles Using MPU6050 and Arduino
Mpu6050 Output Yaw Pitch And Roll With Arduino – GIDK
gyroscope - MPU6050 output yaw pitch and roll with Arduino - Stack Overflow
Calculating Roll, Pitch and Yaw from Gyros on Our Arduino MPU6050 IMU ...
Trouble with getting Yaw angle from MPU6050 Gyroscope - Programming ...
Measure Roll pitch and yaw with mpu 6050 / gyroscope on serial monitor ...
How to Measure Roll Pitch and Yaw with MPU 6050 and Arduino on 16*2 ...
Roll, Pitch e Yaw con MPU6050 - Arduino | Giuseppe Caccavale
MPU6050 Gyroscope Roll Pitch and Yaw with Arduino - YouTube
Measure Angles Easily with MPU6050 and ESP32: Part 1 - DEV Community
In-Depth: Interface MPU6050 Accelerometer & Gyroscope Sensor with Arduino
Measure Angles Easily with MPU6050 and ESP32: Part 1 - Library ...
Arduino + MPU6050 + HMC5883L - Sensors - Arduino Forum
Measure Angles Easily With MPU6050 and ESP32: Part 1 - Library ...
Sensor Fusion (MPU6050 + HMC5883L) || Kalman Filter || Measure Pitch ...
Yaw Pitch Roll Mpu6050 at Luca Barrow blog
MPU6050 Accelerometer and Gyroscope with Arduino Uno - ProteShea
MPU6050 pitch, yaw, roll - Wokwi ESP32, STM32, Arduino Simulator
Interfacing MPU6050 Accelerometer/Gyroscope with Arduino
How to Interface MPU6050 with the Arduino - Electronic component at low ...
ESP32 MPU6050: Accurate angle readings with i2cdevlib | ShillehTek
Estimating angle of Roll with an MPU6050 accelerometer - Programming ...
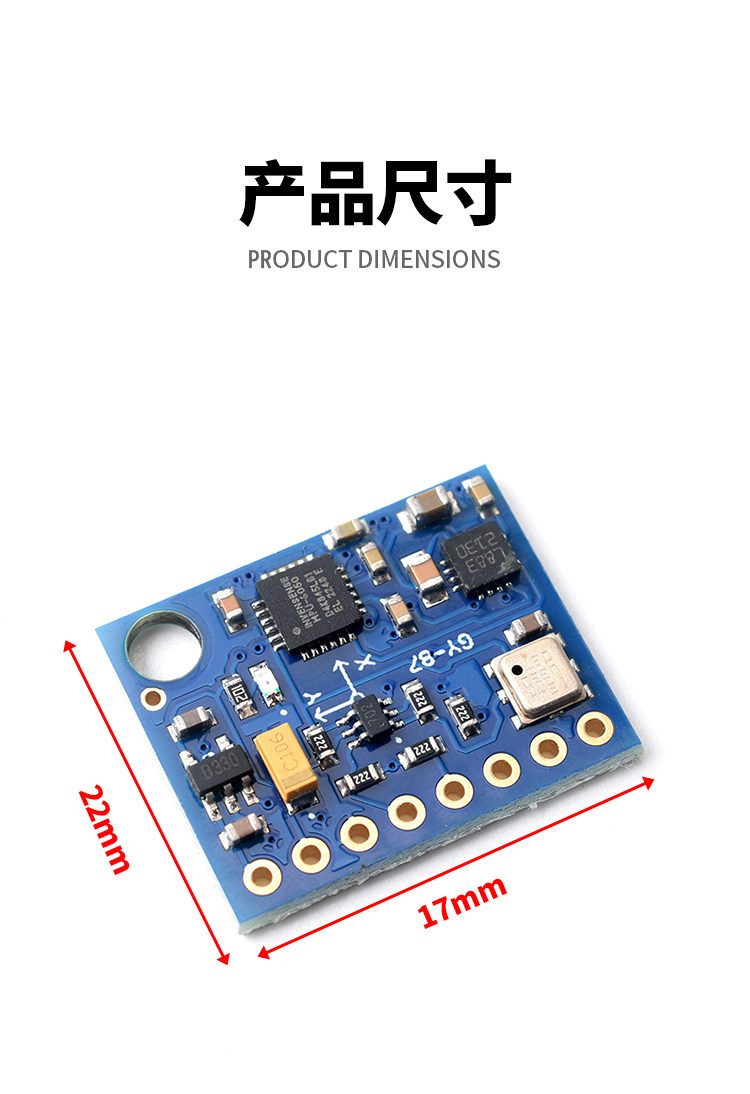
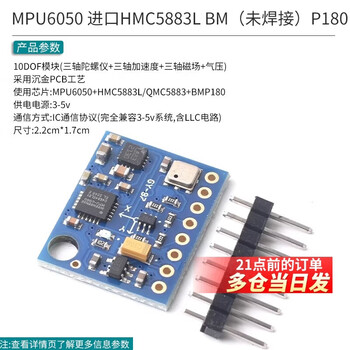
10DOF MPU6050 HMC5883L BMP180 Gyroscope Acceleration Compass Module ...
Jual GY-86 MPU6050 HMC5883L MS5611 10DOF IMU Sensor Module 3 Axis ...
GY-86 10DOF MPU6050 HMC5883L MS5611
GY-87 10DOF MPU6050 HMC5883L BMP180 感測器模塊-淘寶Taobao | 天貓Tmall
Interface HMC5883L Magnetometer with Raspberry Pi Pico
GY-87 10DOF MPU6050 HMC5883L BMP180 三轴加速度计电子陀螺仪
Gyro (Position) sensors (MPU6050) with Arduino - How to access Pitch ...
ESP32 Web Server MPU-6050 Accelerometer Gyroscope (3D object) | Random ...
Trouble changing Pitch and Roll Offsets on MPU6050 - Sensors - Arduino ...
mpu6050 データシート, mpu 6050 使用例 – KGMPYV
아두이노 mpu6050 #mpu6050 #arduino #아두이노 #센서 #자세 #yaw #roll #pitch - YouTube
calculate pitch yaw and roll using mpu9250 and arduino uno - Sensors ...
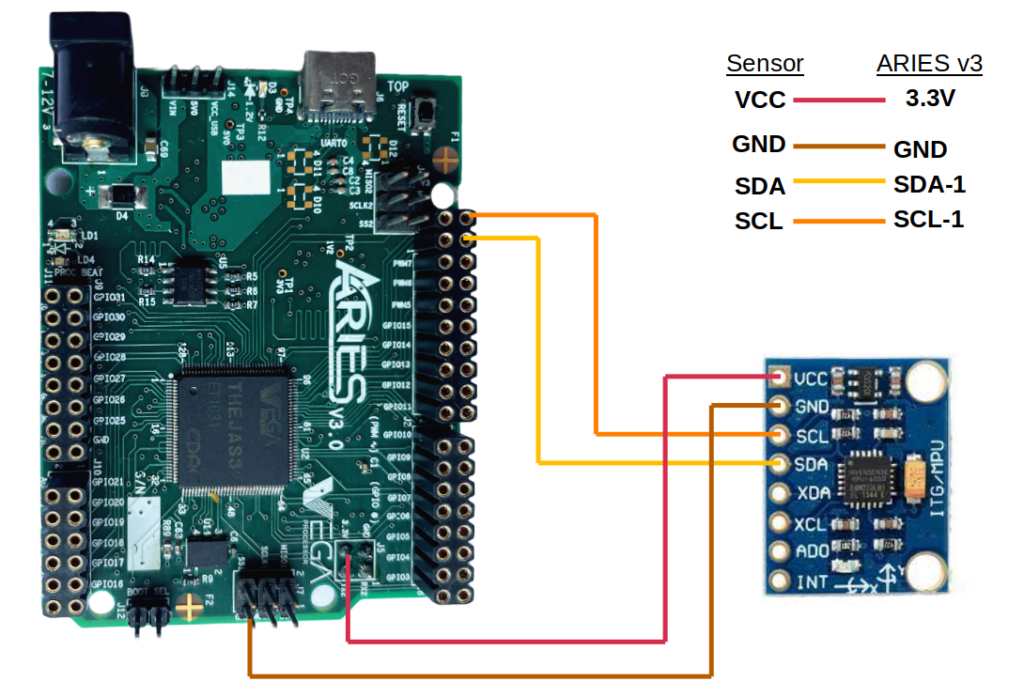
Interfacing MPU6050 Sensor Module to VEGA ARIES boards to find roll and ...
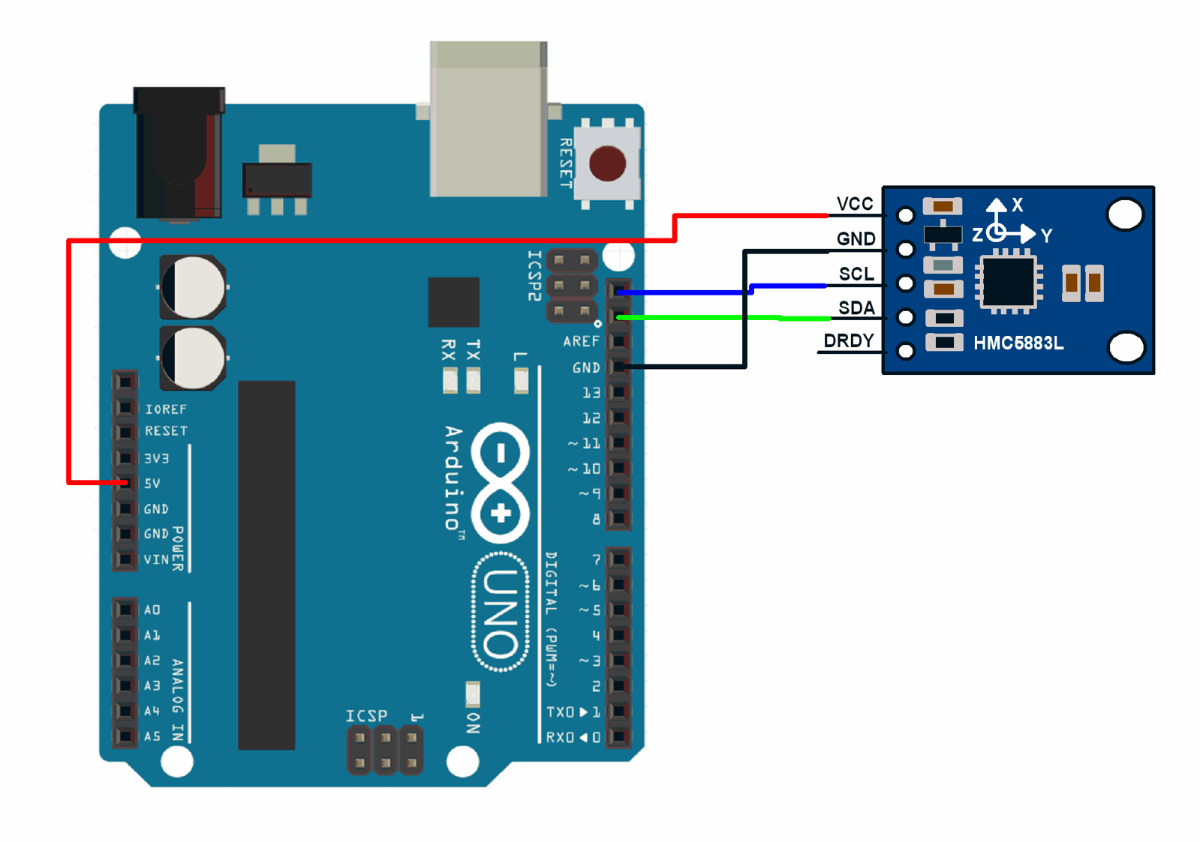
Complete Guide for HMC5883L Magnetometer /Digital Compass | Senso..
(De)coding the MPU6050 and the Control Action – Experiment Design and ...
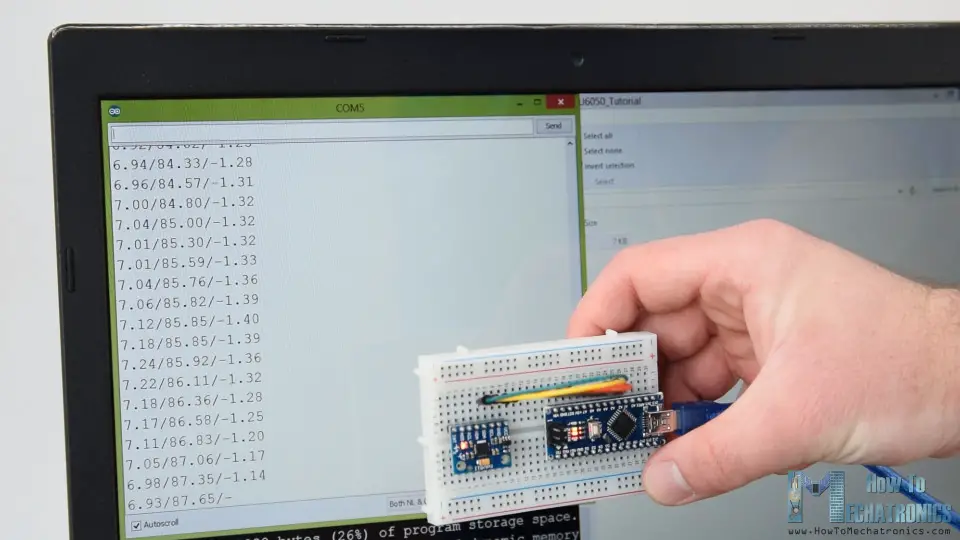
Arduino and MPU6050 Accelerometer and Gyroscope Tutorial
Converting rotation angles from MPU6050 to roll/pitch/yaw - Programming ...
MPU6050模块 三维角度传感器6DOF三轴加速度计电子陀螺仪 GY-521 MPU6050 进口HMC5883L (未焊接)【图片 价格 ...
MPU6050 Assignment - Roll and Pitch - Wokwi ESP32, STM32, Arduino Simulator
Yousif Jalil - Fab Lab
Mpu 6050 Winkel Berechnen: Arduino Mpu 6050 – NVNAKA
Converting Raw Data From Mpu 6050 To Yaw,Pitch And Roll – TRPD
GitHub - nopnop2002/esp-idf-mpu6050-dmp: A demo showing the pose of the ...
10-DOF MPU6050+HMC+BMP180 (2522) – circuitrocks
ESP32与MPU6050的姿态识别项目实战-CSDN博客
Configurar el MPU6050. – Electrónica Práctica Aplicada
[Arduino] Demonstrate an example of yaw, pitch and roll angle by using ...
HMC5883L/QMC5883L Module Pinout | Gyroscope, Microcontrollers, Sensor