Showing 120 of 120on this page. Filters & sort apply to loaded results; URL updates for sharing.120 of 120 on this page
The figure shows the horizontal frame H, placed at the base link bl but ...
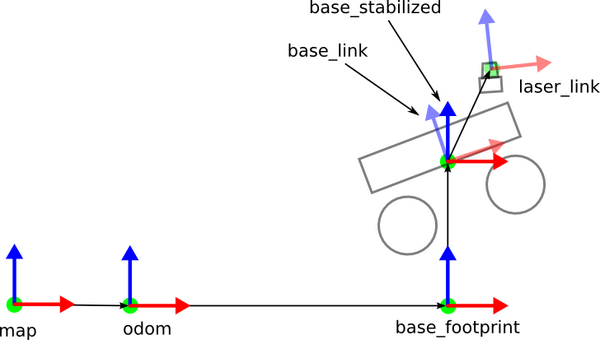
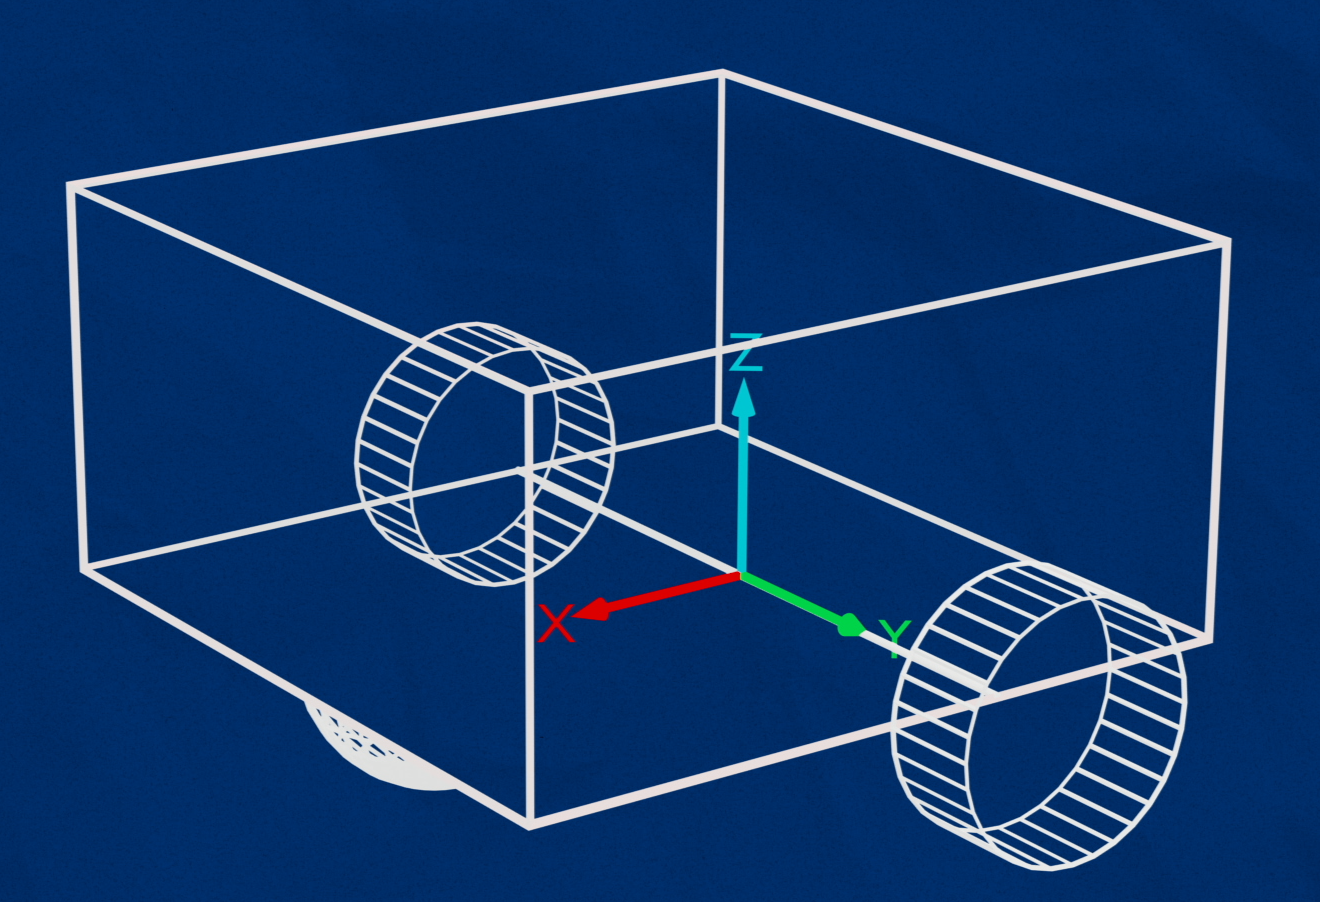
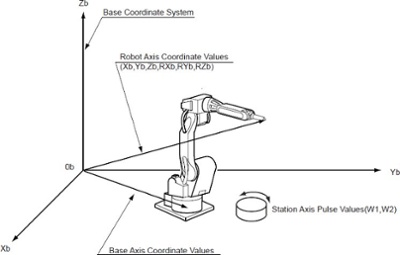
Left: illustration of the robot's coordinate frame, called base link ...
FRAME 4500X LX-R RGB iCUE LINK Panoramic Glass Mid-Tower-PC-Gehäuse
An Example of Rigid-Body Robot Structure (involving 1 base link and 3 ...
| The three coordinate frames, the base frame of the robot, the ...
(a) The robot configuration, (b) link frame assignments. | Download ...
New Camera Link frame grabber: Grablink Duo - Euresys
Figure A.9-Non-Base Link Frame of Reference Method Results Calculation ...
Link frame of the KR500 robot. | Download Scientific Diagram
Mechanical design of the mobile robot base, (a) Base frame only, (b ...
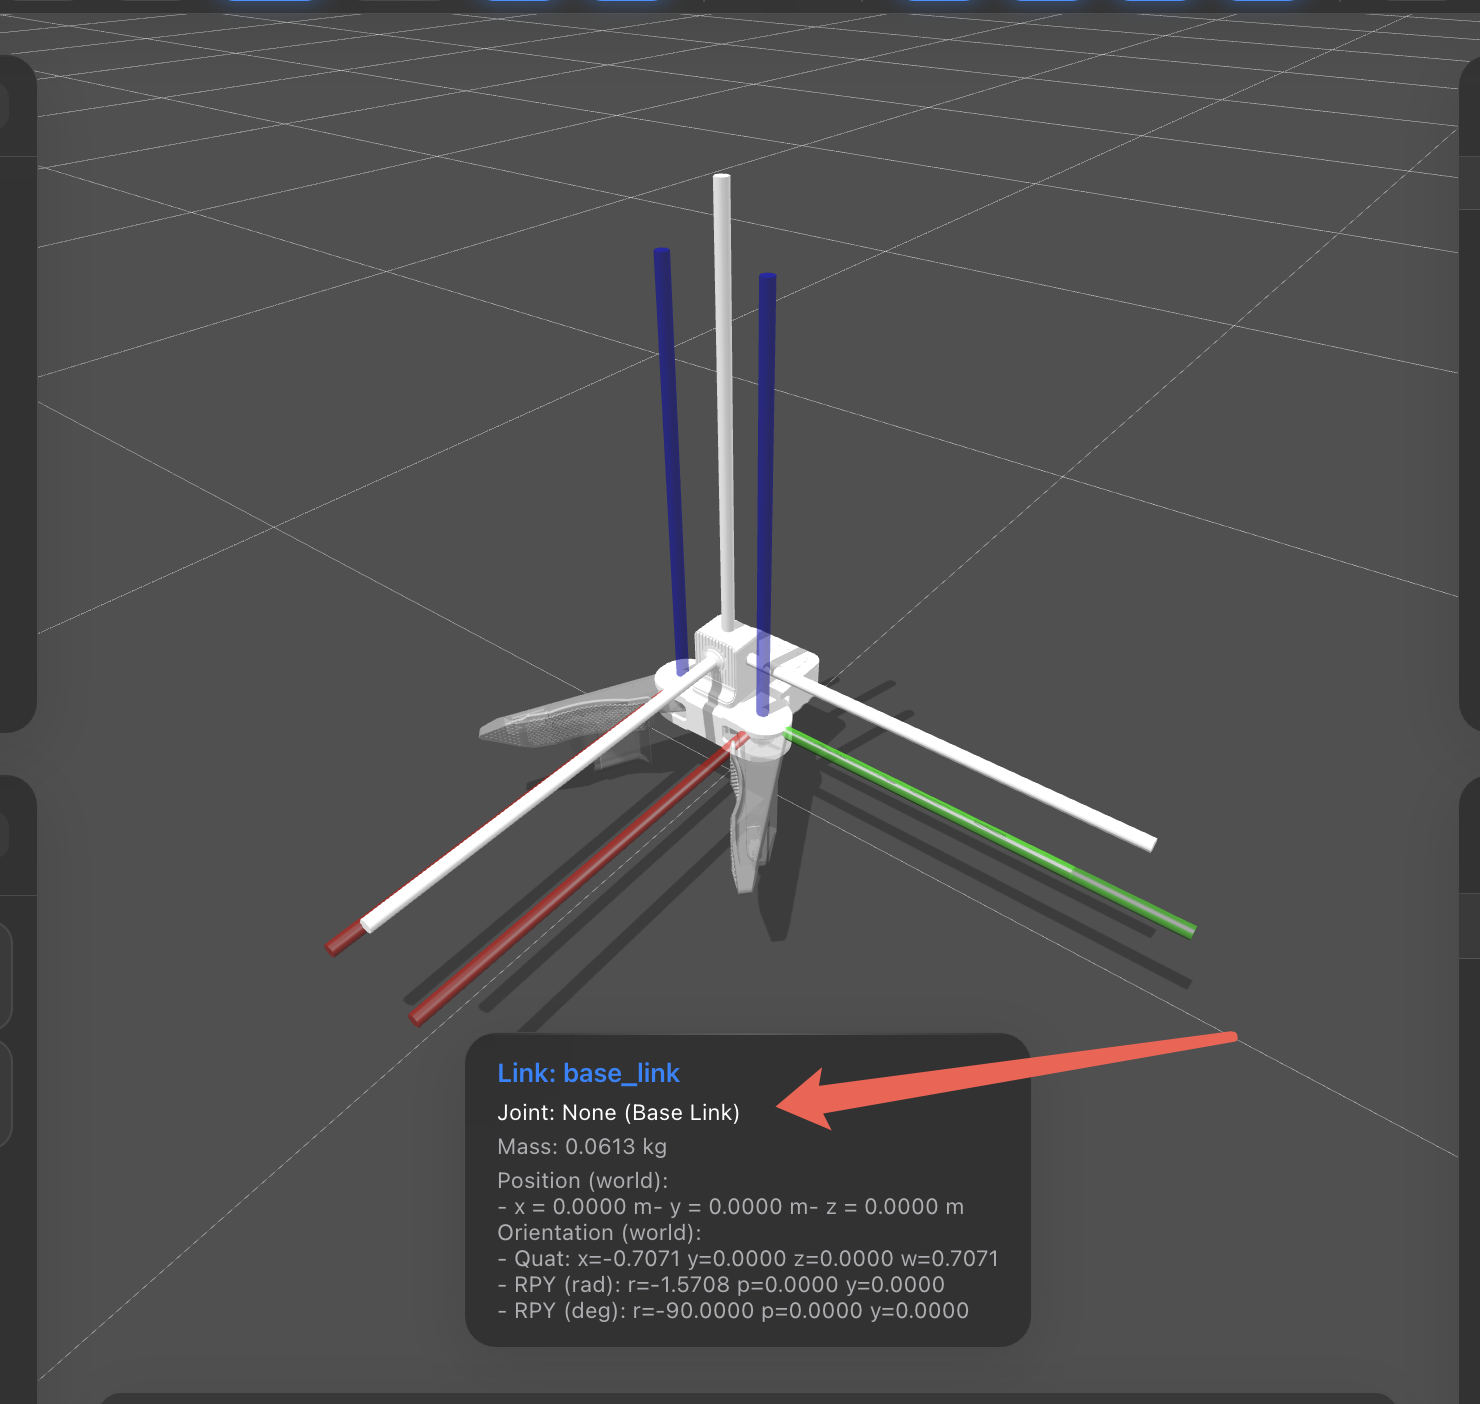
URDF vs. SDF – Link Pose, Joint Pose, Visual & Collision
Virtual Incision: MIRA Surgical System | Springer Nature Link
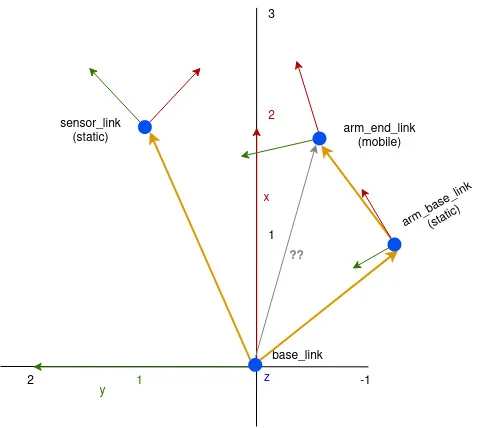
navigation - robot_localization odom wrong frame - Robotics Stack Exchange
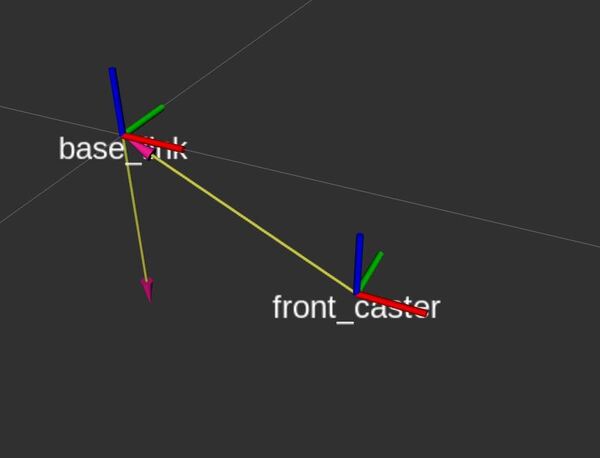
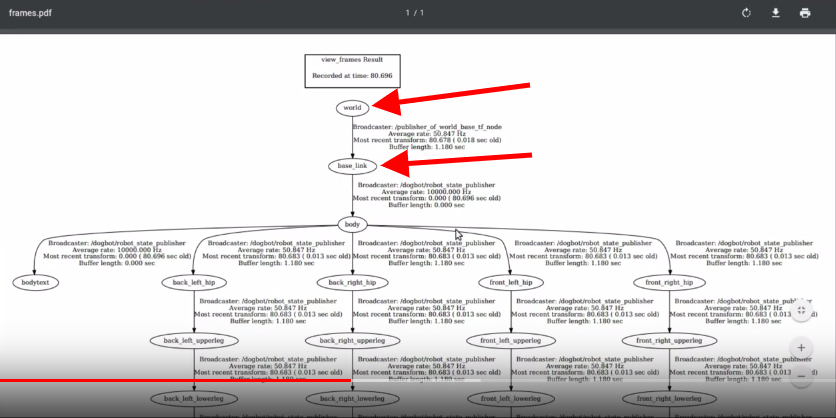
ros - specifying base_link frame for the Transformation tree - Robotics ...
What Is Frame Structures In Robots Explain In Detail - Infoupdate.org
Column Link Behavior in Eccentrically Braced Composite 3-Dimensional Frames
initial orientation of the map frame · Issue #1218 · cartographer ...
ros - Frame in which Goal should be set - Robotics Stack Exchange
AXI03011 SCX10 III Base Camp Builders Kit 1/10th 4WD - HobbyQuarters
cameralink base 接口双通道任意图像数据源模拟
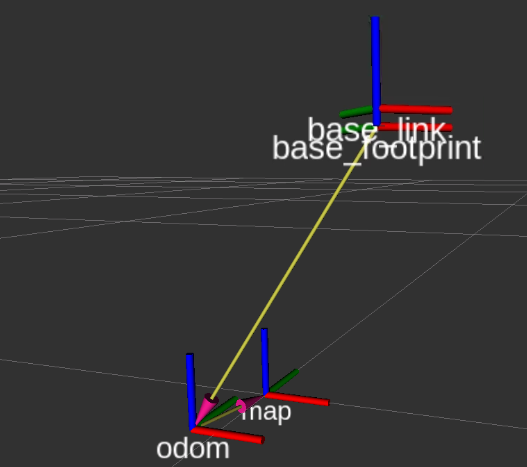
ros - Base_link frame is not connected to odom frame - Robotics Stack ...
Solved A single axis robot with a fixed base and a mobile | Chegg.com
Starlink Standard X-Frame Base - Unboxing and Review - YouTube
Model setup for a four-link robot attached to a non-inertial base with ...
Problem-2: ?? ?? Tip Ltip ?? L? L? (50 Points) Figure 2: Three link RRR ...
1932 Ford Frame For Superide IFS and 4-Link Frame – Heidts Suspension ...
TRX4M Nazaré Chassis: Carbon Fibre Base Kit, Links Included – PNW ...
LiDAR scan visible in base_link frame but not in odom and map frame ...
Axial SCX10 III Base Camp Builder's Kit: Ultimate RC Build
Four Link Suspension Brackets at Matthew Greig blog
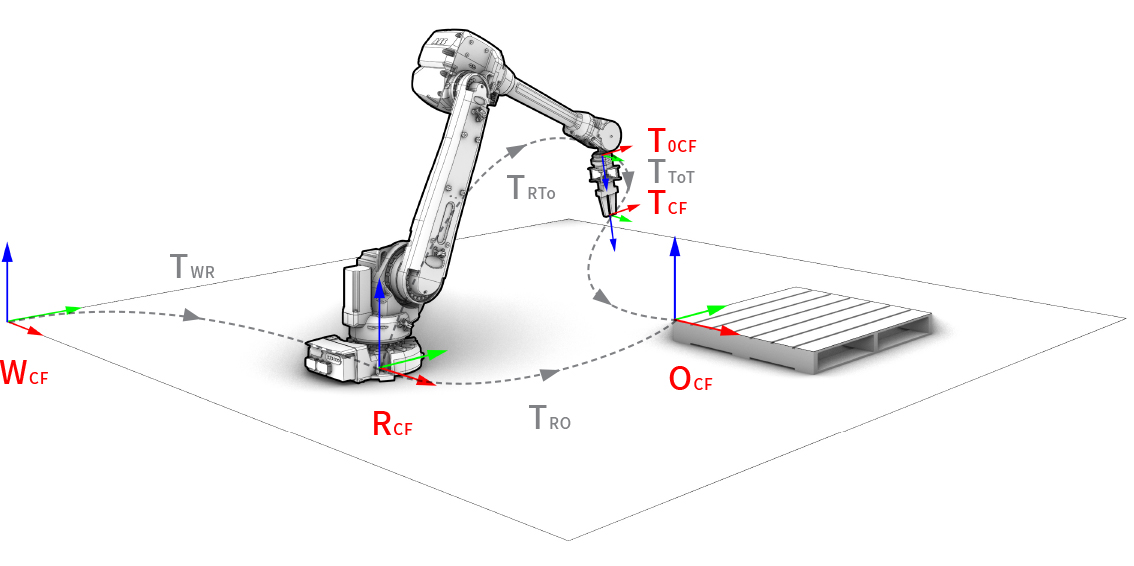
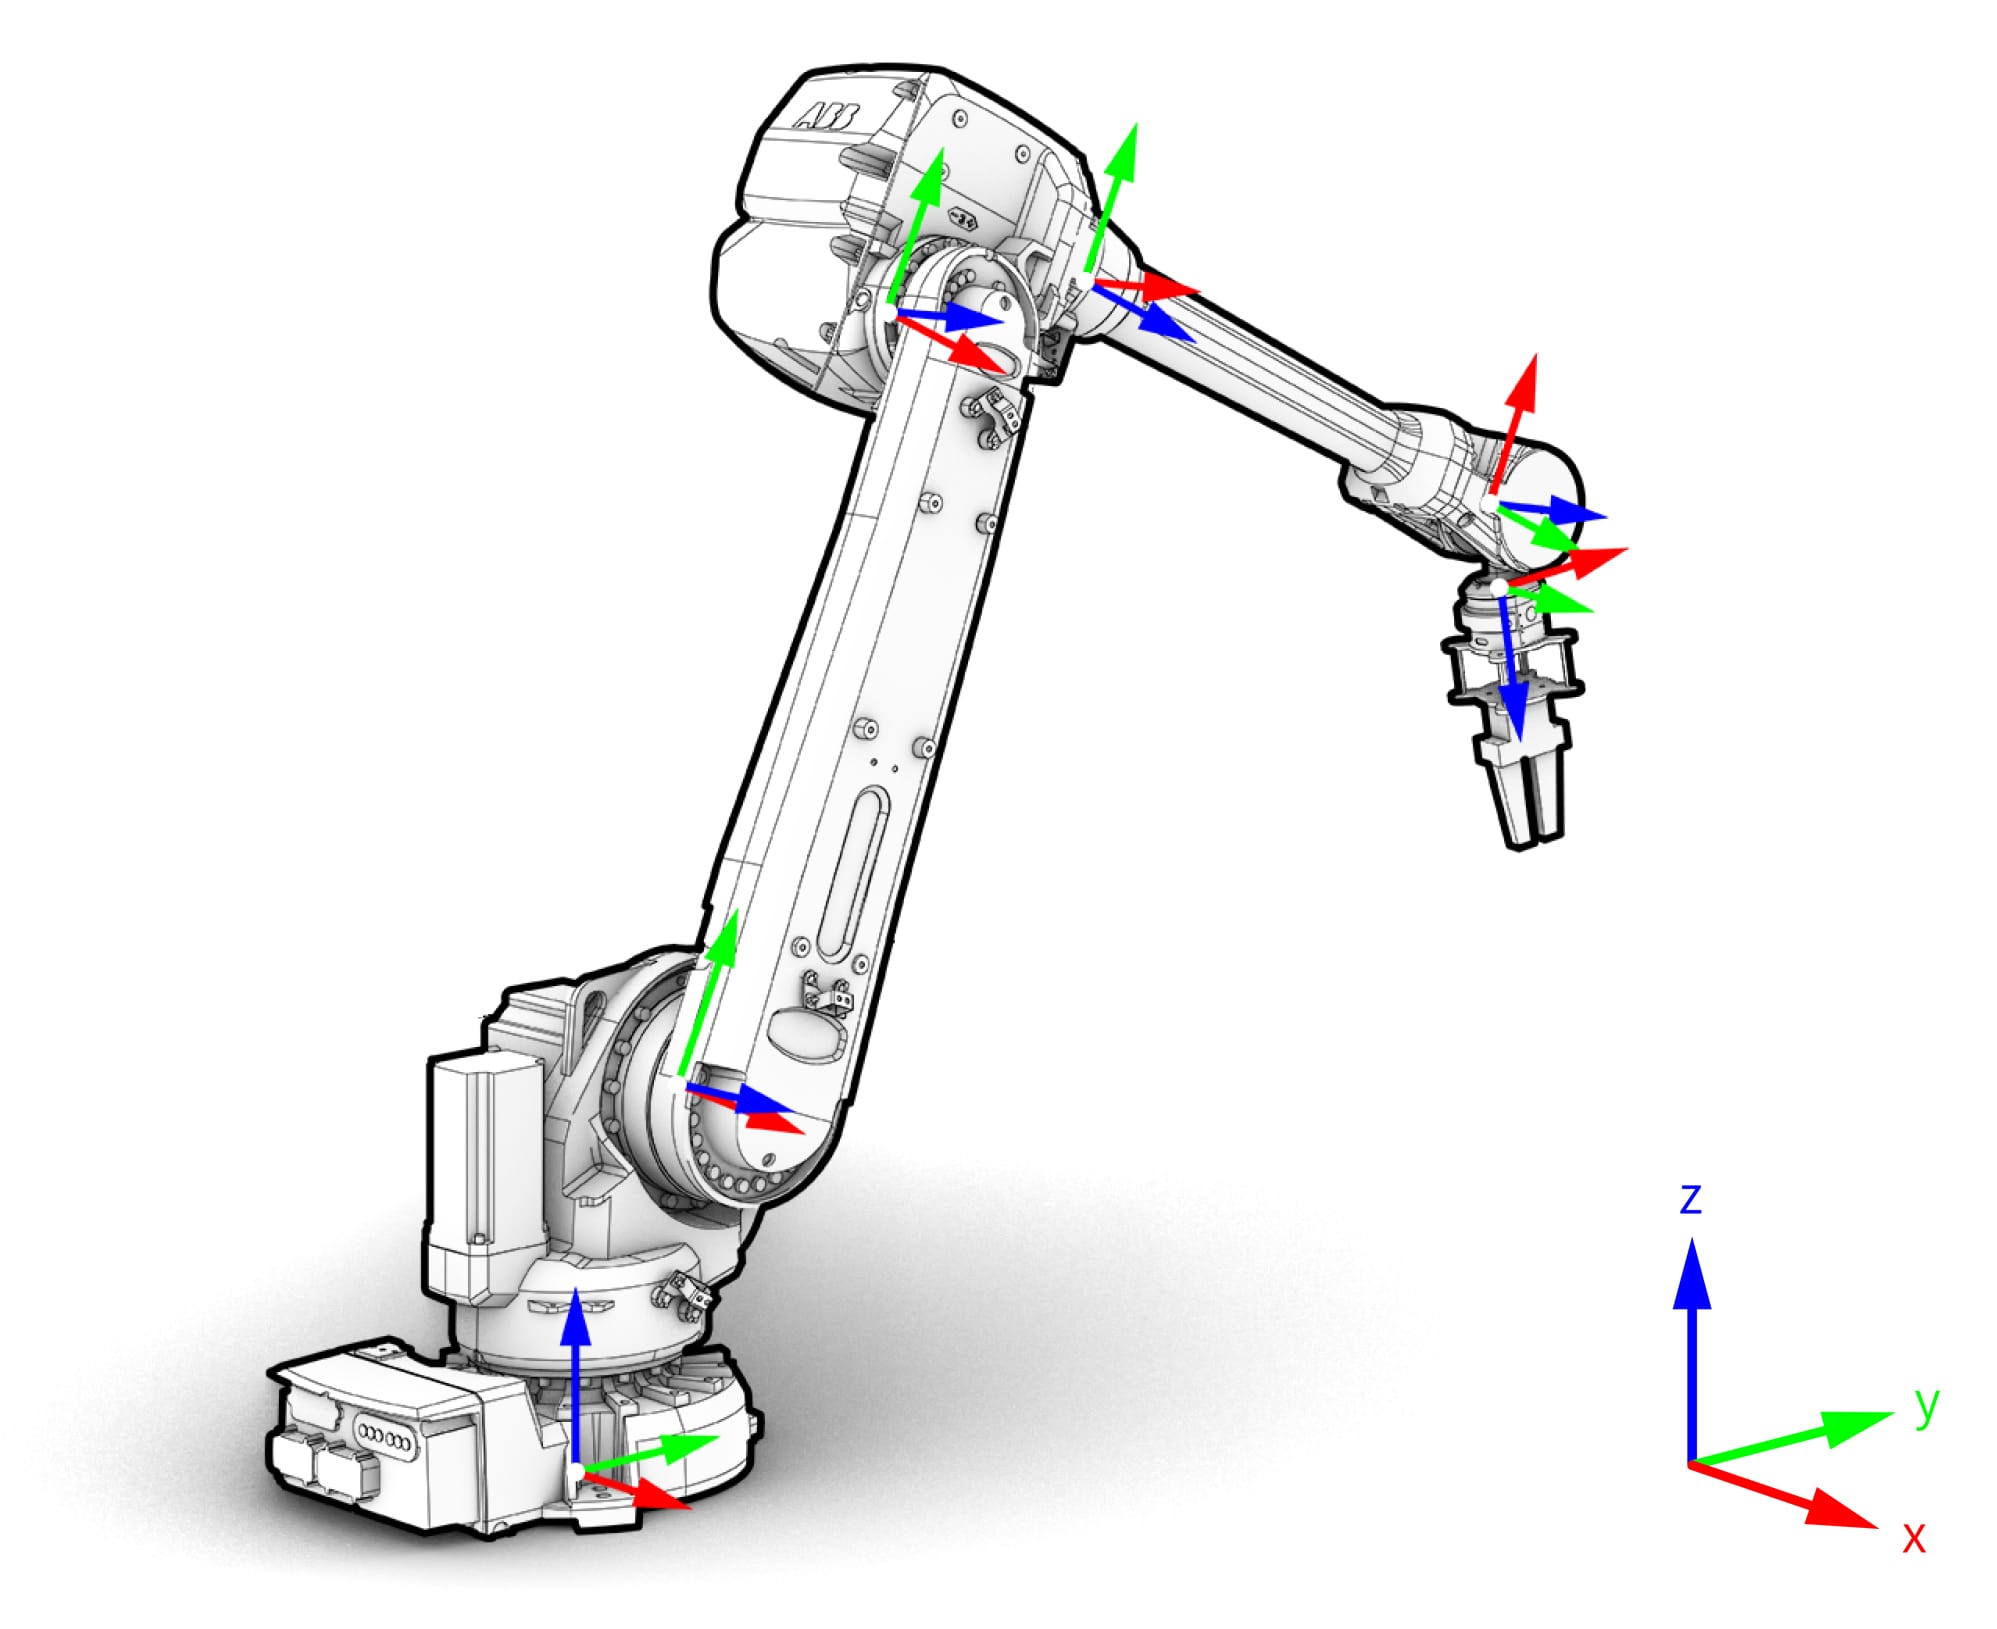
Coordinate Frame Basics and the Right-Hand Rule of Robotics
MAVROS TF Frame Mismatch & Sensor Frequency Error · Issue #1856 ...
Bildverarbeitung . Neue Camera Link Framegrabber Mit Fpga – EIZNJ
25 th11 hybrid base links 2022 new – Artofit
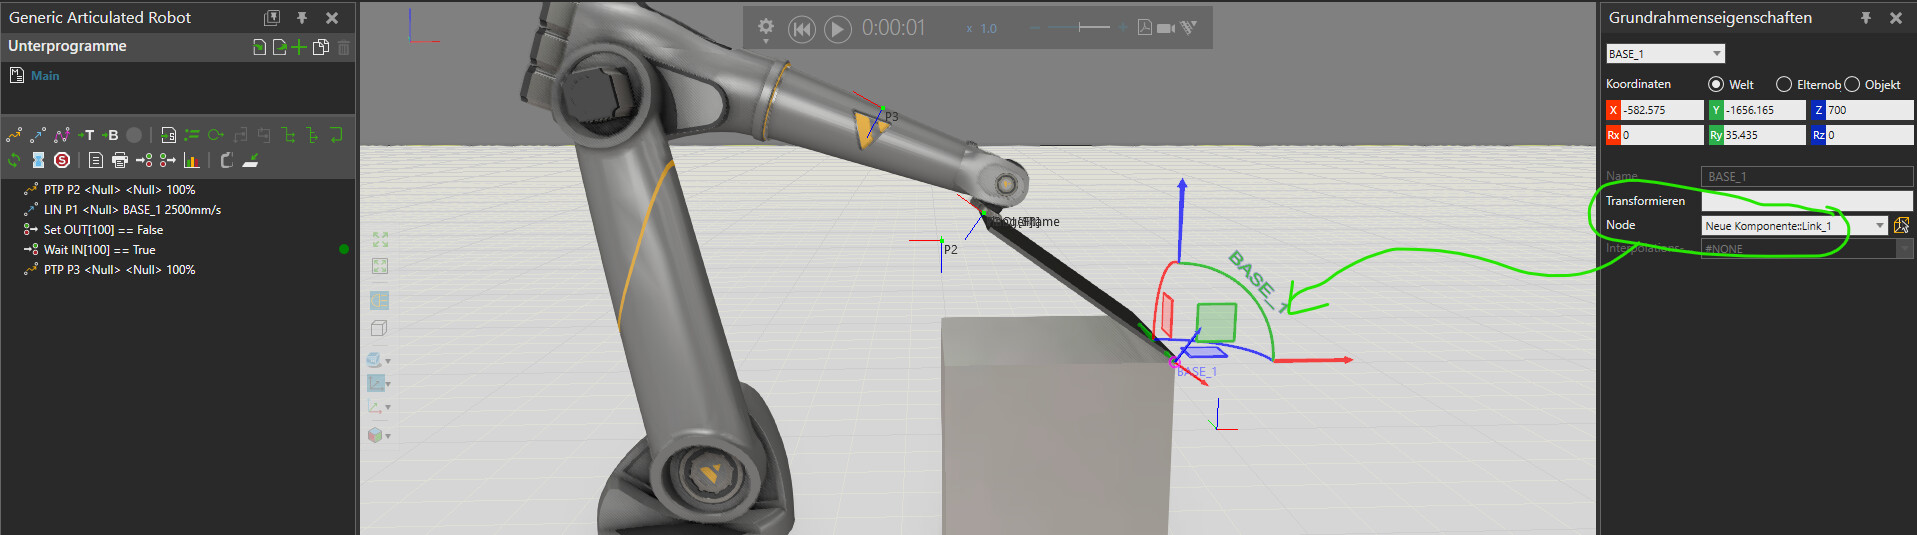
Moving link with robot - Robot Programming - Visual Components - The ...
Parallel Rear Four Link Kit
the goal pose passed to this planner must be in the map frame it is ...
Solved By using the Link Coordinate System in Figure 6, | Chegg.com
Robot arm link coordinate system [28]. | Download Scientific Diagram
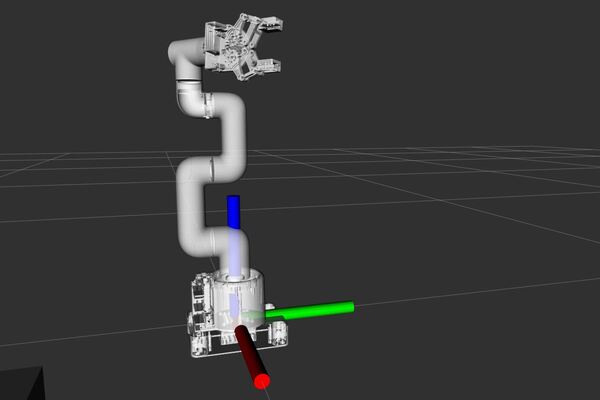
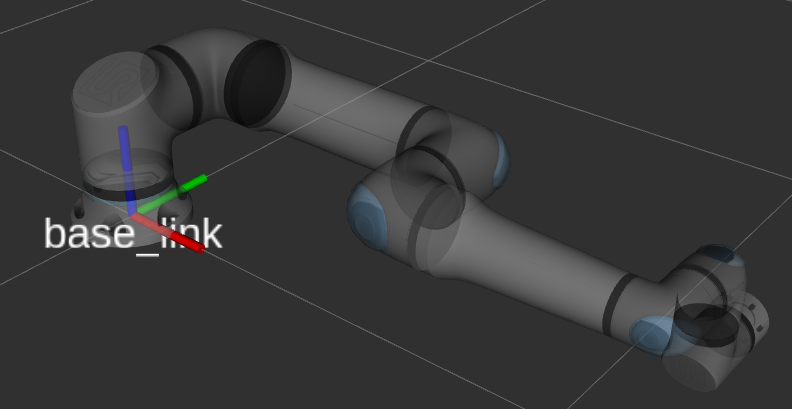
Robot Frames — Universal Robots ROS 2 Driver Documentation 0.1 ...
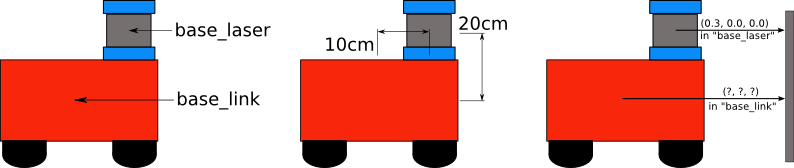
Difference between positions of base_link and base_scan frames ...
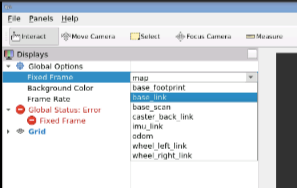
Use of base_footprint in ROS navigation - ROS Navigation In 5 Days ...
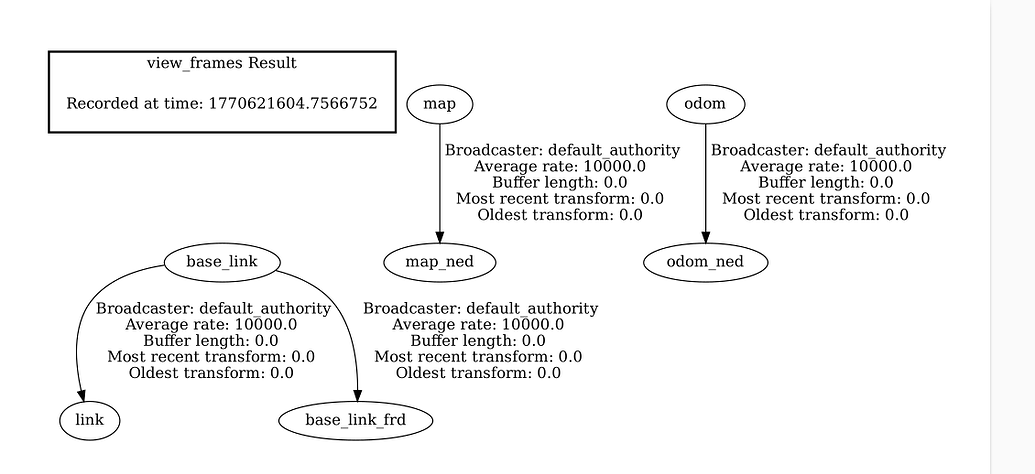
TF Validation | Clearpath Robotics Documentation
ROS学习笔记之——robot_localization包_robot localization github ros2 galactic ...
Understanding ROS Transforms | Foxglove
How to Create a Simulated Mobile Robot in ROS 2 Using URDF
navigation/Tutorials/RobotSetup/TF - ROS Wiki
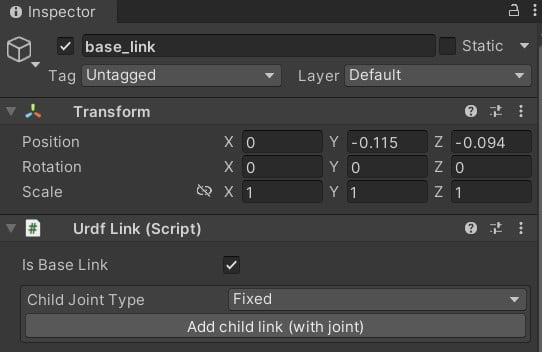
Visualizing Robots in Unity
Introduction to ROBOTICS Forward Kinematics University of Bridgeport
PPT - Robot Kinematics II PowerPoint Presentation, free download - ID ...
ROS gmapping,hector和amcl的坐标系理解_hector 定位-CSDN博客
Understanding ROS Transforms
ros - Robot localization: Odom tf is far offset from Map tf - Robotics ...
ROBOTICS Robot Kinematics Review and examples TEMPUS IV
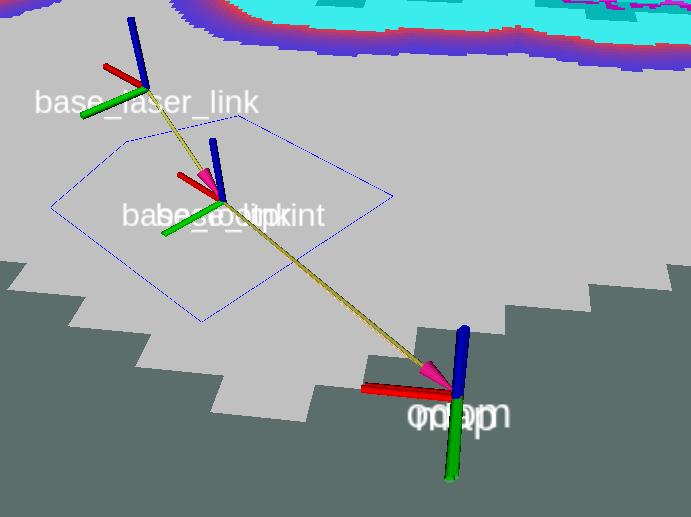
map,odom,base_link,base_laser坐标系_51CTO博客_base_link坐标系在哪里定义
URDF Design | Articulated Robotics
c++ - ROS RVIZ: How to visualize a point cloud that doesn't have a ...
Ardros – Transform Between base_link and the Kinect Sensor – Dr Rainer ...
Chapter 10: Discovering TFs with RViz | ROS 2 from Scratch
Integrating GPS Data — robot_localization 2.7.4 documentation
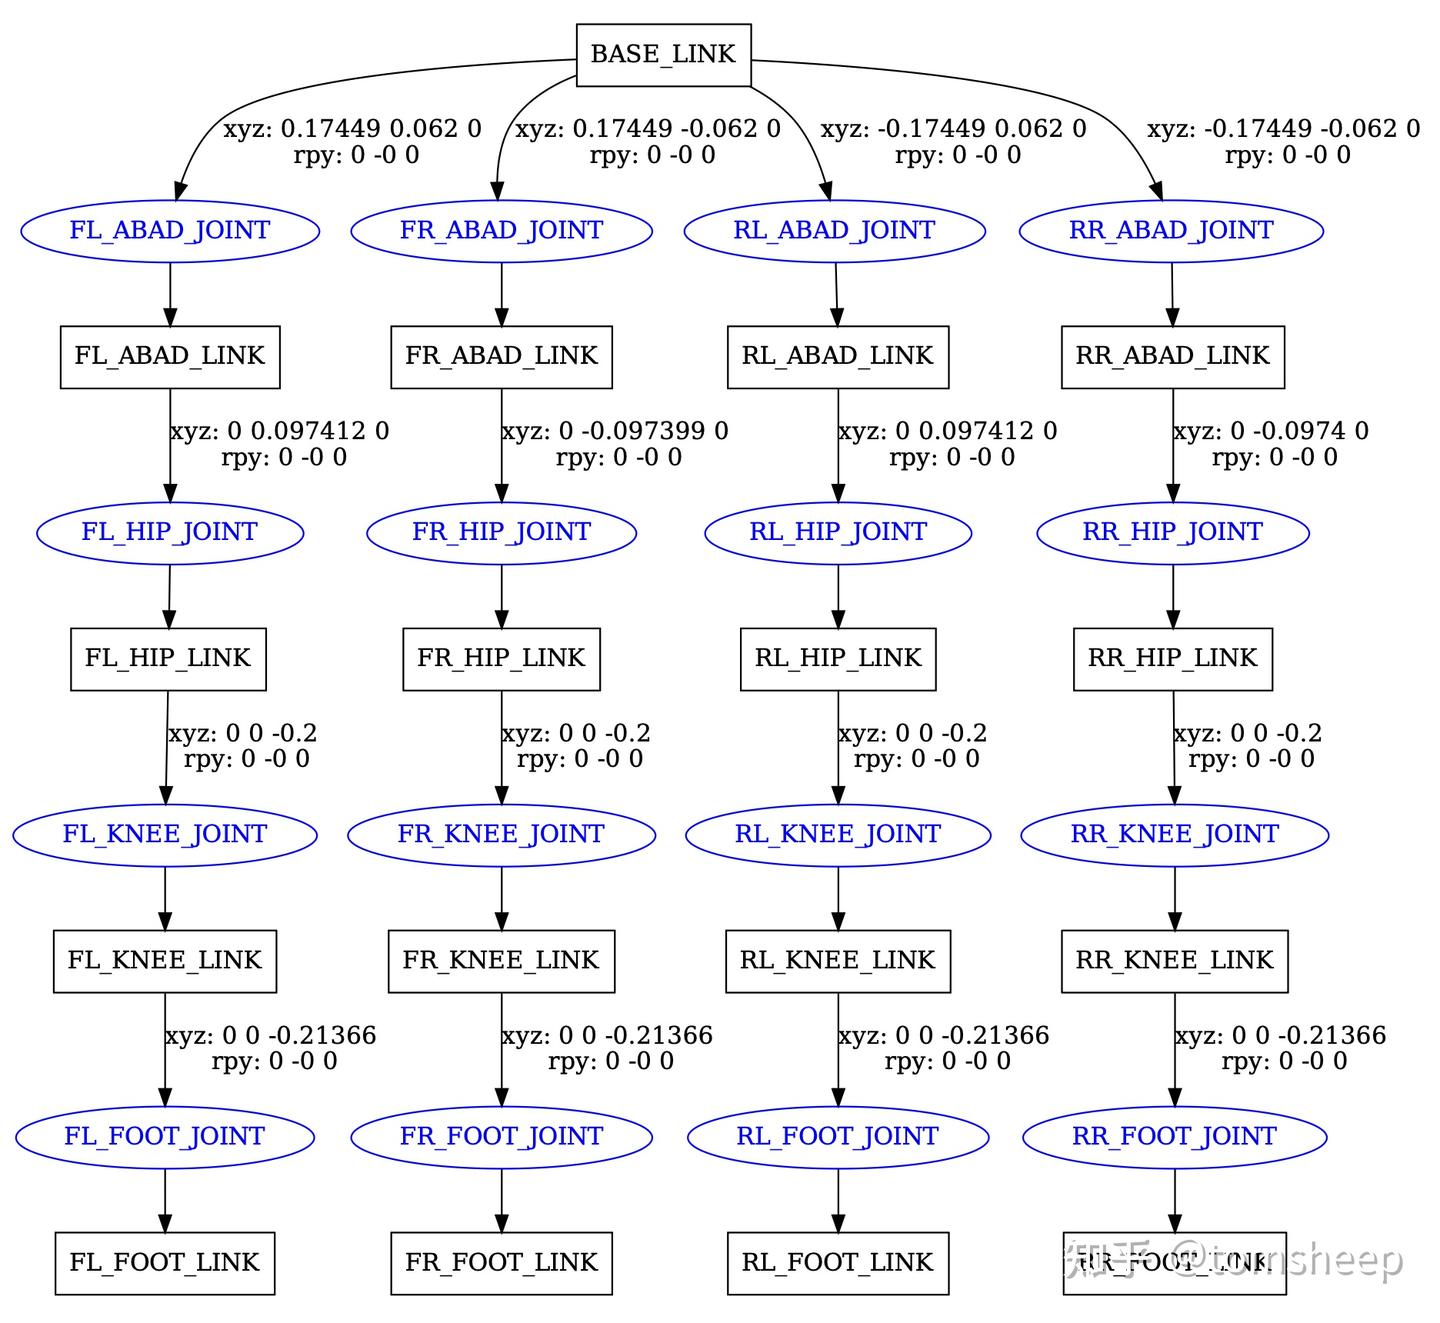
ROS URDF(四) joint和link坐标系及变换释义_ros中rviz中的坐标系是link还是joint-CSDN博客
Odom、base_link、Map_odom baselink map-CSDN博客
Base, End-effector and Target frames for a serial-link manipulator ...
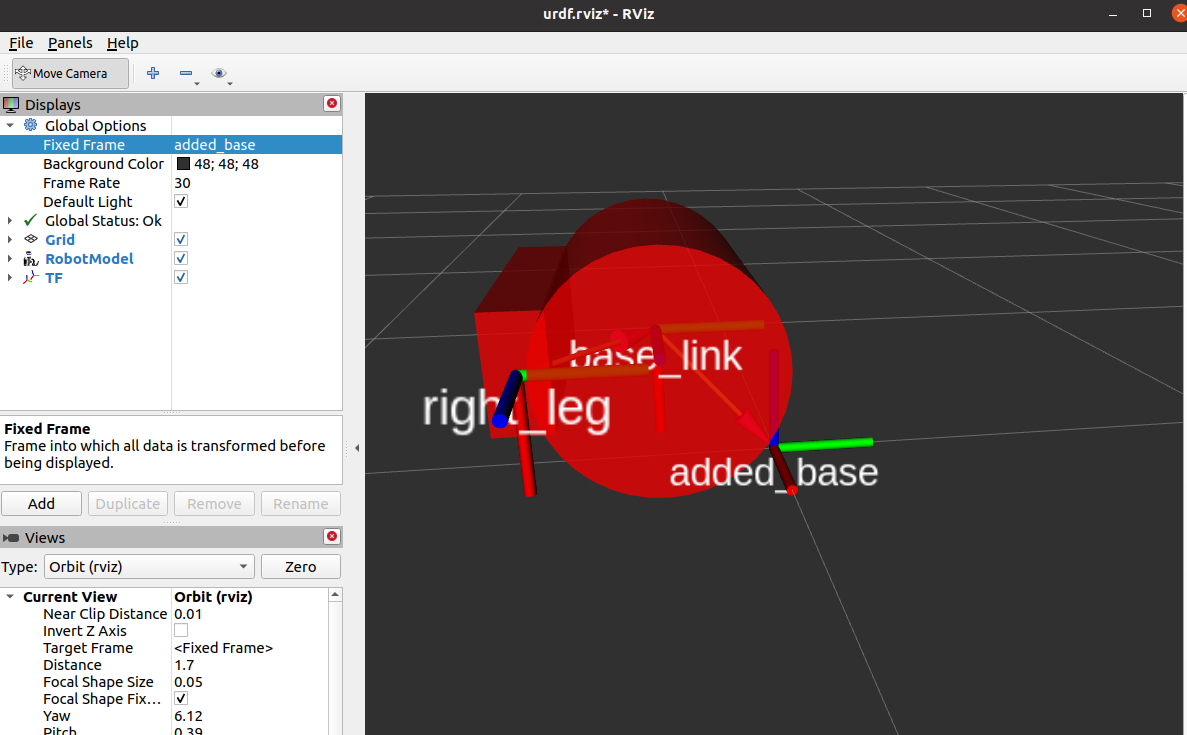
rviz - Incorrect coordinate system for robot model in Rviz2 when ...
DAS Finger Manual v2.0 | GenRobot AI
Robot kinematics 4. A three-link RRP robot manipulator is...
Software Guide - GALAXEA
AUTONOMOUS MOBILE ROBOTICS MEM 1883 CHAPTER 2 a
Understanding Robot Coordinate Frames and Points
compas_fab - 1.2. Coordinate frames
没摸过硬件,我是怎么学习机器人开发的? - 知乎
Connected Components Labeling Algorithm and its Computer Vision ...
Starting with TIER IV's CalibrationTools - Autoware Documentation
ROS组合导航笔记1:融合传感器数据_ros 多传感器融合-CSDN博客
[ROS Q&A] 194 - Add Pressure sensors in RVIZ - The Construct
机器人状态估计:robot_localization 功能包使用方法_robot location-CSDN博客
L1 yo d2 ?? Figure: An RPR planar robot. 1) Assign link...
Forward Kinematics | Toby Godfrey | Personal Site
胡春旭《ROS机器人开发实践》第六章:base_link :No transform from [base link] to [map]_no ...
compas_fab - Kinematic model
Left: Proposed disposition to automatically estimate the transform from ...
[ROS2 Q&A] 223 - How to get robot position using transforms in ROS2 ...
URDF And Sensors - AWSIM Labs Documentation
Hiwonder ArmPi Pro Raspberry Pi 5 ROS Robotic Arm Kit with 4WD Mecanum ...
navigation - Odom Axes not in line with base_link - Robotics Stack Exchange
Rviz and real-world movement differs - Ask - Stretch Forum
Billet 4-Link Chassis Brackets - Tim McAmis Performance Parts
MEUS Racing 324mm Wheelbase Chassis Links For 1/10 Axial Capra 1.9 UTB
For Axial SCX10 PRO Upgrade Parts – Tagged "Chassis Links"
Coordinate Frames and Transforms for ROS-based Mobile Robots
ros - weird initial path from robot_localization's EKF node - Robotics ...
[US Warehouse] INJORA 7pcs High Clearance Chassis Links for SCX24 C10
ros - How to display a marker sequence in ros3djs when each are defined ...
urdf - how to change base_link orientation as parent tf universal robot ...
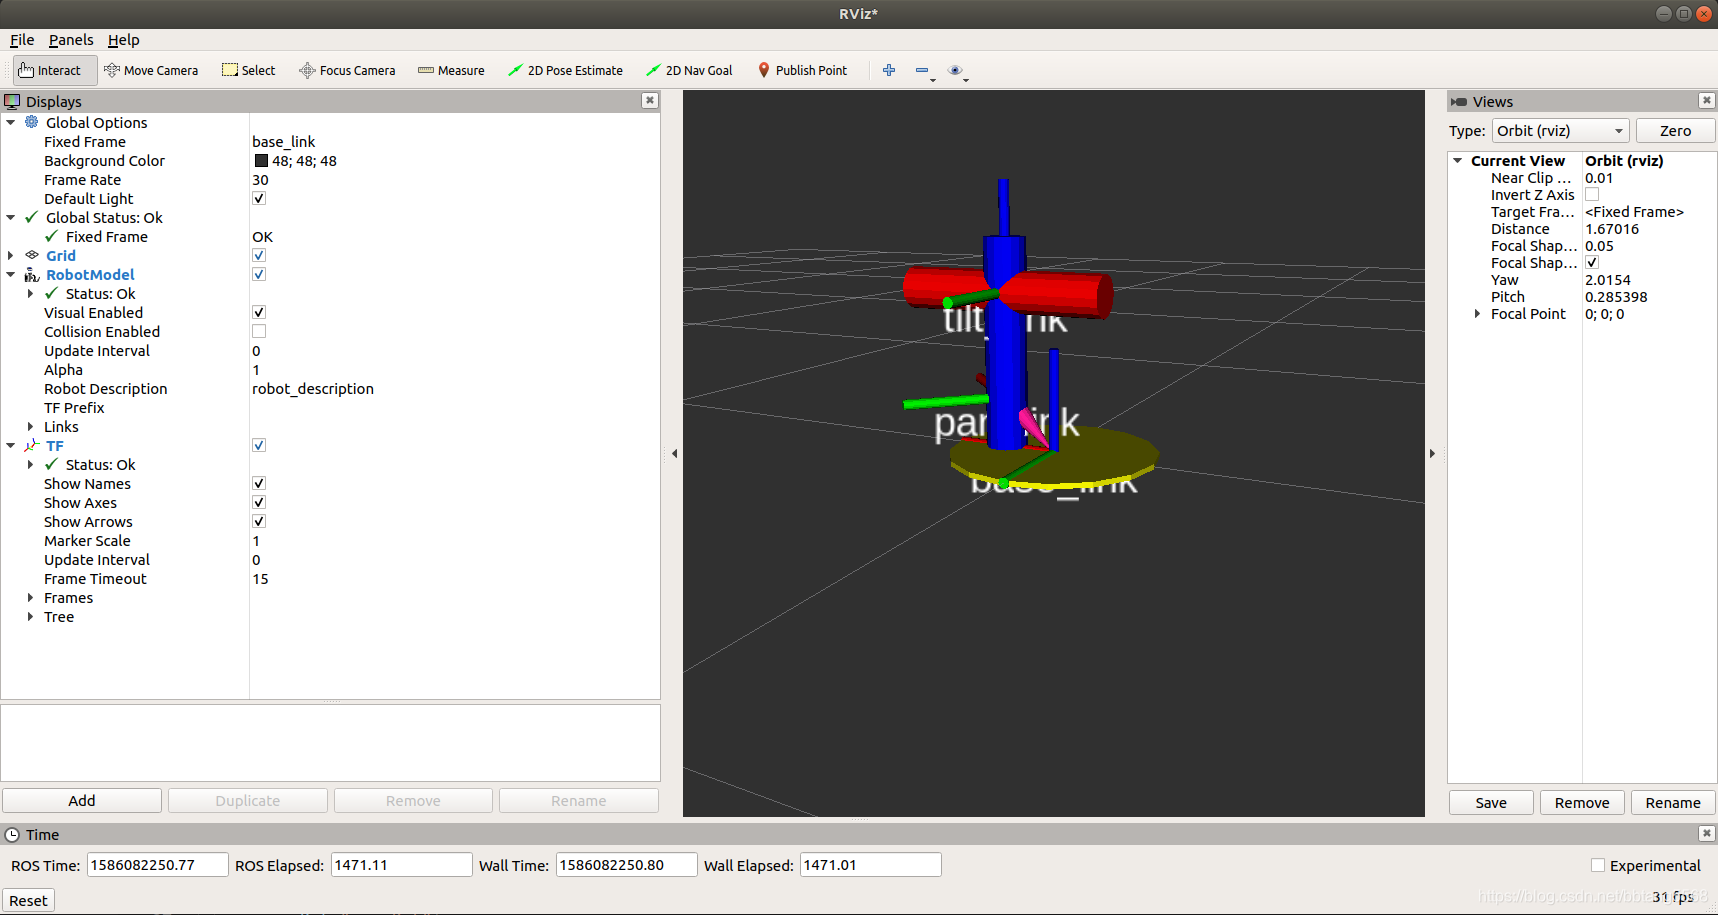
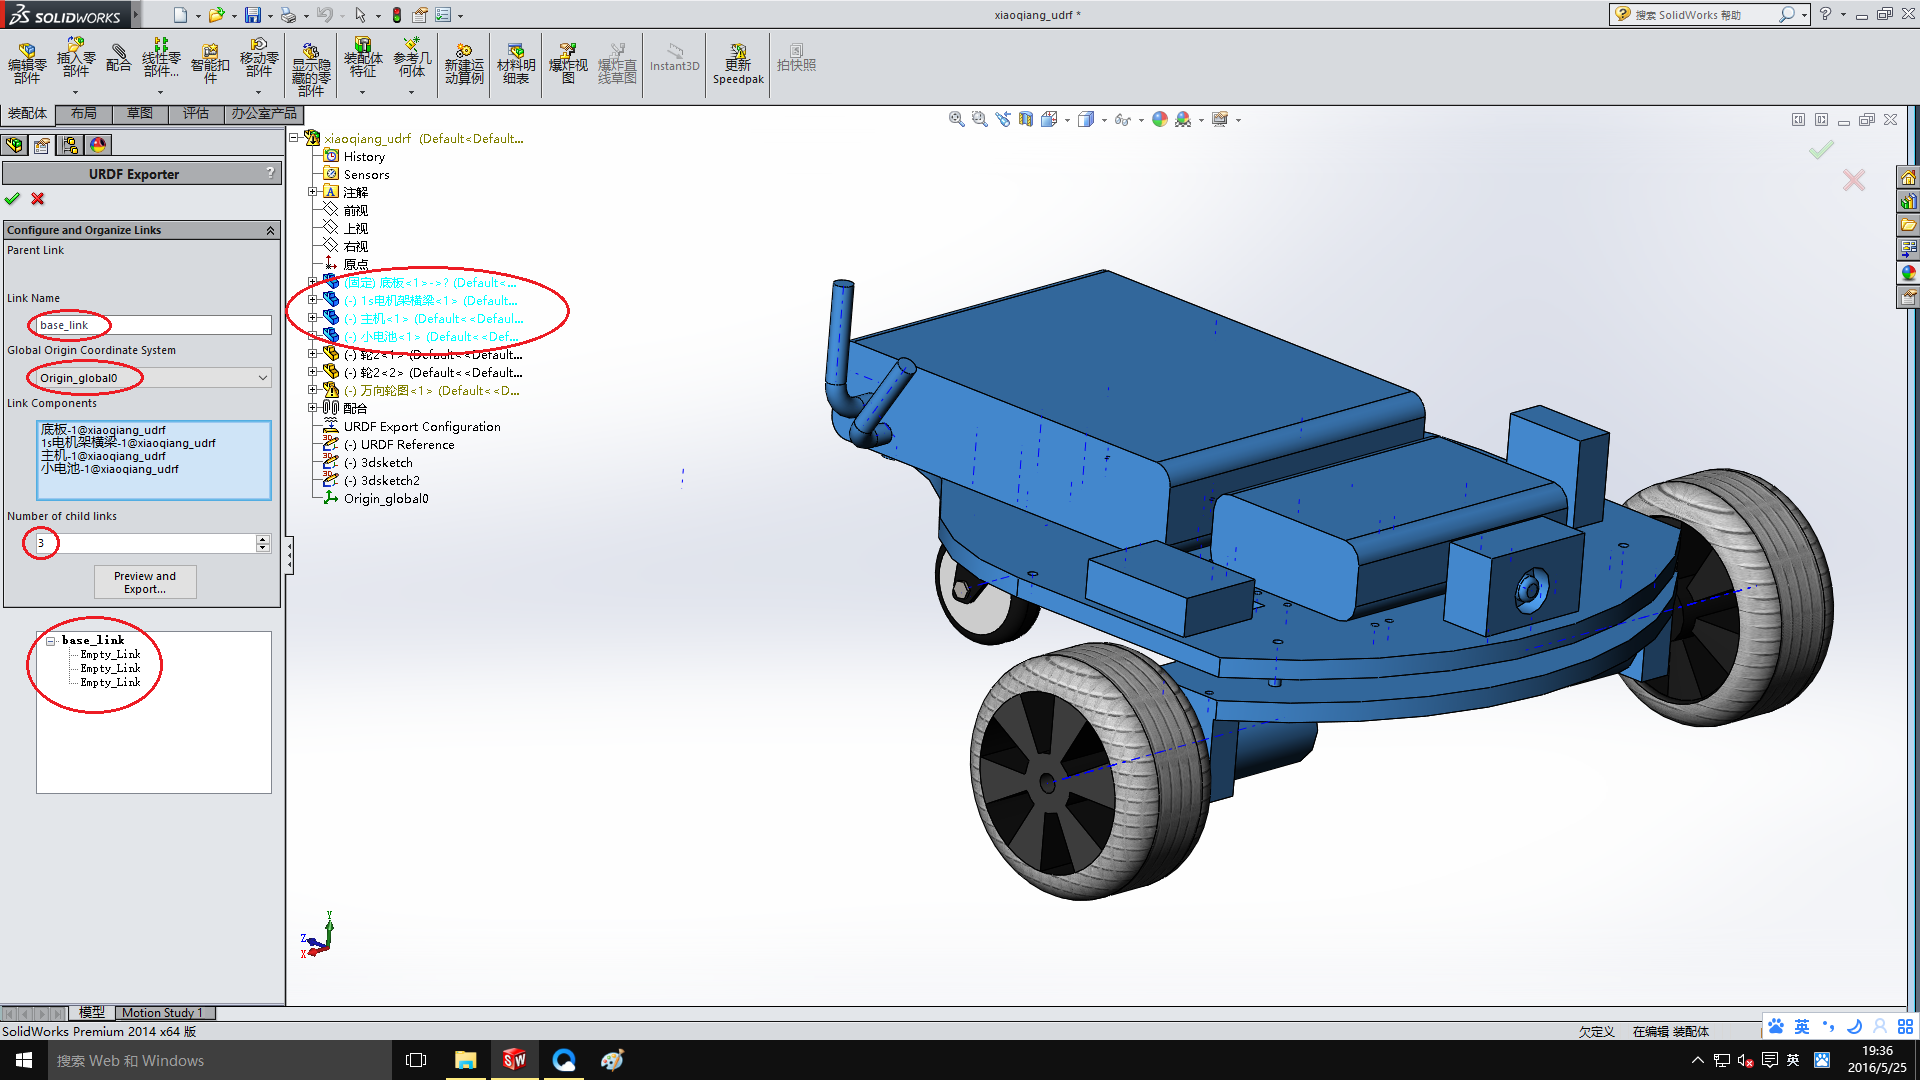
3. 在rviz中显示小强机器人模型 · 小强ROS开发平台用户手册
Hierarchical Trajectory Planning of Floating-Base Multi-Link Robot for ...
SCX24 Chassis Kit – Tagged "Chassis Links"
Open source and open hardware mobile robot for developing applications ...
Glossary
Mobile Robots for Environment-Aware Navigation: A Code-Free Approach ...